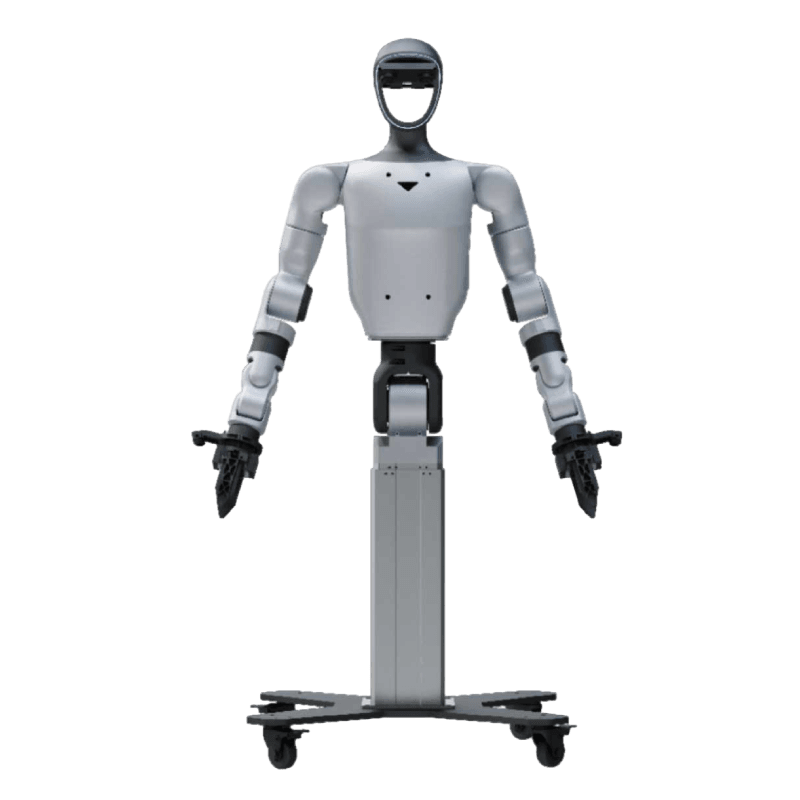
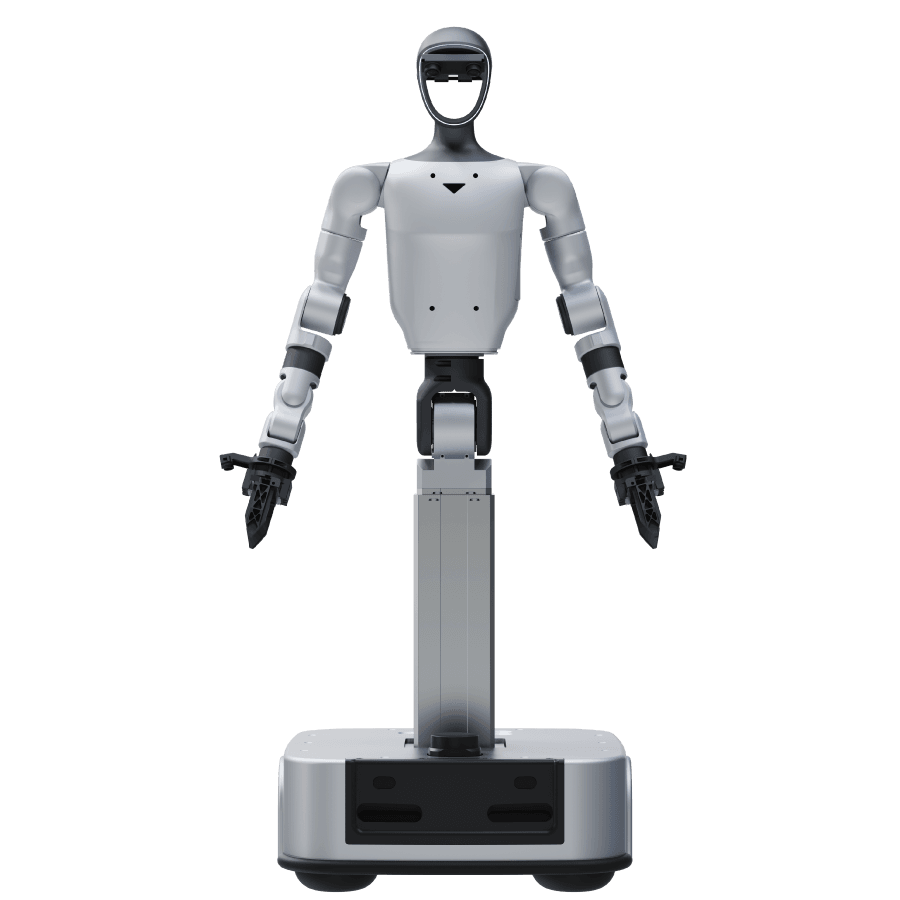
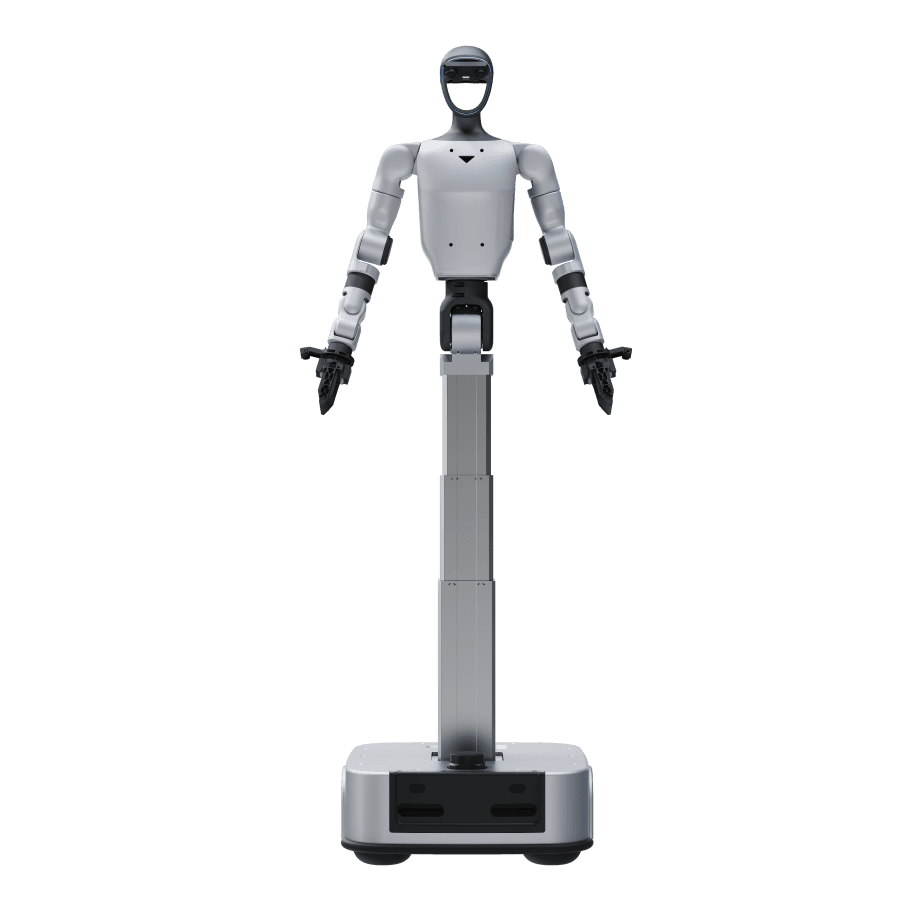
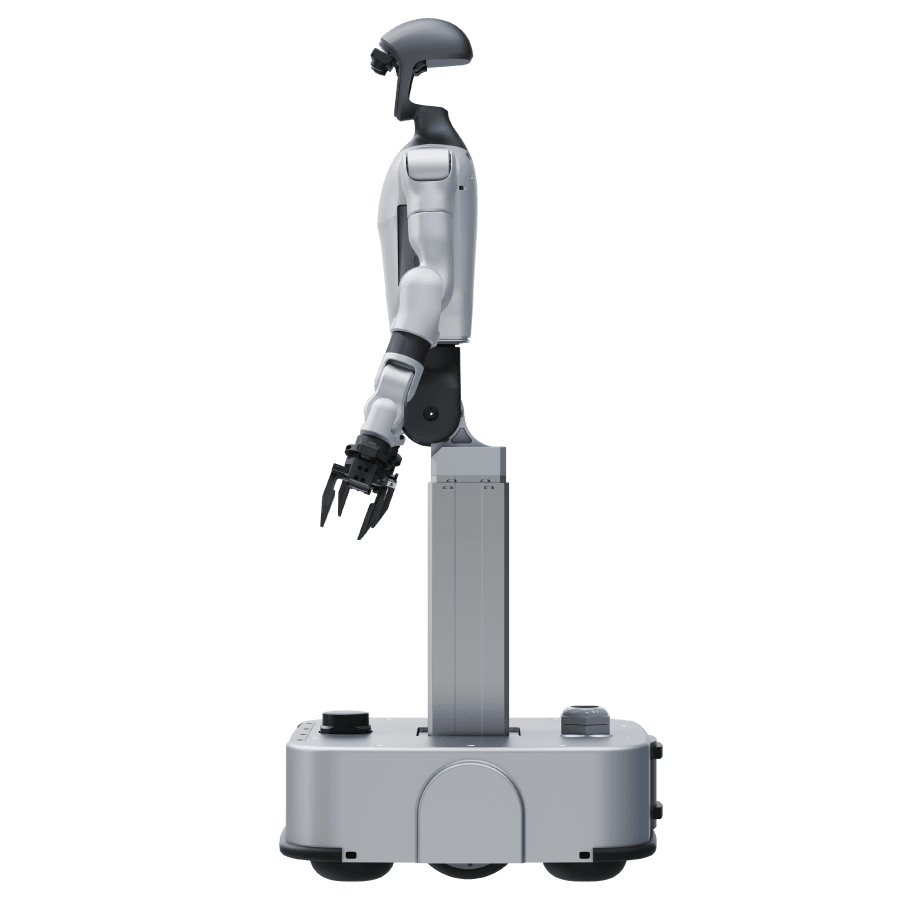
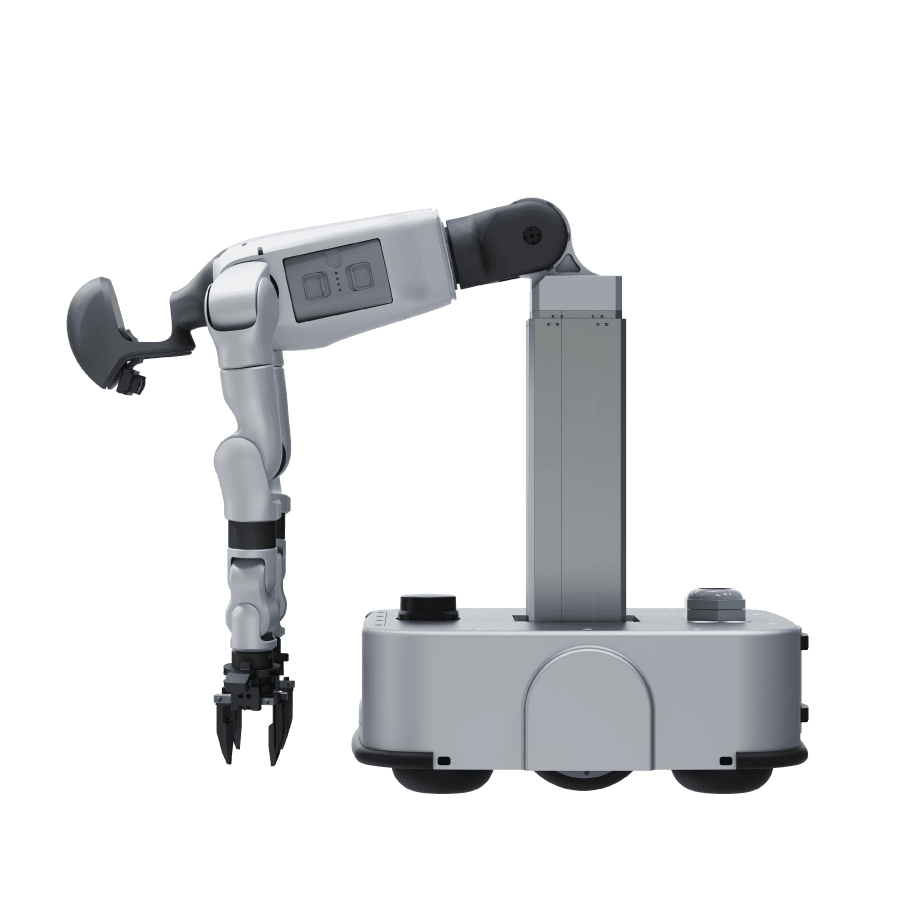
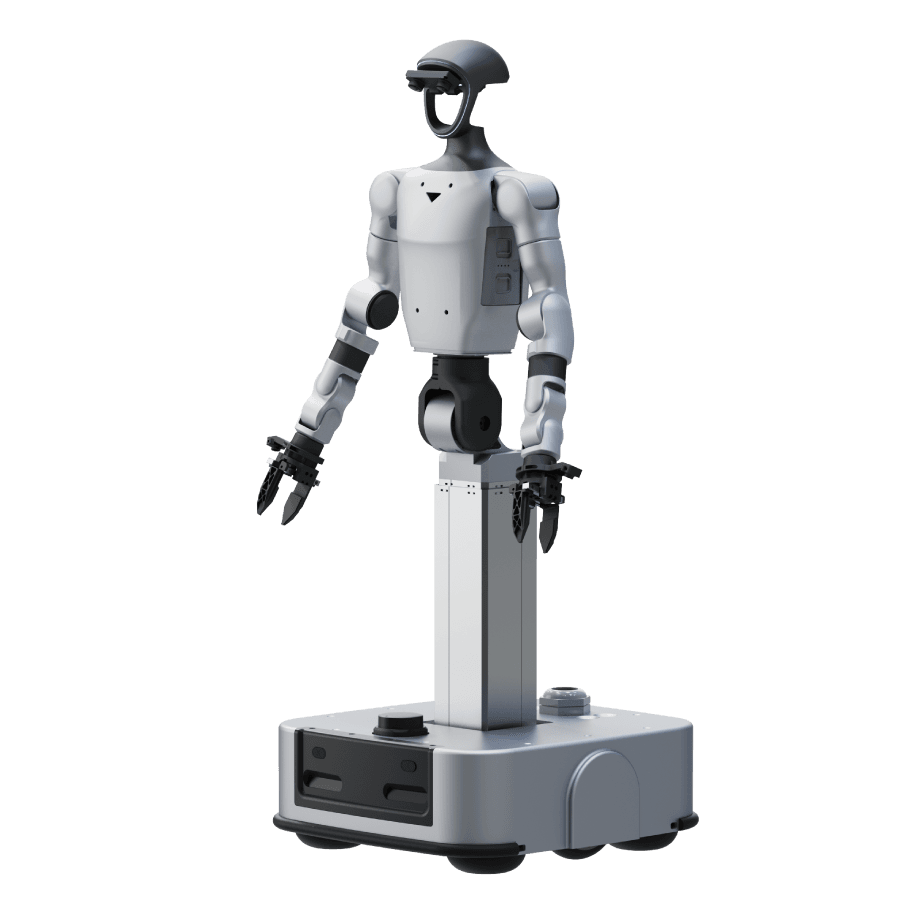
Unitree G1-D är en konfigurerbar humanoid robotplattform för datainsamling, fjärrstyrning, objektmanipulation och utveckling inom AI och robotik. Plattformen har två robotarmar, en höj- och sänkbar konstruktion samt stöd för olika robotiska händer och gripdon.
Välj mellan G1-D Standard och hjulförsedda G1-D Ultimate, med flera alternativ för gripfunktion och taktil avkänning.
G1-D Standard A kombinerar G1-D-plattformen för överkroppen med två Dex1-1 Plus gripdon för mobil manipulation och datainsamling.
Slutlig kompatibilitet, konfiguration, leverans och prissättning bekräftas i offerten.
G1-D Standard B kompletterar Standard A-plattformen med kraftstyrda och trefingrade Dex3-1-händer utan taktil avkänning.
Slutlig kompatibilitet, konfiguration, leverans och prissättning bekräftas i offerten.
G1-D Standard C kompletterar plattformen med taktila, kraftstyrda och trefingrade Dex3-1-händer med 33 taktila sensorer per hand.
Slutlig kompatibilitet, konfiguration, leverans och prissättning bekräftas i offerten.
G1-D Standard D utrustar Standard A-plattformen med två BrainCo Revo 2 Basic femfingrade fingerfärdiga händer.
Slutlig kompatibilitet, konfiguration, leverans och prissättning bekräftas i offerten.
G1-D Standard E utrustar Standard A-plattformen med två taktila BrainCo Revo 2 femfingrade fingerfärdiga händer.
Slutlig kompatibilitet, konfiguration, leverans och prissättning bekräftas i offerten.
G1-D Ultimate A kompletterar plattformen med en motordriven hjulbas, utökad perception och två avancerade kraftstyrda Dex1-1-gripdon.
Slutlig kompatibilitet, konfiguration, leverans och prissättning bekräftas i offerten.
G1-D Ultimate B kompletterar Ultimate A-plattformen med kraftstyrda och trefingrade Dex3-1-händer utan taktil avkänning.
Slutlig kompatibilitet, konfiguration, leverans och prissättning bekräftas i offerten.
G1-D Ultimate C kompletterar plattformen med taktila, kraftstyrda och trefingrade Dex3-1-händer med 33 taktila sensorer per hand.
Slutlig kompatibilitet, konfiguration, leverans och prissättning bekräftas i offerten.
G1-D Ultimate D utrustar Ultimate A-plattformen med två BrainCo Revo 2 Basic femfingrade fingerfärdiga händer.
Slutlig kompatibilitet, konfiguration, leverans och prissättning bekräftas i offerten.
G1-D Ultimate E utrustar Ultimate A-plattformen med två taktila BrainCo Revo 2 femfingrade fingerfärdiga händer.
Slutlig kompatibilitet, konfiguration, leverans och prissättning bekräftas i offerten.
| Specification | G1-D Standard A | G1-D Standard B | G1-D Standard C | G1-D Standard D | G1-D Standard E | G1-D Ultimate A | G1-D Ultimate B | G1-D Ultimate C | G1-D Ultimate D | G1-D Ultimate E |
|---|---|---|---|---|---|---|---|---|---|---|
| General | ||||||||||
| Manufacturer | Unitree | Unitree | Unitree | Unitree | Unitree | Unitree | Unitree | Unitree | Unitree | Unitree |
| Model / edition | G1-D Series | G1-D Series | G1-D Series | G1-D Series | G1-D Series | G1-D Series | G1-D Series | G1-D Series | G1-D Series | G1-D Series |
| Robot type | Humanoid upper-body robot platform | Humanoid upper-body robot platform | Humanoid upper-body robot platform | Humanoid upper-body robot platform | Humanoid upper-body robot platform | Humanoid upper-body robot platform | Humanoid upper-body robot platform | Humanoid upper-body robot platform | Humanoid upper-body robot platform | Humanoid upper-body robot platform |
| Functional description | Configurable upper-body humanoid robot for manipulation, teleoperation, secondary development and data collection. | Configurable upper-body humanoid robot for manipulation, teleoperation, secondary development and data collection. | Configurable upper-body humanoid robot for manipulation, teleoperation, secondary development and data collection. | Configurable upper-body humanoid robot for manipulation, teleoperation, secondary development and data collection. | Configurable upper-body humanoid robot for manipulation, teleoperation, secondary development and data collection. | Configurable upper-body humanoid robot for manipulation, teleoperation, secondary development and data collection. | Configurable upper-body humanoid robot for manipulation, teleoperation, secondary development and data collection. | Configurable upper-body humanoid robot for manipulation, teleoperation, secondary development and data collection. | Configurable upper-body humanoid robot for manipulation, teleoperation, secondary development and data collection. | Configurable upper-body humanoid robot for manipulation, teleoperation, secondary development and data collection. |
| Includes functions of | – | G1-D Standard A | G1-D Standard A | G1-D Standard A | G1-D Standard A | – | G1-D Ultimate A | G1-D Ultimate A | G1-D Ultimate A | G1-D Ultimate A |
| Dimensions & Structure | ||||||||||
| Minimum dimensions (H × W × D) | 1 260 × 500 × 500 mm | 1 260 × 500 × 500 mm | 1 260 × 500 × 500 mm | 1 260 × 500 × 500 mm | 1 260 × 500 × 500 mm | 1 260 × 525 × 570 mm | 1 260 × 525 × 570 mm | 1 260 × 525 × 570 mm | 1 260 × 525 × 570 mm | 1 260 × 525 × 570 mm |
| Maximum dimensions (H × W × D) | 1 680 × 500 × 500 mm | 1 680 × 500 × 500 mm | 1 680 × 500 × 500 mm | 1 680 × 500 × 500 mm | 1 680 × 500 × 500 mm | 1 680 × 525 × 570 mm | 1 680 × 525 × 570 mm | 1 680 × 525 × 570 mm | 1 680 × 525 × 570 mm | 1 680 × 525 × 570 mm |
| Robot weight with battery | 50 kg | 50 kg | 50 kg | 50 kg | 50 kg | 80 kg | 80 kg | 80 kg | 80 kg | 80 kg |
| Maximum operating height | 2 000 mm | 2 000 mm | 2 000 mm | 2 000 mm | 2 000 mm | 2 000 mm | 2 000 mm | 2 000 mm | 2 000 mm | 2 000 mm |
| Degrees of Freedom | ||||||||||
| Total system DoF | 19 | 31 | 31 | 29 | 29 | 21 | 33 | 33 | 31 | 31 |
| Robot DoF excluding end effectors | 17 | 17 | 17 | 17 | 17 | 19 | 19 | 19 | 19 | 19 |
| Single arm DoF | 7 | 7 | 7 | 7 | 7 | 7 | 7 | 7 | 7 | 7 |
| Waist DoF | 2 | 2 | 2 | 2 | 2 | 2 | 2 | 2 | 2 | 2 |
| Vertical column DoF | 1 | 1 | 1 | 1 | 1 | 1 | 1 | 1 | 1 | 1 |
| Mobile base DoF | – | – | – | – | – | 2 | 2 | 2 | 2 | 2 |
| Single hand/end-effector DoF | 1 | 7 | 7 | 6 | 6 | 1 | 7 | 7 | 6 | 6 |
| Single hand joint count | – | – | – | 11 | 11 | – | – | – | 11 | 11 |
| Motion & Performance | ||||||||||
| Arm payload | 3 kg | 3 kg | 3 kg | 3 kg | 3 kg | 3 kg | 3 kg | 3 kg | 3 kg | 3 kg |
| Arm reach | 0,45 m | 0,45 m | 0,45 m | 0,45 m | 0,45 m | 0,45 m | 0,45 m | 0,45 m | 0,45 m | 0,45 m |
| Waist Z-axis range | ±155° | ±155° | ±155° | ±155° | ±155° | ±155° | ±155° | ±155° | ±155° | ±155° |
| Waist Y-axis range | -2.5° to +135° | -2.5° to +135° | -2.5° to +135° | -2.5° to +135° | -2.5° to +135° | -2.5° to +135° | -2.5° to +135° | -2.5° to +135° | -2.5° to +135° | -2.5° to +135° |
| Lift stroke | 500 mm | 500 mm | 500 mm | 500 mm | 500 mm | 450 mm | 450 mm | 450 mm | 450 mm | 450 mm |
| Lift accuracy | 1 mm | 1 mm | 1 mm | 1 mm | 1 mm | 1 mm | 1 mm | 1 mm | 1 mm | 1 mm |
| Maximum lift speed | 60 mm/s | 60 mm/s | 60 mm/s | 60 mm/s | 60 mm/s | 60 mm/s | 60 mm/s | 60 mm/s | 60 mm/s | 60 mm/s |
| Cooling | Local air cooling | Local air cooling | Local air cooling | Local air cooling | Local air cooling | Local air cooling | Local air cooling | Local air cooling | Local air cooling | Local air cooling |
| Mobile Base | ||||||||||
| Base dimensions (L × W × H) | – | – | – | – | – | 570 × 525 × 197 mm | 570 × 525 × 197 mm | 570 × 525 × 197 mm | 570 × 525 × 197 mm | 570 × 525 × 197 mm |
| Drive system | – | – | – | – | – | Dual-wheel differential drive | Dual-wheel differential drive | Dual-wheel differential drive | Dual-wheel differential drive | Dual-wheel differential drive |
| Maximum base speed | – | – | – | – | – | 1,50 m/s | 1,50 m/s | 1,50 m/s | 1,50 m/s | 1,50 m/s |
| In-place 360° rotation | – | – | – | – | – | Yes | Yes | Yes | Yes | Yes |
| LiDAR units | – | – | – | – | – | 1 | 1 | 1 | 1 | 1 |
| Base depth cameras | – | – | – | – | – | 2 | 2 | 2 | 2 | 2 |
| Physical collision sensor | – | – | – | – | – | Yes | Yes | Yes | Yes | Yes |
| Low-lying obstacle recognition sensor | – | – | – | – | – | Yes | Yes | Yes | Yes | Yes |
| Battery & Power | ||||||||||
| Power modes | Smart quick-release battery or direct cable | Smart quick-release battery or direct cable | Smart quick-release battery or direct cable | Smart quick-release battery or direct cable | Smart quick-release battery or direct cable | Built-in base battery or charging pile | Built-in base battery or charging pile | Built-in base battery or charging pile | Built-in base battery or charging pile | Built-in base battery or charging pile |
| Battery type | Smart quick-release battery | Smart quick-release battery | Smart quick-release battery | Smart quick-release battery | Smart quick-release battery | Built-in base battery | Built-in base battery | Built-in base battery | Built-in base battery | Built-in base battery |
| Battery capacity | 9 Ah | 9 Ah | 9 Ah | 9 Ah | 9 Ah | 30 Ah | 30 Ah | 30 Ah | 30 Ah | 30 Ah |
| Battery life | 2 hours | 2 hours | 2 hours | 2 hours | 2 hours | 6 hours | 6 hours | 6 hours | 6 hours | 6 hours |
| Charger output voltage | 54 V | 54 V | 54 V | 54 V | 54 V | 54 V | 54 V | 54 V | 54 V | 54 V |
| Charger output current | 5 A | 5 A | 5 A | 5 A | 5 A | 5 A | 5 A | 5 A | 5 A | 5 A |
| Charging pile output voltage | – | – | – | – | – | 51 V | 51 V | 51 V | 51 V | 51 V |
| Charging pile output current | – | – | – | – | – | 10 A | 10 A | 10 A | 10 A | 10 A |
| Power / charging notes | 9000 mAh smart quick-release battery; 54 V 5 A charger | 9000 mAh smart quick-release battery; 54 V 5 A charger | 9000 mAh smart quick-release battery; 54 V 5 A charger | 9000 mAh smart quick-release battery; 54 V 5 A charger | 9000 mAh smart quick-release battery; 54 V 5 A charger | 30 Ah built-in base battery; 54 V 5 A onboard charger; 51 V 10 A base charging pile | 30 Ah built-in base battery; 54 V 5 A onboard charger; 51 V 10 A base charging pile | 30 Ah built-in base battery; 54 V 5 A onboard charger; 51 V 10 A base charging pile | 30 Ah built-in base battery; 54 V 5 A onboard charger; 51 V 10 A base charging pile | 30 Ah built-in base battery; 54 V 5 A onboard charger; 51 V 10 A base charging pile |
| Compute, Control & Software | ||||||||||
| CPU | 8-core CPU | 8-core CPU | 8-core CPU | 8-core CPU | 8-core CPU | 8-core CPU | 8-core CPU | 8-core CPU | 8-core CPU | 8-core CPU |
| Compute module | NVIDIA Jetson Orin 16 GB | NVIDIA Jetson Orin 16 GB | NVIDIA Jetson Orin 16 GB | NVIDIA Jetson Orin 16 GB | NVIDIA Jetson Orin 16 GB | NVIDIA Jetson Orin 16 GB | NVIDIA Jetson Orin 16 GB | NVIDIA Jetson Orin 16 GB | NVIDIA Jetson Orin 16 GB | NVIDIA Jetson Orin 16 GB |
| AI compute performance | 100 TOPS | 100 TOPS | 100 TOPS | 100 TOPS | 100 TOPS | 100 TOPS | 100 TOPS | 100 TOPS | 100 TOPS | 100 TOPS |
| Optional high-compute modules | Optional rear expansion docks: NVIDIA Jetson AGX Orin (275 TOPS) or NVIDIA Jetson Thor (2070 TOPS) | Optional rear expansion docks: NVIDIA Jetson AGX Orin (275 TOPS) or NVIDIA Jetson Thor (2070 TOPS) | Optional rear expansion docks: NVIDIA Jetson AGX Orin (275 TOPS) or NVIDIA Jetson Thor (2070 TOPS) | Optional rear expansion docks: NVIDIA Jetson AGX Orin (275 TOPS) or NVIDIA Jetson Thor (2070 TOPS) | Optional rear expansion docks: NVIDIA Jetson AGX Orin (275 TOPS) or NVIDIA Jetson Thor (2070 TOPS) | Optional rear expansion docks: NVIDIA Jetson AGX Orin (275 TOPS) or NVIDIA Jetson Thor (2070 TOPS) | Optional rear expansion docks: NVIDIA Jetson AGX Orin (275 TOPS) or NVIDIA Jetson Thor (2070 TOPS) | Optional rear expansion docks: NVIDIA Jetson AGX Orin (275 TOPS) or NVIDIA Jetson Thor (2070 TOPS) | Optional rear expansion docks: NVIDIA Jetson AGX Orin (275 TOPS) or NVIDIA Jetson Thor (2070 TOPS) | Optional rear expansion docks: NVIDIA Jetson AGX Orin (275 TOPS) or NVIDIA Jetson Thor (2070 TOPS) |
| Control | Handheld remote controller included | Handheld remote controller included | Handheld remote controller included | Handheld remote controller included | Handheld remote controller included | Handheld remote controller included | Handheld remote controller included | Handheld remote controller included | Handheld remote controller included | Handheld remote controller included |
| OTA updates | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes |
| Secondary development support | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes |
| Visualization PC included | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes |
| Perception, Audio & Connectivity | ||||||||||
| Perception sensors | Multiple perception sensors | Multiple perception sensors | Multiple perception sensors | Multiple perception sensors | Multiple perception sensors | Multiple perception sensors | Multiple perception sensors | Multiple perception sensors | Multiple perception sensors | Multiple perception sensors |
| Head camera | Binocular camera × 1 | Binocular camera × 1 | Binocular camera × 1 | Binocular camera × 1 | Binocular camera × 1 | Binocular camera × 1 | Binocular camera × 1 | Binocular camera × 1 | Binocular camera × 1 | Binocular camera × 1 |
| Head camera FOV | H 115° / V 80° / D 125° | H 115° / V 80° / D 125° | H 115° / V 80° / D 125° | H 115° / V 80° / D 125° | H 115° / V 80° / D 125° | H 115° / V 80° / D 125° | H 115° / V 80° / D 125° | H 115° / V 80° / D 125° | H 115° / V 80° / D 125° | H 115° / V 80° / D 125° |
| Head camera resolution | 3840 × 1200 | 3840 × 1200 | 3840 × 1200 | 3840 × 1200 | 3840 × 1200 | 3840 × 1200 | 3840 × 1200 | 3840 × 1200 | 3840 × 1200 | 3840 × 1200 |
| Wrist cameras | HD wrist cameras × 2 | HD wrist cameras × 2 | HD wrist cameras × 2 | HD wrist cameras × 2 | HD wrist cameras × 2 | HD wrist cameras × 2 | HD wrist cameras × 2 | HD wrist cameras × 2 | HD wrist cameras × 2 | HD wrist cameras × 2 |
| Wrist camera FOV | H 130° / V 60° / D 160° | H 130° / V 60° / D 160° | H 130° / V 60° / D 160° | H 130° / V 60° / D 160° | H 130° / V 60° / D 160° | H 130° / V 60° / D 160° | H 130° / V 60° / D 160° | H 130° / V 60° / D 160° | H 130° / V 60° / D 160° | H 130° / V 60° / D 160° |
| Wrist camera resolution | 1920 × 1080 | 1920 × 1080 | 1920 × 1080 | 1920 × 1080 | 1920 × 1080 | 1920 × 1080 | 1920 × 1080 | 1920 × 1080 | 1920 × 1080 | 1920 × 1080 |
| Audio input | 4-microphone array | 4-microphone array | 4-microphone array | 4-microphone array | 4-microphone array | 4-microphone array | 4-microphone array | 4-microphone array | 4-microphone array | 4-microphone array |
| Audio output | 5 W speaker | 5 W speaker | 5 W speaker | 5 W speaker | 5 W speaker | 5 W speaker | 5 W speaker | 5 W speaker | 5 W speaker | 5 W speaker |
| Wi-Fi | Wi-Fi 6 | Wi-Fi 6 | Wi-Fi 6 | Wi-Fi 6 | Wi-Fi 6 | Wi-Fi 6 | Wi-Fi 6 | Wi-Fi 6 | Wi-Fi 6 | Wi-Fi 6 |
| Bluetooth | Bluetooth 5.2 | Bluetooth 5.2 | Bluetooth 5.2 | Bluetooth 5.2 | Bluetooth 5.2 | Bluetooth 5.2 | Bluetooth 5.2 | Bluetooth 5.2 | Bluetooth 5.2 | Bluetooth 5.2 |
| Hand / End Effector | ||||||||||
| Hand / end-effector model | Dex1-1 Plus grippers × 2 | Dex3-1 force-controlled three-finger dexterous hands, non-tactile × 2 | Dex3-1 force-controlled three-finger dexterous hands, tactile × 2 | BrainCo Bionic Dexterous Hand Revo 2 Basic × 2 | BrainCo Bionic Dexterous Hand Revo 2 Tactile × 2 | Dex1-1 force-controlled grippers, Advanced Version × 2 | Dex3-1 force-controlled three-finger dexterous hands, non-tactile × 2 | Dex3-1 force-controlled three-finger dexterous hands, tactile × 2 | BrainCo Bionic Dexterous Hand Revo 2 Basic × 2 | BrainCo Bionic Dexterous Hand Revo 2 Tactile × 2 |
| Tactile sensing | No | No | Yes | No | Yes | – | No | Yes | No | Yes |
| Single hand/end-effector weight | 550 g | 650 g | 650 g | 383 g | 383 g | – | 650 g | 650 g | 383 g | 383 g |
| Hand/end-effector dimensions | 143 × 78 × 67 mm | 175 × 88 × 77 mm | 175 × 88 × 77 mm | – | – | – | 175 × 88 × 77 mm | 175 × 88 × 77 mm | – | – |
| Hand height | – | – | – | 160 mm | 160 mm | – | – | – | 160 mm | 160 mm |
| Single hand/end-effector DoF | 1 | 7 | 7 | 6 | 6 | 1 | 7 | 7 | 6 | 6 |
| Single hand joint count | – | – | – | 11 | 11 | – | – | – | 11 | 11 |
| Operating voltage | – | 12–58 V | 12–58 V | – | – | – | 12–58 V | 12–58 V | – | – |
| Static current | – | 0.2 A at 58 V | 0.2 A at 58 V | – | – | – | 0.2 A at 58 V | 0.2 A at 58 V | – | – |
| Communication interface / protocol | High-speed 485 | USB | USB | – | – | – | USB | USB | – | – |
| Repeatability / control accuracy | – | – | – | 0.1° | 0.1° | – | – | – | 0.1° | 0.1° |
| Whole-hand / gripping force | – | – | – | 50 N | 50 N | – | – | – | 50 N | 50 N |
| Single-finger pinch force | – | – | – | 15 N | 15 N | – | – | – | 15 N | 15 N |
| Adjustable force range | 5–120 N adjustable | – | – | – | – | – | – | – | – | – |
| Position resolution | 0.1 mm | – | – | – | – | – | – | – | – | – |
| Gripper stroke | 90 mm | – | – | – | – | – | – | – | – | – |
| Closing time | 0.24 s for full stroke | – | – | – | – | – | – | – | – | – |
| Claw length | 80 mm | – | – | – | – | – | – | – | – | – |
| Form-closure gripping payload | 20 kg | – | – | – | – | – | – | – | – | – |
| Friction gripping payload | 5 kg | – | – | – | – | – | – | – | – | – |
| Tactile sensors per hand | – | – | 33 | – | – | – | – | 33 | – | – |
| Tactile perception range | – | – | 10–2500 g | – | – | – | – | 10–2500 g | – | – |
| Tactile sensing capabilities | – | – | – | – | Pressure, friction, direction and proximity sensing | – | – | – | – | Pressure, friction, direction and proximity sensing |
| Hand/wrist RGB camera included | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes |
| Hand / end-effector notes | Two-finger grippers; specifications are per gripper unless otherwise stated. | Three-finger hand: thumb 3 DoF, index finger 2 DoF and middle finger 2 DoF; specifications are per hand. | Three-finger hand: thumb 3 DoF, index finger 2 DoF and middle finger 2 DoF; specifications are per hand. | Height is measured from the middle fingertip to the palm root; specifications are per hand. | Height is measured from the middle fingertip to the palm root; specifications are per hand. | The supplied document does not state detailed specifications for the Advanced Version gripper. | Three-finger hand: thumb 3 DoF, index finger 2 DoF and middle finger 2 DoF; specifications are per hand. | Three-finger hand: thumb 3 DoF, index finger 2 DoF and middle finger 2 DoF; specifications are per hand. | Height is measured from the middle fingertip to the palm root; specifications are per hand. | Height is measured from the middle fingertip to the palm root; specifications are per hand. |
| Package, Warranty & Notes | ||||||||||
| Included items | Dex1-1 Plus grippers × 2; handheld remote controller; visualization PC | Dex3-1 non-tactile dexterous hands × 2; handheld remote controller; visualization PC | Dex3-1 tactile dexterous hands × 2; handheld remote controller; visualization PC | BrainCo Revo 2 Basic hands × 2; handheld remote controller; visualization PC | BrainCo Revo 2 Tactile hands × 2; handheld remote controller; visualization PC | Dex1-1 Advanced grippers × 2; handheld remote controller; visualization PC | Dex3-1 non-tactile dexterous hands × 2; handheld remote controller; visualization PC | Dex3-1 tactile dexterous hands × 2; handheld remote controller; visualization PC | BrainCo Revo 2 Basic hands × 2; handheld remote controller; visualization PC | BrainCo Revo 2 Tactile hands × 2; handheld remote controller; visualization PC |
| Whole-unit warranty | 12 months | 12 months | 12 months | 12 months | 12 months | 12 months | 12 months | 12 months | 12 months | 12 months |
| Configuration | G1-D Standard A, G1-D Standard B, G1-D Standard C, G1-D Standard D, G1-D Standard E, G1-D Ultimate A, G1-D Ultimate B, G1-D Ultimate C, G1-D Ultimate D, G1-D Ultimate E |
|---|---|
| Brand | Unitree |
| Robot type | Humanoid mobile manipulator |
| Application | Research, Education, Development, Data collection, Teleoperation |
Unitree G1-D är en avancerad humanoid överkroppsplattform från Unitree Robotics, utvecklad för forskning, datainsamling, fjärrstyrning och utveckling inom robotik och artificiell intelligens.
Plattformen kombinerar två robotarmar med en rörlig midja, höj- och sänkbar konstruktion, sensorer och stöd för olika robothänder och gripdon. Det gör G1-D särskilt relevant för projekt där en robot ska kunna interagera med föremål, samla in data från fysiska arbetsmoment och användas för utveckling av AI-baserade manipulationsfunktioner.
Unitree G1-D finns i flera konfigurationer, från Standard-versioner till Ultimate-versioner med motordriven hjulbas. Valet av konfiguration påverkar bland annat robotens mobilitet, gripfunktion och möjligheter till taktil avkänning.
Unitree G1-D är utvecklad för projekt där data från fysiska interaktioner behövs för utveckling och utvärdering av robotstyrning och AI-modeller. Genom att samla in information om robotens rörelser, sensordata och hantering av objekt kan utvecklingsteam arbeta med datadrivna metoder för robotmanipulation.
Plattformen är särskilt relevant för forskning inom embodied AI, imitation learning och andra metoder där en robot lär sig eller styrs utifrån data från fysiska uppgifter.
G1-D kan användas i projekt med teleoperation, där en operatör fjärrstyr robotens rörelser för att genomföra arbetsmoment eller samla in demonstrationsdata. Det gör plattformen relevant för utveckling av styrsystem, operatörsgränssnitt och metoder för att överföra mänskliga rörelser till robotiska armar och gripdon.
Den praktiska funktionaliteten beror på vald konfiguration, styrutrustning och programvara.
Med två robotarmar och stöd för olika ändeffektorer kan Unitree G1-D användas för forskning och utveckling inom grepp, hantering och förflyttning av föremål. Beroende på konfiguration kan plattformen utrustas med tvåfingersgripdon, trefingrade robothänder eller femfingrade fingerfärdiga händer.
För projekt där roboten behöver registrera kontakt med objekt finns även konfigurationer med taktil avkänning. Det gör G1-D relevant för utveckling av AI-baserad manipulation, greppstyrning och uppgifter där robotens interaktion med föremål är central.
Unitree G1-D kan användas som en fysisk forskningsplattform för utveckling av AI-system som ska förstå och påverka sin omgivning. Plattformen ger möjligheter att arbeta med perception, rörelsestyrning, datainsamling och fysisk interaktion i ett sammanhängande robotsystem.
Utveckling av självständiga arbetsuppgifter kräver normalt ytterligare programmering, AI-modeller, integration och tester.
G1-D kan också användas för att undersöka hur specifika hanteringsmoment kan genomföras med robotarmar och olika gripdon. Det kan exempelvis handla om att testa gripstrategier, analysera rörelsemönster eller jämföra olika typer av ändeffektorer. Plattformen är därför relevant för företag och forskningsmiljöer som vill utvärdera tekniska möjligheter innan en specialiserad robotapplikation utvecklas.
Unitree G1-D finns i tio konfigurationer på Webot: fem Standard-versioner och fem Ultimate-versioner.
Valet görs främst utifrån två frågor: behöver roboten en motordriven hjulbas, och vilken typ av gripdon eller robothand kräver projektet?
G1-D Standard är ett alternativ för projekt där fokus ligger på robotarmarnas funktioner, objektmanipulation och datainsamling. Standard-konfigurationerna har två robotarmar, rörlig midja och en motordriven vertikalpelare. De saknar den hjuldrivna mobilitet som finns i Ultimate-serien.
Det gör Standard särskilt intressant för forsknings- och testmiljöer där robotplattformen används vid en definierad arbetsstation eller i en kontrollerad uppställning.
G1-D Ultimate bygger vidare på överkroppsplattformen och har en motordriven hjulbas för förflyttning mellan positioner. Det ger möjlighet att utveckla och undersöka arbetsmoment där både mobilitet och objektmanipulation ingår. Ultimate-serien är relevant för projekt som kräver att roboten kan förflytta sig i en miljö och arbeta vid olika positioner.
Vilka navigations- och manipulationsuppgifter som kan genomföras autonomt beror på systemets programvara och den utveckling som görs för tillämpningen.
Både Standard och Ultimate finns med olika alternativ för robotens händer och gripdon.
Dex1-1-gripdon är relevanta för projekt med tvåfingersgrepp och hantering av föremål.
Dex3-1-robothänder erbjuder tre fingrar och flera frihetsgrader för mer avancerad manipulation. Det finns alternativ både med och utan taktil avkänning.
BrainCo Revo 2 Basic erbjuder femfingrad manipulation för projekt där handens konstruktion och flera rörliga fingrar är viktiga.
BrainCo Revo 2 Tactile kompletterar den femfingrade konstruktionen med taktil avkänning för forskning och utveckling där kontaktinformation är betydelsefull.
Valet av ändeffektor påverkar vilka grepp och manipulationsmoment som kan utvecklas. Kontrollera därför både robotkonfiguration och medföljande utrustning innan beställning.
Unitree G1 och Unitree G1-D är två olika robotplattformar med delvis olika användningsområden.
Unitree G1 är en tvåbent humanoidrobot som lämpar sig för forskning och utveckling inom bland annat humanoid rörelse, balans, styrning och embodied AI.
Unitree G1-D fokuserar i stället på den humanoida överkroppen och användningen av robotarmar, robothänder och gripdon för datainsamling och manipulation. Ultimate-konfigurationerna erbjuder dessutom mobilitet genom en hjulbas.
Om projektet främst handlar om tvåbent gång och humanoid rörelsekontroll är G1 ett relevant alternativ. Om fokus ligger på data från fysiska hanteringsmoment, teleoperation och objektmanipulation kan G1-D vara mer lämplig.
Läs mer om Unitree G1 Humanoid.
För projekt som kräver en annan storlek på robotplattformen eller andra mekaniska förutsättningar kan även Unitree H2-D vara relevant att undersöka.
H2-D är en pelarmonterad humanoid plattform i H2-serien, med konfigurationer för stationär eller mobil användning.
Vilken plattform som passar bäst beror på bland annat arbetsområde, mekaniska krav, val av ändeffektor och projektets mål.
Utforska Unitree H2-D Humanoid.
För Unitree G1-D finns flera alternativ för gripdon och robotiska händer, bland annat Dex1-1, Dex3-1 och BrainCo Revo 2.
Vilken lösning som passar beror på om projektet kräver ett enklare tvåfingersgrepp, fingerfärdig manipulation eller taktil återkoppling.
Observera att robothänder och gripdon även kan ingå i en vald G1-D-konfiguration. Kontrollera därför leveransomfattning och kompatibilitet innan du väljer separata tillbehör.
Se tillbehör och robothänder till Unitree G1-D.
När du väljer Unitree G1-D är det viktigt att utgå från projektets behov av mobilitet, datainsamling, styrning och objektmanipulation.
På produktsidan kan du jämföra Standard- och Ultimate-konfigurationerna samt välja mellan olika gripdon och robotiska händer.
Välj önskad konfiguration och kontakta Webot för offert på Unitree G1-D.
Unitree G1-D är en konfigurerbar humanoid överkroppsplattform från Unitree Robotics för datainsamling, fjärrstyrning, robotmanipulation och AI-utveckling. Den har två robotarmar, en rörlig midja och en höj- och sänkbar konstruktion. Plattformen finns i både Standard- och Ultimate-konfigurationer med olika gripdon och robothänder.
Priset på Unitree G1-D beror på vilken konfiguration, vilka robothänder och vilken övrig utrustning som väljs. Webot erbjuder produkten via offert, där slutlig konfiguration, pris och leveransvillkor bekräftas utifrån beställningen. Kontakta Webot för en offert på önskad G1-D-version.
G1-D Standard är en humanoid överkroppsplattform med två robotarmar, rörlig midja och motordriven vertikalpelare. G1-D Ultimate har dessutom en motordriven hjulbas för förflyttning mellan olika positioner. Båda serierna finns med flera alternativ för gripdon och robotiska händer.
G1-D Ultimate har en motordriven hjulbas som möjliggör förflyttning i en miljö. Standard-versionerna saknar motsvarande hjuldrivna mobilitet. Vilka navigeringsfunktioner som kan användas, och i vilken grad roboten kan arbeta autonomt, beror på konfiguration och programvara.
Unitree G1-D är avsedd för forskning och utveckling och har stöd för vidareutveckling enligt produktinformationen. Plattformen kan användas för att utveckla styrning, datainsamling och robotmanipulation. Vilka utvecklingsgränssnitt och programvarufunktioner som är tillgängliga bör kontrolleras för den aktuella konfigurationen.
G1-D erbjuds med olika ändeffektorer, bland annat Dex1-1-gripdon, trefingrade Dex3-1-händer och femfingrade BrainCo Revo 2-händer. Det finns även alternativ med taktil avkänning. Vilka händer som ingår beror på vilken Standard- eller Ultimate-konfiguration som väljs.
Ja. Unitree G1-D är utvecklad för datainsamling och forskning där information om robotens rörelser och interaktion med föremål används för att utveckla och utvärdera AI-modeller. Hur insamling, bearbetning och träning genomförs beror på programvara, styrutrustning och projektets tekniska upplägg.
Unitree G1-D är framför allt en utvecklingsplattform. Den har robotarmar, sensorer och funktioner för rörelse och manipulation, men specialiserade autonoma arbetsuppgifter kan kräva ytterligare programmering, integration och tester. Den bör därför inte betraktas som en färdig lösning för alla typer av automatiserade arbetsmoment.
Unitree G1 är en tvåbent humanoidrobot som bland annat används för forskning om humanoid rörelse, balans och robotstyrning. Unitree G1-D är en humanoid överkroppsplattform som framför allt är utvecklad för datainsamling, fjärrstyrning och objektmanipulation. G1-D Ultimate har dessutom en hjulbas för mobil användning.