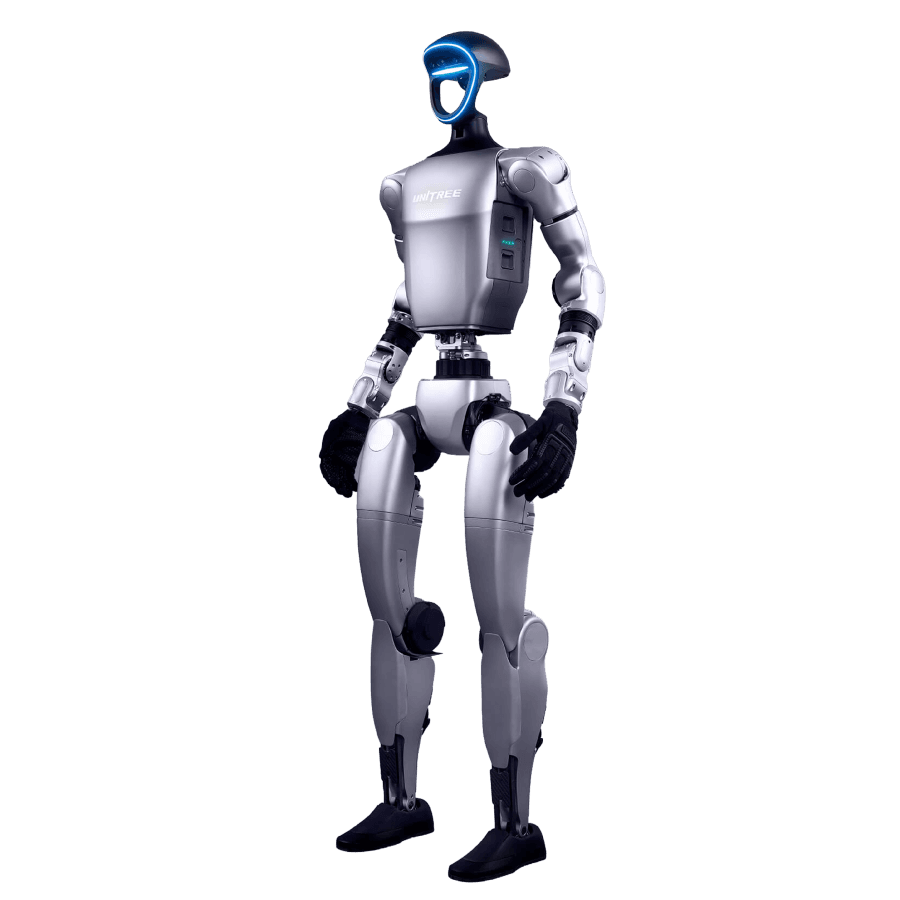
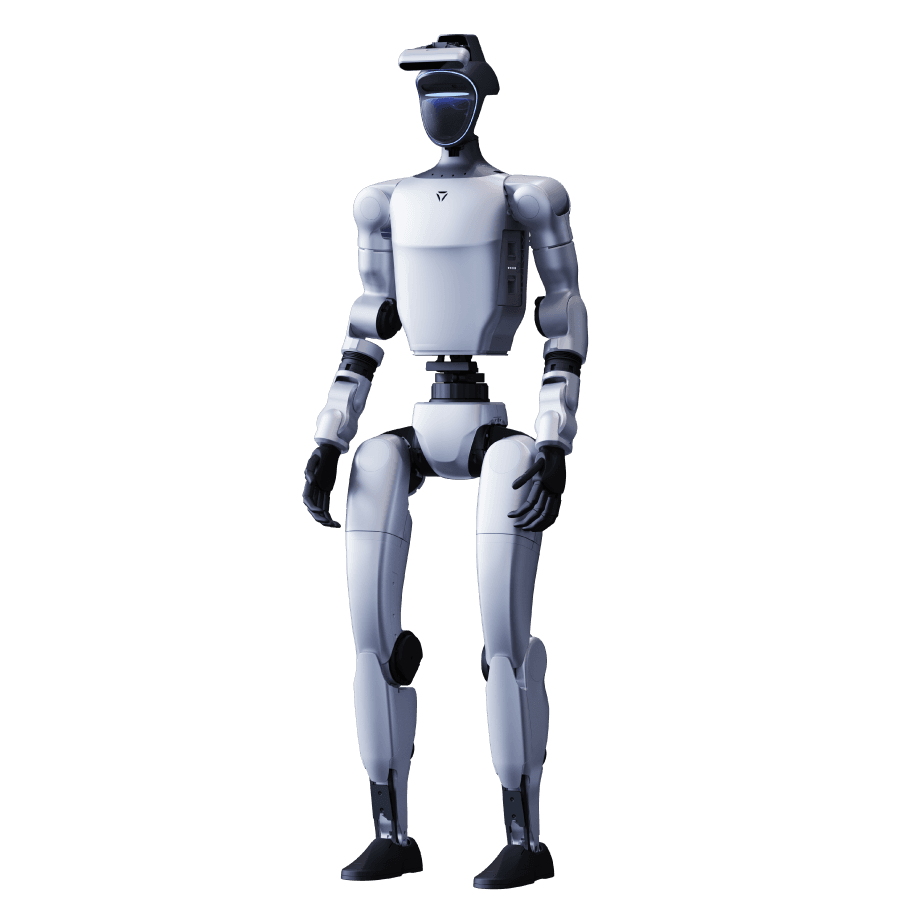
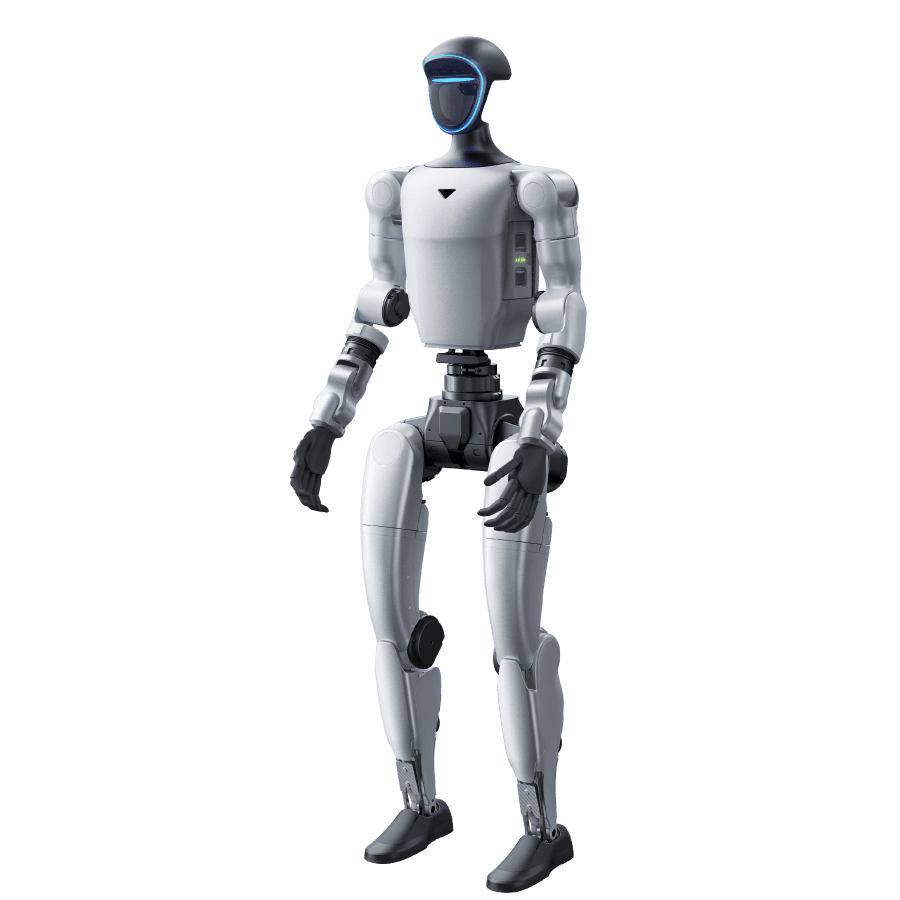
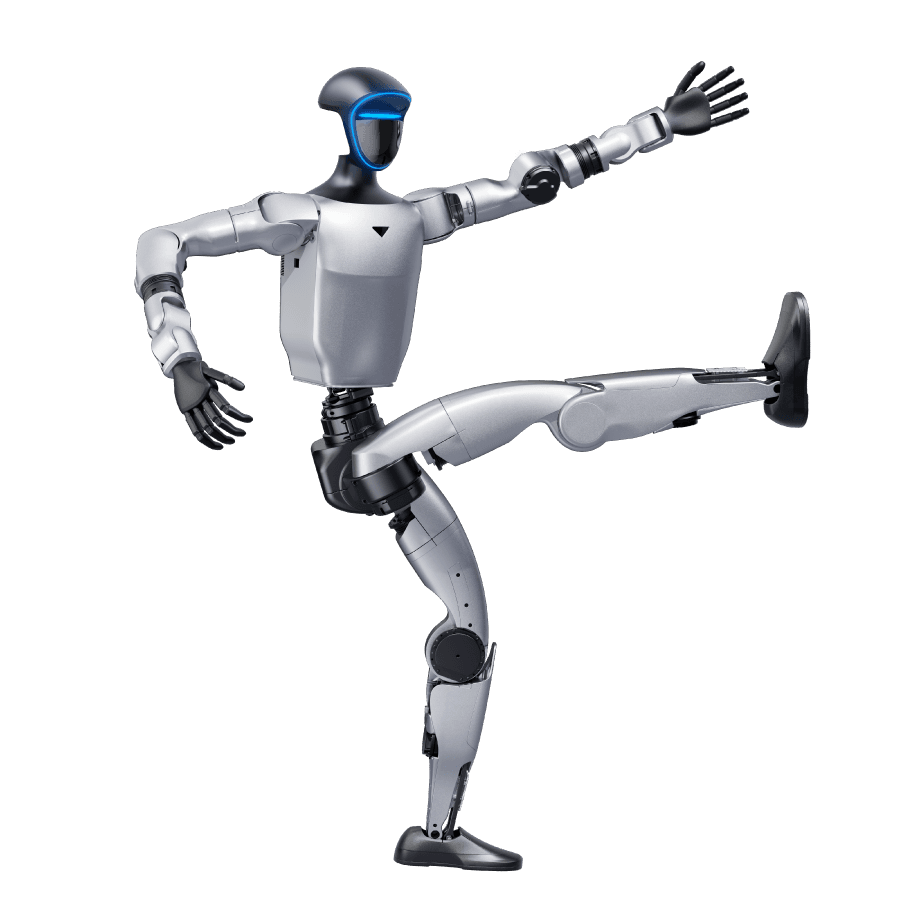
Unitree G1 är en avancerad humanoidrobot för forskning, utbildning, AI-utveckling och robotik. Med människoliknande rörelser, avancerad sensorteknik och flera konfigurationer kan roboten användas inom bland annat embodied AI, rörelseplanering och robotutveckling.
Välj mellan G1 Basic, Pro, E och olika EDU-konfigurationer beroende på projektets krav på funktioner, programmering och robotiska händer.
G1 Basic är den mångsidiga grundmodellen i Unitree G1-serien.
Den här konfigurationen säljs via offert. Slutlig omfattning, leverans och prissättning bekräftas i offerten.
G1 Pro bygger vidare på G1 Basic med förstärkt maskinvara, utökat rörelseomfång och inbyggd högpresterande beräkningskapacitet.
Slutlig kompatibilitet, konfiguration, leverans och prissättning bekräftas i offerten.
G1 E kombinerar den uppgraderade mekaniska G1-plattformen med stöd för vidareutveckling.
Slutlig kompatibilitet, konfiguration, leverans och prissättning bekräftas i offerten.
G1 Edu Standard kompletterar maskinvaran i G1 Basic med en heltäckande utvecklingsplattform.
Slutlig kompatibilitet, konfiguration, leverans och prissättning bekräftas i offerten.
G1 Edu Plus innehåller utvecklingsplattformen från G1 Edu Standard och utökar robotens rörlighet i överkroppen.
Slutlig kompatibilitet, konfiguration, leverans och prissättning bekräftas i offerten.
G1 Edu Ultimate A kombinerar hela G1 Edu Plus-plattformen med Dex3-1 kraftstyrda fingerfärdiga händer.
Slutlig kompatibilitet, konfiguration, leverans och prissättning bekräftas i offerten.
G1 Edu Ultimate B kompletterar hela G1 Edu Plus-plattformen med taktila Dex3-1 fingerfärdiga händer.
Slutlig kompatibilitet, konfiguration, leverans och prissättning bekräftas i offerten.
G1 Edu Ultimate C kombinerar G1 Edu Plus med Inspire DFQ fingerfärdiga händer.
Slutlig kompatibilitet, konfiguration, leverans och prissättning bekräftas i offerten.
G1 Edu Ultimate D kombinerar G1 Edu Plus med taktila Inspire E2 fingerfärdiga händer.
Slutlig kompatibilitet, konfiguration, leverans och prissättning bekräftas i offerten.
G1 Edu Ultimate E kombinerar G1 Edu Plus med BrainCo Revo 2 Basic fingerfärdiga händer.
Slutlig kompatibilitet, konfiguration, leverans och prissättning bekräftas i offerten.
G1 Edu Ultimate F kombinerar G1 Edu Plus med BrainCo Revo 2 Touch fingerfärdiga händer.
Slutlig kompatibilitet, konfiguration, leverans och prissättning bekräftas i offerten.
G1 Edu Ultimate G utrustar G1 Edu Plus-plattformen med DEX 2/5 senvajerstyrda fingerfärdiga händer.
Slutlig kompatibilitet, konfiguration, leverans och prissättning bekräftas i offerten.
G1 Edu Ultimate H kombinerar G1 Edu Plus med två Dex1-1 Gripper Plus ändeffektorer.
Slutlig kompatibilitet, konfiguration, leverans och prissättning bekräftas i offerten.
G1 Edu Ultimate I kombinerar G1 Edu Plus med två mycket artikulerade Wuji Hand2 ändeffektorer.
Slutlig kompatibilitet, konfiguration, leverans och prissättning bekräftas i offerten.
G1 Edu Professional A kombinerar G1 Edu Standard med Dex3-1 kraftstyrda fingerfärdiga händer.
Slutlig kompatibilitet, konfiguration, leverans och prissättning bekräftas i offerten.
G1 Edu Professional B kombinerar G1 Edu Standard med taktila Dex3-1 fingerfärdiga händer.
Slutlig kompatibilitet, konfiguration, leverans och prissättning bekräftas i offerten.
G1 Edu Professional E kombinerar G1 Edu Standard med BrainCo Revo 2 Basic fingerfärdiga händer.
Slutlig kompatibilitet, konfiguration, leverans och prissättning bekräftas i offerten.
G1 Edu Professional F kombinerar G1 Edu Standard med två BrainCo Revo 2 Touch fingerfärdiga händer.
Slutlig kompatibilitet, konfiguration, leverans och prissättning bekräftas i offerten.
G1 Edu Professional G utrustar G1 Edu Standard med DEX 2/5 senvajerstyrda fingerfärdiga händer.
Slutlig kompatibilitet, konfiguration, leverans och prissättning bekräftas i offerten.
G1 Edu Professional H kombinerar G1 Edu Standard med två Dex1-1 Gripper Plus ändeffektorer.
Slutlig kompatibilitet, konfiguration, leverans och prissättning bekräftas i offerten.
G1 Edu Professional I kombinerar G1 Edu Standard med två Wuji Hand2 ändeffektorer.
Slutlig kompatibilitet, konfiguration, leverans och prissättning bekräftas i offerten.
G1-Comp är en tävlingsinriktad G1-konfiguration med utökad perception, huvudrörelser och inbyggd beräkningskapacitet.
Slutlig kompatibilitet, konfiguration, leverans och prissättning bekräftas i offerten.
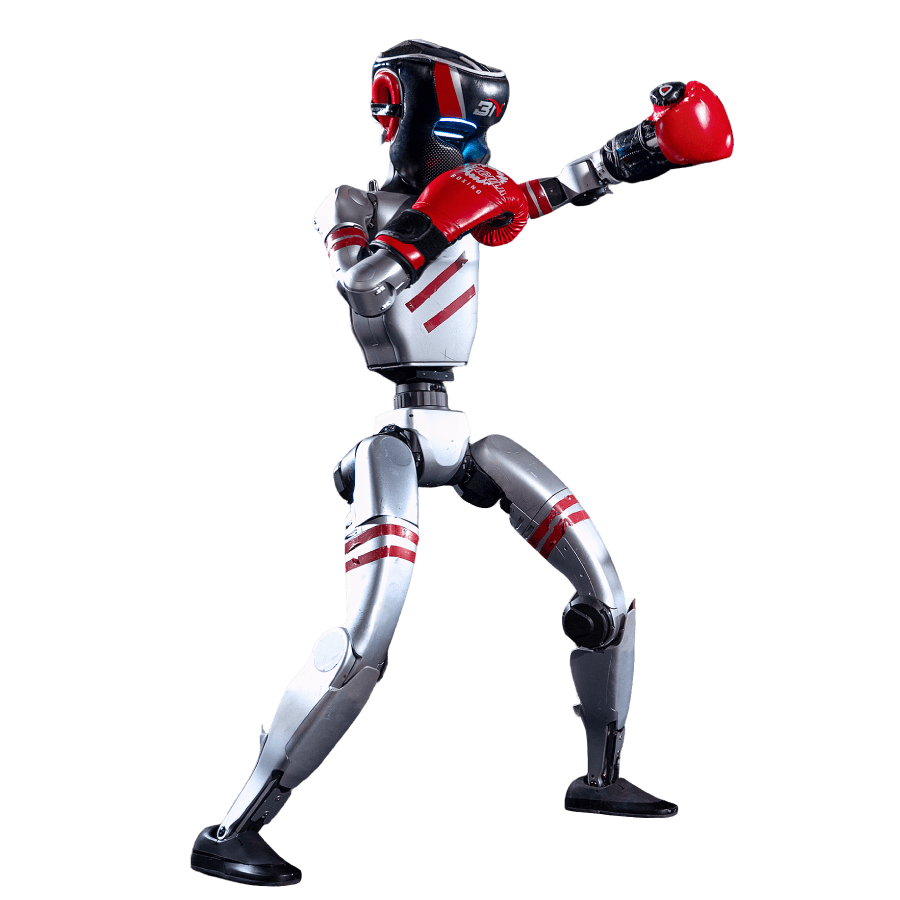
G1 Edu Boxing innehåller funktionerna från G1 Edu Plus och är förstärkt för den dokumenterade kampanvändningen.
Den här konfigurationen säljs via offert. Villkor för underhåll, reservdelar och bidrag ska bekräftas i offerten.
| Specification | G1 Basic | G1 Pro | G1 E | G1 Edu Standard | G1 Edu Plus | G1 Edu Ultimate A | G1 Edu Ultimate B | G1 Edu Ultimate C | G1 Edu Ultimate D | G1 Edu Ultimate E | G1 Edu Ultimate F | G1 Edu Ultimate G | G1 Edu Ultimate H | G1 Edu Ultimate I | G1 Edu Professional A | G1 Edu Professional B | G1 Edu Professional E | G1 Edu Professional F | G1 Edu Professional G | G1 Edu Professional H | G1 Edu Professional I | G1-Comp | G1 Edu Boxing |
|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|
| General | |||||||||||||||||||||||
| Manufacturer | Unitree | Unitree | Unitree | Unitree | Unitree | Unitree | Unitree | Unitree | Unitree | Unitree | Unitree | Unitree | Unitree | Unitree | Unitree | Unitree | Unitree | Unitree | Unitree | Unitree | Unitree | Unitree | Unitree |
| Model / edition | G1 Series | G1 Series | G1 Series | G1 Series | G1 Series | G1 Series | G1 Series | G1 Series | G1 Series | G1 Series | G1 Series | G1 Series | G1 Series | G1 Series | G1 Series | G1 Series | G1 Series | G1 Series | G1 Series | G1 Series | G1 Series | G1 Series | G1 Series |
| Robot type | Humanoid robot | Humanoid robot | Humanoid robot | Humanoid robot | Humanoid robot | Humanoid robot | Humanoid robot | Humanoid robot | Humanoid robot | Humanoid robot | Humanoid robot | Humanoid robot | Humanoid robot | Humanoid robot | Humanoid robot | Humanoid robot | Humanoid robot | Humanoid robot | Humanoid robot | Humanoid robot | Humanoid robot | Humanoid robot | Humanoid robot |
| Main market description | Light industrial, service, residential and academic applications | Tourism, commercial events, media entertainment and content creation | Tourism, commercial events, media entertainment and content creation | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – |
| Includes functions of | – | G1 Basic | G1 Basic | G1 Basic | G1 Edu Standard | G1 Edu Plus | G1 Edu Plus | G1 Edu Plus | G1 Edu Plus | G1 Edu Plus | G1 Edu Plus | G1 Edu Plus | G1 Edu Plus | G1 Edu Plus | G1 Edu Standard | G1 Edu Standard | G1 Edu Standard | G1 Edu Standard | G1 Edu Standard | G1 Edu Standard | G1 Edu Standard | – | G1 Edu Plus |
| Dimensions & Weight | |||||||||||||||||||||||
| Standing dimensions (H × W × D) | 1 320 × 450 × 200 mm | 1 320 × 450 × 200 mm | 1 320 × 450 × 200 mm | 1 320 × 450 × 200 mm | 1 320 × 450 × 200 mm | 1 320 × 450 × 200 mm | 1 320 × 450 × 200 mm | 1 320 × 450 × 200 mm | 1 320 × 450 × 200 mm | 1 320 × 450 × 200 mm | 1 320 × 450 × 200 mm | 1 320 × 450 × 200 mm | 1 320 × 450 × 200 mm | 1 320 × 450 × 200 mm | 1 320 × 450 × 200 mm | 1 320 × 450 × 200 mm | 1 320 × 450 × 200 mm | 1 320 × 450 × 200 mm | 1 320 × 450 × 200 mm | 1 320 × 450 × 200 mm | 1 320 × 450 × 200 mm | 1 320 × 450 × 200 mm | 1 320 × 450 × 200 mm |
| Folded dimensions (H × W × D) | 690 × 450 × 300 mm | 690 × 450 × 300 mm | 690 × 450 × 300 mm | 690 × 450 × 300 mm | 690 × 450 × 300 mm | 690 × 450 × 300 mm | 690 × 450 × 300 mm | 690 × 450 × 300 mm | 690 × 450 × 300 mm | 690 × 450 × 300 mm | 690 × 450 × 300 mm | 690 × 450 × 300 mm | 690 × 450 × 300 mm | 690 × 450 × 300 mm | 690 × 450 × 300 mm | 690 × 450 × 300 mm | 690 × 450 × 300 mm | 690 × 450 × 300 mm | 690 × 450 × 300 mm | 690 × 450 × 300 mm | 690 × 450 × 300 mm | 690 × 450 × 300 mm | 690 × 450 × 300 mm |
| Robot weight (with battery) | 35 kg | 35 kg | 35 kg | 35 kg | 35 kg | 35 kg | 35 kg | 35 kg | 35 kg | 35 kg | 35 kg | 35 kg | 35 kg | 35 kg | 35 kg | 35 kg | 35 kg | 35 kg | 35 kg | 35 kg | 35 kg | 35 kg | 35 kg |
| Leg length (thigh + shin/calf) | 0,60 m | 0,60 m | 0,60 m | 0,60 m | 0,60 m | 0,60 m | 0,60 m | 0,60 m | 0,60 m | 0,60 m | 0,60 m | 0,60 m | 0,60 m | 0,60 m | 0,60 m | 0,60 m | 0,60 m | 0,60 m | 0,60 m | 0,60 m | 0,60 m | 0,60 m | 0,60 m |
| Arm span | 0,45 m | 0,45 m | 0,45 m | 0,45 m | 0,45 m | 0,45 m | 0,45 m | 0,45 m | 0,45 m | 0,45 m | 0,45 m | 0,45 m | 0,45 m | 0,45 m | 0,45 m | 0,45 m | 0,45 m | 0,45 m | 0,45 m | 0,45 m | 0,45 m | 0,45 m | 0,45 m |
| Degrees of Freedom | |||||||||||||||||||||||
| Total robot/system DoF | 23 | 29 | 29 | 23 | 29 | 43 | 43 | 41 | 41 | 41 | 41 | 33 | 31 | 69 | 37 | 37 | 35 | 35 | 27 | 25 | 63 | 25 | 29 |
| Single leg DoF | 6 | 6 | 6 | 6 | 6 | 6 | 6 | 6 | 6 | 6 | 6 | 6 | 6 | 6 | 6 | 6 | 6 | 6 | 6 | 6 | 6 | 6 | 6 |
| Waist DoF | 1 | 3 | 3 | 1 | 3 | 3 | 3 | 3 | 3 | 3 | 3 | 3 | 3 | 3 | 1 | 1 | 1 | 1 | 1 | 1 | 1 | 1 | 3 |
| Single arm DoF | 5 | 7 | 7 | 5 | 7 | 7 | 7 | 7 | 7 | 7 | 7 | 7 | 7 | 7 | 5 | 5 | 5 | 5 | 5 | 5 | 5 | 5 | 7 |
| Head DoF | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | 2 | – |
| Single hand/end-effector DoF | – | – | – | – | – | 7 | 7 | 6 | 6 | 6 | 6 | 2 | 1 | 20 | 7 | 7 | 6 | 6 | 2 | 1 | 20 | – | – |
| Single hand joint count | – | – | – | – | – | – | – | 12 | 12 | 11 | 11 | 10 | – | – | – | – | 11 | 11 | 10 | – | – | – | – |
| Performance & Joint Motion | |||||||||||||||||||||||
| Maximum knee torque | 90 N·m | 120 N·m | 120 N·m | 120 N·m | 120 N·m | 120 N·m | 120 N·m | 120 N·m | 120 N·m | 120 N·m | 120 N·m | 120 N·m | 120 N·m | 120 N·m | 120 N·m | 120 N·m | 120 N·m | 120 N·m | 120 N·m | 120 N·m | 120 N·m | 120 N·m | 120 N·m |
| Maximum arm payload | 2 kg | 3 kg | 3 kg | 3 kg | 3 kg | 3 kg | 3 kg | 3 kg | 3 kg | 3 kg | 3 kg | 3 kg | 3 kg | 3 kg | 3 kg | 3 kg | 3 kg | 3 kg | 3 kg | 3 kg | 3 kg | 3 kg | 3 kg |
| Waist Z-axis range | ±155 ° | ±155 ° | ±155 ° | ±155 ° | ±155 ° | ±155 ° | ±155 ° | ±155 ° | ±155 ° | ±155 ° | ±155 ° | ±155 ° | ±155 ° | ±155 ° | ±155 ° | ±155 ° | ±155 ° | ±155 ° | ±155 ° | ±155 ° | ±155 ° | ±155 ° | ±155 ° |
| Waist X-axis range | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | ±45 ° | – |
| Waist Y-axis range | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | ±30 ° | – |
| Knee range | 0–165 ° | 0–165 ° | 0–165 ° | 0–165 ° | 0–165 ° | 0–165 ° | 0–165 ° | 0–165 ° | 0–165 ° | 0–165 ° | 0–165 ° | 0–165 ° | 0–165 ° | 0–165 ° | 0–165 ° | 0–165 ° | 0–165 ° | 0–165 ° | 0–165 ° | 0–165 ° | 0–165 ° | 0–165 ° | 0–165 ° |
| Hip pitch (P) range | ±154 ° | ±154 ° | ±154 ° | ±154 ° | ±154 ° | ±154 ° | ±154 ° | ±154 ° | ±154 ° | ±154 ° | ±154 ° | ±154 ° | ±154 ° | ±154 ° | ±154 ° | ±154 ° | ±154 ° | ±154 ° | ±154 ° | ±154 ° | ±154 ° | ±154 ° | ±154 ° |
| Hip roll (R) range | '-30–+170 ° | '-30–+170 ° | '-30–+170 ° | '-30–+170 ° | '-30–+170 ° | '-30–+170 ° | '-30–+170 ° | '-30–+170 ° | '-30–+170 ° | '-30–+170 ° | '-30–+170 ° | '-30–+170 ° | '-30–+170 ° | '-30–+170 ° | '-30–+170 ° | '-30–+170 ° | '-30–+170 ° | '-30–+170 ° | '-30–+170 ° | '-30–+170 ° | '-30–+170 ° | '-30–+170 ° | '-30–+170 ° |
| Hip yaw (Y) range | ±158 ° | ±158 ° | ±158 ° | ±158 ° | ±158 ° | ±158 ° | ±158 ° | ±158 ° | ±158 ° | ±158 ° | ±158 ° | ±158 ° | ±158 ° | ±158 ° | ±158 ° | ±158 ° | ±158 ° | ±158 ° | ±158 ° | ±158 ° | ±158 ° | ±158 ° | ±158 ° |
| Head pitch (P) range | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | '-90–+22.7 ° | – |
| Head yaw (Y) range | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | '-50–+50 ° | – |
| Wrist pitch (P) range | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | ±92.5 ° | – |
| Wrist yaw (Y) range | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | ±92.5 ° | – |
| Hardware & Systems | |||||||||||||||||||||||
| Waist motor | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | IM6010-R32 |
| Wiring | Hollow internal routing for all joints | Hollow internal routing for all joints | Hollow internal routing for all joints | Hollow internal routing for all joints | Hollow internal routing for all joints | Hollow internal routing for all joints | Hollow internal routing for all joints | Hollow internal routing for all joints | Hollow internal routing for all joints | Hollow internal routing for all joints | Hollow internal routing for all joints | Hollow internal routing for all joints | Hollow internal routing for all joints | Hollow internal routing for all joints | Hollow internal routing for all joints | Hollow internal routing for all joints | Hollow internal routing for all joints | Hollow internal routing for all joints | Hollow internal routing for all joints | Hollow internal routing for all joints | Hollow internal routing for all joints | Hollow internal routing for all joints | Hollow internal routing for all joints |
| Encoders | Dual encoders per joint | Dual encoders per joint | Dual encoders per joint | Dual encoders per joint | Dual encoders per joint | Dual encoders per joint | Dual encoders per joint | Dual encoders per joint | Dual encoders per joint | Dual encoders per joint | Dual encoders per joint | Dual encoders per joint | Dual encoders per joint | Dual encoders per joint | Dual encoders per joint | Dual encoders per joint | Dual encoders per joint | Dual encoders per joint | Dual encoders per joint | Dual encoders per joint | Dual encoders per joint | Dual encoders per joint | Dual encoders per joint |
| Cooling | Localized air cooling | Localized air cooling | Localized air cooling | Localized air cooling | Localized air cooling | Localized air cooling | Localized air cooling | Localized air cooling | Localized air cooling | Localized air cooling | Localized air cooling | Localized air cooling | Localized air cooling | Localized air cooling | Localized air cooling | Localized air cooling | Localized air cooling | Localized air cooling | Localized air cooling | Localized air cooling | Localized air cooling | Localized air cooling | Localized air cooling |
| Power system | 13S battery | 13S battery | 13S battery | 13S battery | 13S battery | 13S battery | 13S battery | 13S battery | 13S battery | 13S battery | 13S battery | 13S battery | 13S battery | 13S battery | 13S battery | 13S battery | 13S battery | 13S battery | 13S battery | 13S battery | 13S battery | 13S battery | 13S battery |
| Battery & Charging | |||||||||||||||||||||||
| Battery capacity | 9 000 mAh | 9 000 mAh | 9 000 mAh | 9 000 mAh | 9 000 mAh | 9 000 mAh | 9 000 mAh | 9 000 mAh | 9 000 mAh | 9 000 mAh | 9 000 mAh | 9 000 mAh | 9 000 mAh | 9 000 mAh | 9 000 mAh | 9 000 mAh | 9 000 mAh | 9 000 mAh | 9 000 mAh | 9 000 mAh | 9 000 mAh | 9 000 mAh | 9 000 mAh |
| Battery life | 2 hours | 2 hours | 2 hours | 2 hours | 2 hours | 2 hours | 2 hours | 2 hours | 2 hours | 2 hours | 2 hours | 2 hours | 2 hours | 2 hours | 2 hours | 2 hours | 2 hours | 2 hours | 2 hours | 2 hours | 2 hours | 2 hours | 2 hours |
| Charger output | 54 V / 5 A | 54 V / 5 A | 54 V / 5 A | 54 V / 5 A | 54 V / 5 A | 54 V / 5 A | 54 V / 5 A | 54 V / 5 A | 54 V / 5 A | 54 V / 5 A | 54 V / 5 A | 54 V / 5 A | 54 V / 5 A | 54 V / 5 A | 54 V / 5 A | 54 V / 5 A | 54 V / 5 A | 54 V / 5 A | 54 V / 5 A | 54 V / 5 A | 54 V / 5 A | 54 V / 5 A | 54 V / 5 A |
| Compute & Software | |||||||||||||||||||||||
| Base compute | 8-core high-performance CPU | 8-core high-performance CPU | 8-core high-performance CPU | 8-core high-performance CPU | 8-core high-performance CPU | 8-core high-performance CPU | 8-core high-performance CPU | 8-core high-performance CPU | 8-core high-performance CPU | 8-core high-performance CPU | 8-core high-performance CPU | 8-core high-performance CPU | 8-core high-performance CPU | 8-core high-performance CPU | 8-core high-performance CPU | 8-core high-performance CPU | 8-core high-performance CPU | 8-core high-performance CPU | 8-core high-performance CPU | 8-core high-performance CPU | 8-core high-performance CPU | 8-core high-performance CPU | 8-core high-performance CPU |
| High-compute module | – | Built-in high-performance expansion computing module | Built-in high-performance expansion computing module | Built-in high-performance expansion computing module | Built-in high-performance expansion computing module | Built-in high-performance expansion computing module | Built-in high-performance expansion computing module | Built-in high-performance expansion computing module | Built-in high-performance expansion computing module | Built-in high-performance expansion computing module | Built-in high-performance expansion computing module | Built-in high-performance expansion computing module | Built-in high-performance expansion computing module | Built-in high-performance expansion computing module | Built-in high-performance expansion computing module | Built-in high-performance expansion computing module | Built-in high-performance expansion computing module | Built-in high-performance expansion computing module | Built-in high-performance expansion computing module | Built-in high-performance expansion computing module | Built-in high-performance expansion computing module | NVIDIA Jetson Orin package | Built-in high-performance expansion computing module |
| Compute performance | – | 100 TOPS | 100 TOPS | 100 TOPS | 100 TOPS | 100 TOPS | 100 TOPS | 100 TOPS | 100 TOPS | 100 TOPS | 100 TOPS | 100 TOPS | 100 TOPS | 100 TOPS | 100 TOPS | 100 TOPS | 100 TOPS | 100 TOPS | 100 TOPS | 100 TOPS | 100 TOPS | 100 TOPS | 100 TOPS |
| Expansion dock / bay | – | Built-in 100 TOPS expansion dock | Built-in 100 TOPS expansion dock | Built-in 100 TOPS expansion dock | Built-in 100 TOPS expansion dock | Built-in 100 TOPS expansion dock | Built-in 100 TOPS expansion dock | Built-in 100 TOPS expansion dock | Built-in 100 TOPS expansion dock | Built-in 100 TOPS expansion dock | Built-in 100 TOPS expansion dock | Built-in 100 TOPS expansion dock | Built-in 100 TOPS expansion dock | Built-in 100 TOPS expansion dock | Built-in 100 TOPS expansion dock | Built-in 100 TOPS expansion dock | Built-in 100 TOPS expansion dock | Built-in 100 TOPS expansion dock | Built-in 100 TOPS expansion dock | Built-in 100 TOPS expansion dock | Built-in 100 TOPS expansion dock | Built-in 100 TOPS expansion bay | Built-in 100 TOPS expansion dock |
| Navigation and positioning software | – | Navigation and positioning software | Navigation and positioning software | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – |
| AI algorithms and technical support | – | – | AI algorithms included | AI algorithms included | AI algorithms included | AI algorithms included | AI algorithms included | AI algorithms included | AI algorithms included | AI algorithms included | AI algorithms included | AI algorithms included | AI algorithms included | AI algorithms included | AI algorithms included | – | – | – | – | – | – | – | AI algorithms included |
| UniStore support | – | Yes | Yes | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – |
| Smart OTA updates | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes |
| Secondary development | No | No | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes |
| Development level | No secondary development | External secondary development is not supported | – | High-level and low-level secondary development | High-level and low-level secondary development | High-level and low-level secondary development | High-level and low-level secondary development | High-level and low-level secondary development | High-level and low-level secondary development | High-level and low-level secondary development | High-level and low-level secondary development | High-level and low-level secondary development | High-level and low-level secondary development | High-level and low-level secondary development | High-level and low-level secondary development | High-level and low-level secondary development | High-level and low-level secondary development | High-level and low-level secondary development | High-level and low-level secondary development | High-level and low-level secondary development | High-level and low-level secondary development | – | High-level and low-level secondary development |
| Technical support | – | – | Technical support included | Technical support, development manuals and ecosystem support | Technical support, development manuals and ecosystem support | Technical support, development manuals and ecosystem support | Technical support, development manuals and ecosystem support | Technical support, development manuals and ecosystem support | Technical support, development manuals and ecosystem support | Technical support, development manuals and ecosystem support | Technical support, development manuals and ecosystem support | Technical support, development manuals and ecosystem support | Technical support, development manuals and ecosystem support | Technical support, development manuals and ecosystem support | Technical support, development manuals and ecosystem support | Technical support, development manuals and ecosystem support | Technical support, development manuals and ecosystem support | Technical support, development manuals and ecosystem support | Technical support, development manuals and ecosystem support | Technical support, development manuals and ecosystem support | Technical support, development manuals and ecosystem support | Technical support included | Technical support, development manuals and ecosystem support |
| Included movements and dances | – | 10+ official movements and dances | 10+ official movements and dances | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – |
| Perception, Audio & Connectivity | |||||||||||||||||||||||
| Depth camera | Intel RealSense D435i × 1 | Intel RealSense D435i × 1 | Intel RealSense D435i × 1 | Intel RealSense D435i × 1 | Intel RealSense D435i × 1 | Intel RealSense D435i × 1 | Intel RealSense D435i × 1 | Intel RealSense D435i × 1 | Intel RealSense D435i × 1 | Intel RealSense D435i × 1 | Intel RealSense D435i × 1 | Intel RealSense D435i × 1 | Intel RealSense D435i × 1 | Intel RealSense D435i × 1 | Intel RealSense D435i × 1 | Intel RealSense D435i × 1 | Intel RealSense D435i × 1 | Intel RealSense D435i × 1 | Intel RealSense D435i × 1 | Intel RealSense D435i × 1 | Intel RealSense D435i × 1 | Intel RealSense D455 × 1 | Intel RealSense D435i × 1 |
| LiDAR | 3D LiDAR × 1 | Ultra-wide-angle 3D LiDAR × 1 | Ultra-wide-angle 3D LiDAR × 1 | 3D LiDAR × 1 | 3D LiDAR × 1 | 3D LiDAR × 1 | 3D LiDAR × 1 | 3D LiDAR × 1 | 3D LiDAR × 1 | 3D LiDAR × 1 | 3D LiDAR × 1 | 3D LiDAR × 1 | 3D LiDAR × 1 | 3D LiDAR × 1 | 3D LiDAR × 1 | 3D LiDAR × 1 | 3D LiDAR × 1 | 3D LiDAR × 1 | 3D LiDAR × 1 | 3D LiDAR × 1 | 3D LiDAR × 1 | 3D LiDAR × 1 | 3D LiDAR × 1 |
| Wrist RGB camera | – | – | – | – | – | Wrist RGB camera | Wrist RGB camera | Wrist RGB camera | Wrist RGB camera | Wrist RGB camera | Wrist RGB camera | – | Wrist RGB camera | Wrist RGB camera | Wrist RGB camera | Wrist RGB camera | Wrist RGB camera | Wrist RGB camera | – | Wrist RGB camera | Wrist RGB camera | – | – |
| Wrist camera FOV | – | – | – | – | – | D 130°; H 120°; V 81° | D 130°; H 120°; V 81° | D 130°; H 120°; V 81° | D 130°; H 120°; V 81° | D 130°; H 120°; V 81° | D 130°; H 120°; V 81° | – | D 130°; H 120°; V 81° | D 130°; H 120°; V 81° | D 130°; H 120°; V 81° | D 130°; H 120°; V 81° | D 130°; H 120°; V 81° | D 130°; H 120°; V 81° | – | D 130°; H 120°; V 81° | D 130°; H 120°; V 81° | – | – |
| Wrist camera resolution | – | – | – | – | – | 1920 × 1080 | 1920 × 1080 | 1920 × 1080 | 1920 × 1080 | 1920 × 1080 | 1920 × 1080 | – | 1920 × 1080 | 1920 × 1080 | 1920 × 1080 | 1920 × 1080 | 1920 × 1080 | 1920 × 1080 | – | 1920 × 1080 | 1920 × 1080 | – | – |
| Audio input | Microphone array | Microphone array | Microphone array | Microphone array | Microphone array | Microphone array | Microphone array | Microphone array | Microphone array | Microphone array | Microphone array | Microphone array | Microphone array | Microphone array | Microphone array | Microphone array | Microphone array | Microphone array | Microphone array | Microphone array | Microphone array | 4-microphone array | Microphone array |
| Audio output | Built-in stereo speakers | Built-in stereo speakers | Built-in stereo speakers | Built-in stereo speakers | Built-in stereo speakers | Built-in stereo speakers | Built-in stereo speakers | Built-in stereo speakers | Built-in stereo speakers | Built-in stereo speakers | Built-in stereo speakers | Built-in stereo speakers | Built-in stereo speakers | Built-in stereo speakers | Built-in stereo speakers | Built-in stereo speakers | Built-in stereo speakers | Built-in stereo speakers | Built-in stereo speakers | Built-in stereo speakers | Built-in stereo speakers | 5 W speaker | Built-in stereo speakers |
| Wi-Fi | WiFi 6 | WiFi 6 | WiFi 6 | WiFi 6 | WiFi 6 | WiFi 6 | WiFi 6 | WiFi 6 | WiFi 6 | WiFi 6 | WiFi 6 | WiFi 6 | WiFi 6 | WiFi 6 | WiFi 6 | WiFi 6 | WiFi 6 | WiFi 6 | WiFi 6 | WiFi 6 | WiFi 6 | WiFi 6 | WiFi 6 |
| Bluetooth | Bluetooth 5.2 | Bluetooth 5.2 | Bluetooth 5.2 | Bluetooth 5.2 | Bluetooth 5.2 | Bluetooth 5.2 | Bluetooth 5.2 | Bluetooth 5.2 | Bluetooth 5.2 | Bluetooth 5.2 | Bluetooth 5.2 | Bluetooth 5.2 | Bluetooth 5.2 | Bluetooth 5.2 | Bluetooth 5.2 | Bluetooth 5.2 | Bluetooth 5.2 | Bluetooth 5.2 | Bluetooth 5.2 | Bluetooth 5.2 | Bluetooth 5.2 | Bluetooth 5.2 | Bluetooth 5.2 |
| Hand / End Effector | |||||||||||||||||||||||
| Hand / end-effector model | – | – | – | – | – | Dex3-1 force-controlled three-finger dexterous hands | Dex3-1 force-controlled three-finger dexterous hands | Inspire DFQ dexterous hands | Inspire E2 dexterous hands | BrainCo Bionic Dexterous Hand Revo 2 Basic | BrainCo Bionic Dexterous Hand Revo 2 Touch | DEX 2/5 tendon-driven dexterous hands | Dex1-1 Gripper Plus × 2 | Wuji Hand2 five-finger dexterous hands | Dex3-1 force-controlled three-finger dexterous hands | Dex3-1 force-controlled three-finger dexterous hands | BrainCo Bionic Dexterous Hand Revo 2 Basic | BrainCo Bionic Dexterous Hand Revo 2 Touch | DEX 2/5 tendon-driven dexterous hands | Dex1-1 Gripper Plus × 2 | Wuji Hand2 five-finger dexterous hands | – | – |
| Tactile sensing | – | – | – | – | – | No | Yes | No | Yes | No | Yes | No | No | No | No | Yes | No | Yes | No | No | No | – | – |
| Single hand/end-effector weight | – | – | – | – | – | 650 g | 650 g | – | 800 g | 383 g | 383 g | 365 g | 550 g | – | 650 g | 650 g | 383 g | 383 g | 365 g | 550 g | – | – | – |
| Hand/end-effector dimensions (H × W × D) | – | – | – | – | – | 175 × 88 × 77 mm | 175 × 88 × 77 mm | – | – | – | – | 151 × 67 × 70 mm | 143 × 78 × 67 mm | Approximately 185 × 80 × 40 (skeleton) mm | 175 × 88 × 77 mm | 175 × 88 × 77 mm | – | – | 151 × 67 × 70 mm | 143 × 78 × 67 mm | Approximately 185 × 80 × 40 (skeleton) mm | – | – |
| Operating voltage | – | – | – | – | – | 12–58 V | 12–58 V | – | 24 V ±10% | – | – | 24–58 V | – | 16–58 V | 12–58 V | 12–58 V | – | – | 24–58 V | – | 16–58 V | – | – |
| Static current | – | – | – | – | – | 58 V @ 0.2 A | 58 V @ 0.2 A | – | 0.25 A | – | – | – | – | – | 58 V @ 0.2 A | 58 V @ 0.2 A | – | – | – | – | – | – | – |
| Maximum current | – | – | – | – | – | – | – | – | 4 A | – | – | – | – | – | – | – | – | – | – | – | – | – | – |
| Communication interface / protocol | – | – | – | – | – | USB | USB | – | – | – | – | – | – | Ethernet 1000BASE-T | USB | USB | – | – | – | – | Ethernet 1000BASE-T | – | – |
| Repeatability / control accuracy | – | – | – | – | – | – | – | ±0.20 mm | ±0.20 mm | 0.1° | 0.1° | – | – | – | – | – | 0.1° | 0.1° | – | – | – | – | – |
| Whole-hand / gripping force | – | – | – | – | – | – | – | – | – | 50 N | 50 N | 10 N fingertip force | 5–120 N | ≥15 N fingertip force | – | – | 50 N | 50 N | 10 N fingertip force | 5–120 N | ≥15 N fingertip force | – | – |
| Single-finger pinch force | – | – | – | – | – | – | – | – | – | 15 N | 15 N | – | – | – | – | – | 15 N | 15 N | – | – | – | – | – |
| Thumb gripping force | – | – | – | – | – | – | – | 6 N | 30 N | – | – | – | – | – | – | – | – | – | – | – | – | – | – |
| Four-finger gripping force | – | – | – | – | – | – | – | 4 N | 28 N | – | – | – | – | – | – | – | – | – | – | – | – | – | – |
| Tactile sensors per hand | – | – | – | – | – | – | 33 per hand | – | 17 per hand | – | – | – | – | – | – | – | – | – | – | – | – | – | – |
| Tactile sensing capabilities | – | – | – | – | – | – | – | – | – | – | Pressure, friction, direction and proximity | – | – | – | – | – | – | Pressure, friction, direction and proximity | – | – | – | – | – |
| Tactile sensor / force-detection range | – | – | – | – | – | – | – | – | 0–30 N | – | – | – | – | – | – | – | – | – | – | – | – | – | – |
| Tactile sensor accuracy | – | – | – | – | – | – | – | – | ≤5% FS | – | – | – | – | – | – | – | – | – | – | – | – | – | – |
| Hand motion speed | – | – | – | – | – | – | – | Thumb lateral swing 235°/s; thumb flexion 150°/s; four-finger flexion 570°/s | Thumb lateral swing >130°/s; thumb bending >130°/s; four-finger bending >200°/s | – | – | – | – | – | – | – | – | – | – | – | – | – | – |
| Stroke | – | – | – | – | – | – | – | – | – | – | – | – | 90 mm | – | – | – | – | – | – | 90 mm | – | – | – |
| Gripping load | – | – | – | – | – | – | – | – | – | – | – | – | 20 kg form-fitting; 5 kg friction grip | – | – | – | – | – | – | 20 kg form-fitting; 5 kg friction grip | – | – | – |
| Closing time | – | – | – | – | – | – | – | – | 0.8 s | – | – | – | 0.24 s | – | – | – | – | – | – | 0.24 s | – | – | – |
| Claw length | – | – | – | – | – | – | – | – | – | – | – | – | 80 mm | – | – | – | – | – | – | 80 mm | – | – | – |
| Minimum grasping diameter | – | – | – | – | – | – | – | – | – | – | – | – | – | 0 mm | – | – | – | – | – | – | 0 mm | – | – |
| Control frequency | – | – | – | – | – | – | – | – | – | – | – | – | – | 1000 Hz × 20 axes | – | – | – | – | – | – | 1000 Hz × 20 axes | – | – |
| Control mode | – | – | – | – | – | – | – | – | – | – | – | – | – | MIT hybrid force/position control | – | – | – | – | – | – | MIT hybrid force/position control | – | – |
| Joint backlash | – | – | – | – | – | – | – | – | – | – | – | – | – | <1° | – | – | – | – | – | – | <1° | – | – |
| Hand / end-effector notes | – | – | – | – | – | Per hand: thumb 3 DoF, index finger 2 DoF and middle finger 2 DoF. | Per hand: thumb 3 DoF, index finger 2 DoF and middle finger 2 DoF. | Gripping-force resolution 0.50 N; thumb lateral rotation range >65°. | – | Height from middle fingertip to palm base: 160 mm. | Height from middle fingertip to palm base: 160 mm. | No external wiring between the dexterous hands and the robot body. | Fingertip position resolution 0.1 mm; high-speed mode 485. | At least 4 movements per second; force-detection range 0–30 N with 0.005 N sensitivity. The document identifies this edition as without tactile sensing. | Per hand: thumb 3 DoF, index finger 2 DoF and middle finger 2 DoF. | Per hand: thumb 3 DoF, index finger 2 DoF and middle finger 2 DoF. | Height from middle fingertip to palm base: 160 mm. | Height from middle fingertip to palm base: 160 mm. | No external wiring between the dexterous hands and the robot body. | Fingertip position resolution 0.1 mm; high-speed mode 485. | At least 4 movements per second; force-detection range 0–30 N with 0.005 N sensitivity. The document identifies this edition as without tactile sensing. | – | – |
| Package, Warranty & Notes | |||||||||||||||||||||||
| Included items | 1 charger; 1 smart battery (quick-release); 1 handheld remote | 1 charger; 1 smart battery (quick-release); 1 handheld remote | 1 charger; 1 smart battery (quick-release); 1 handheld remote | 1 charger; 1 smart battery (quick-release); 1 handheld remote | 1 charger; 1 smart battery (quick-release); 1 handheld remote | 1 charger; 1 smart battery (quick-release); 1 handheld remote | 1 charger; 1 smart battery (quick-release); 1 handheld remote | 1 charger; 1 smart battery (quick-release); 1 handheld remote | 1 charger; 1 smart battery (quick-release); 1 handheld remote | 1 charger; 1 smart battery (quick-release); 1 handheld remote | 1 charger; 1 smart battery (quick-release); 1 handheld remote | 1 charger; 1 smart battery (quick-release); 1 handheld remote | 1 charger; 1 smart battery (quick-release); 1 handheld remote | 1 charger; 1 smart battery (quick-release); 1 handheld remote | 1 charger; 1 smart battery (quick-release); 1 handheld remote | 1 charger; 1 smart battery (quick-release); 1 handheld remote | 1 charger; 1 smart battery (quick-release); 1 handheld remote | 1 charger; 1 smart battery (quick-release); 1 handheld remote | 1 charger; 1 smart battery (quick-release); 1 handheld remote | 1 charger; 1 smart battery (quick-release); 1 handheld remote | 1 charger; 1 smart battery (quick-release); 1 handheld remote | 1 charger; 1 smart battery (quick-release); 1 handheld remote | 1 charger; 1 smart battery (quick-release); 1 handheld remote; 1 combat remote control; 2 boxing gloves; 1 boxing helmet |
| Protective bracket included | No | No | Yes | No | No | No | No | No | No | No | No | No | No | No | No | No | No | No | No | No | No | – | No |
| Whole-unit warranty | 8 months | 12 months | 18 months | 18 months | 18 months | 18 months | 18 months | 18 months | 18 months | 18 months | 18 months | 18 months | 18 months | 18 months | 18 months | 18 months | 18 months | 18 months | 18 months | 18 months | 18 months | 18 months | 0 months |
| Warranty / maintenance terms | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | Default 18-month warranty; extension may be agreed case by case for competition requirements. | No free warranty; robot maintenance and spare-parts replacement are chargeable. |
| Maintenance subsidy | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | RMB 50,000 (USD 7,500); non-cash and restricted to maintenance or spare parts for this product |
| Notes | Protective bracket is not included by default. | Hardware reinforcement and algorithm synergy; protective bracket is not included by default. | The NX expansion module is not included by default and can be purchased separately. | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | Reinforced waist, armour and related hardware. G1 Edu Plus cannot be upgraded to the Combat Edition; the Combat Edition can be used as G1 Edu Plus. |
| Configuration | G1 Basic, G1 Pro, G1 E, G1 Edu Standard, G1 Edu Plus, G1 Edu Ultimate A, G1 Edu Ultimate B, G1 Edu Ultimate C, G1 Edu Ultimate D, G1 Edu Ultimate E, G1 Edu Ultimate F, G1 Edu Ultimate G, G1 Edu Ultimate H, G1 Edu Ultimate I, G1 Edu Professional A, G1 Edu Professional B, G1 Edu Professional E, G1 Edu Professional F, G1 Edu Professional G, G1 Edu Professional H, G1 Edu Professional I, G1 Edu Boxing, G1-Comp |
|---|---|
| Brand | Unitree |
| Robot type | Humanoid robot |
| Application | Research, Education, Development, Service, Entertainment, Competition |
Unitree G1 är en kompakt och avancerad humanoidrobot från Unitree Robotics, utvecklad för forskning, utbildning och utveckling inom robotik och artificiell intelligens. Roboten kombinerar människoliknande rörelser med sensorer, motorstyrning och beräkningskapacitet i en konfigurerbar plattform. Med sin tvåbenta konstruktion och rörliga armar kan Unitree G1 användas för att studera gång, balans, rörelseplanering och interaktion med omgivningen. Roboten är också relevant för utveckling inom embodied AI, där artificiell intelligens används för att styra och samordna en fysisk robots beteende.
Unitree G1 finns i flera konfigurationer med olika tekniska egenskaper och möjligheter till vidareutveckling. Valet av modell beror på om roboten ska användas för exempelvis demonstrationer, forskning, programmering eller avancerad objektmanipulation.
Unitree G1 kan användas som forskningsplattform för att undersöka hur humanoidrobotar rör sig, balanserar och interagerar med sin omgivning. Robotens mekaniska konstruktion, sensorer och styrsystem ger förutsättningar för forskning inom bland annat rörelsekontroll, perception och autonoma robotsystem. För projekt som kräver egen utveckling är det viktigt att välja en konfiguration med stöd för programmering.
För universitet, forskningsinstitutioner och utvecklingsteam erbjuder Unitree G1 EDU en plattform för praktiskt arbete med humanoid robotik. Beroende på konfiguration kan utvecklare arbeta med robotens rörelser, styrning, algoritmer och interaktion med olika miljöer. Det gör roboten relevant för både utbildningsprojekt och mer avancerat utvecklingsarbete.
Unitree G1 kan användas i projekt inom embodied AI, där AI-modeller kopplas till en fysisk robot för att studera hur perception, beslutsfattande och rörelse samverkar. Med en lämplig utvecklingskonfiguration kan robotplattformen användas för att testa och vidareutveckla algoritmer för exempelvis rörelseplanering, styrning och interaktion med omgivningen. Specialiserade AI-tillämpningar kräver normalt ytterligare utveckling, integration och tester.
Utvalda Unitree G1 EDU-konfigurationer är utrustade med robotiska händer eller gripdon som möjliggör forskning inom greppstyrning och hantering av föremål. Beroende på konfiguration kan roboten ha olika typer av ändeffektorer, med exempelvis flera frihetsgrader, kraftstyrning eller taktil avkänning. Det gör plattformen relevant för projekt som undersöker hur humanoidrobotar kan gripa, flytta och manipulera objekt.
Unitree G1 kan även användas för demonstrationer av humanoid robotik, teknikutvärdering och presentationer i utbildnings- och forskningsmiljöer. Robotens tillgängliga rörelser, styrfunktioner och möjligheter till anpassning varierar beroende på modell och programvara.
Unitree G1-serien består av flera konfigurationer med olika förutsättningar för programmering, rörelsekontroll och avancerad manipulation. Rätt val beror på projektets tekniska krav och hur roboten ska användas.
G1 Basic är grundmodellen i serien och erbjuder en tvåbent humanoidplattform med sensorer och fördefinierade funktioner. G1 Pro erbjuder bland annat utökad rörelsefrihet, förstärkt maskinvara och högre beräkningskapacitet jämfört med Basic. Dessa versioner är främst relevanta när fokus ligger på robotplattformens befintliga funktioner snarare än egen programmering, eftersom extern vidareutveckling inte stöds enligt de angivna produktspecifikationerna.
G1 E och EDU-konfigurationerna är alternativ för projekt där egen utveckling och programmering är centrala delar av användningen. G1 EDU finns i flera versioner med olika antal frihetsgrader, rörelseegenskaper och möjligheter att använda robotiska händer. För universitet, forskningsinstitutioner och utvecklingsteam är det särskilt viktigt att jämföra konfigurationernas utvecklingsstöd, motorstyrning och tillgängliga gränssnitt.
G1 EDU Ultimate och Professional omfattar specialiserade konfigurationer med olika robotiska händer och gripdon. Dessa alternativ är särskilt relevanta för forskning och utveckling inom objektmanipulation, greppstyrning och avancerad robotik.
Skillnaderna mellan konfigurationerna omfattar bland annat typ av ändeffektor, antal frihetsgrader och tillgång till taktil avkänning. Använd produktens konfigurationsväljare och jämförelsetabell för att undersöka de tekniska skillnaderna.
För projekt med särskilt fokus på datainsamling, fjärrstyrning och AI-baserad objektmanipulation kan Unitree G1-D vara ett relevant alternativ. Till skillnad från den tvåbenta Unitree G1 är G1-D en humanoid överkroppsplattform med rörlig bas. Den är utvecklad för manipulation, insamling av rörelsedata och utveckling av AI-modeller i fysiska miljöer. Valet mellan Unitree G1 och G1-D beror därför på om projektet främst kräver en tvåbent humanoidrobot eller en mobil manipulationsplattform.
Läs mer om Unitree G1-D och dess konfigurationer.
Unitree G1 kan kombineras med olika typer av robotiska händer, gripdon och andra tillbehör beroende på vald konfiguration. Det finns bland annat lösningar för kraftstyrda grepp, fingerfärdig manipulation och taktil avkänning. Vilka tillbehör som kan användas, och om de ingår i robotens konfiguration, behöver kontrolleras för respektive modell.
Se vårt utbud av tillbehör till Unitree G1.
Valet av Unitree G1 bör utgå från projektets användningsområde, krav på programmering, rörelsefrihet och behov av tillbehör. På produktsidan kan du jämföra olika konfigurationer och se deras tekniska egenskaper.
Kontakta Webot för en offert på Unitree G1 utifrån den konfiguration och utrustning som passar ditt projekt.
Unitree G1 är en tvåbent humanoidrobot från Unitree Robotics, utvecklad för bland annat forskning, utbildning, robotutveckling och AI-baserade tillämpningar. Roboten kombinerar människoliknande rörelser med sensorer, motorstyrning och beräkningskapacitet. Den finns i flera konfigurationer med olika funktioner och möjligheter till vidareutveckling.
Priset på Unitree G1 beror på vilken konfiguration och vilka eventuella tillbehör som väljs. Webot erbjuder roboten via offert, där pris, utrustning och leveransvillkor fastställs utifrån den aktuella beställningen. Kontakta Webot för prisuppgifter på önskad modell.
G1 Basic är grundmodellen, medan G1 Pro erbjuder bland annat utökad rörelsefrihet och högre beräkningskapacitet. G1 EDU är avsedd för forskning och utveckling med stöd för egen programmering. Även G1 E har utvecklingsstöd. EDU-serien omfattar dessutom flera konfigurationer med olika robotiska händer och tekniska egenskaper.
Ja, vissa versioner av Unitree G1 stöder egen programmering och vidareutveckling. G1 E och G1 EDU är alternativ för utvecklingsprojekt. G1 Basic och G1 Pro saknar däremot stöd för extern vidareutveckling enligt produktspecifikationerna. Kontrollera därför utvecklingsstödet för den aktuella konfigurationen innan beställning.
Unitree G1 kan användas inom forskning, utbildning, humanoid robotutveckling, embodied AI och teknikdemonstrationer. Med lämplig konfiguration och programvara kan plattformen även användas för projekt inom rörelseplanering, perception och objektmanipulation. Specialiserade tillämpningar kan kräva ytterligare utveckling och integration.
Den angivna batteritiden för Unitree G1 är cirka två timmar. Den faktiska drifttiden påverkas av bland annat robotens rörelser, belastning, konfiguration och hur den används. Batteritiden bör därför ses som en ungefärlig uppgift och inte som en garanterad drifttid för alla arbetsuppgifter.
Ja, flera G1 EDU-konfigurationer omfattar robotiska händer eller gripdon. Alternativen varierar i antal frihetsgrader, gripfunktioner och eventuell taktil avkänning. Kontrollera alltid vilken utrustning som ingår i den valda konfigurationen och vilka tillbehör som kan köpas separat.
Unitree G1 har avancerade rörelsefunktioner, sensorer och styrsystem, men är inte en färdig autonom lösning för alla typer av arbetsuppgifter. Funktionerna varierar mellan konfigurationerna. Tillämpningar som kräver särskild autonomi, AI-styrning eller integration kan behöva utvecklas och testas separat.
Unitree G1 är en tvåbent humanoidrobot för bland annat forskning, utbildning och robotutveckling. Unitree G1-D är i stället en humanoid överkroppsplattform med rörlig bas, särskilt inriktad på datainsamling, fjärrstyrning och objektmanipulation. Vilken modell som passar bäst beror på projektets krav på mobilitet, rörelseförmåga och utvecklingsmöjligheter.