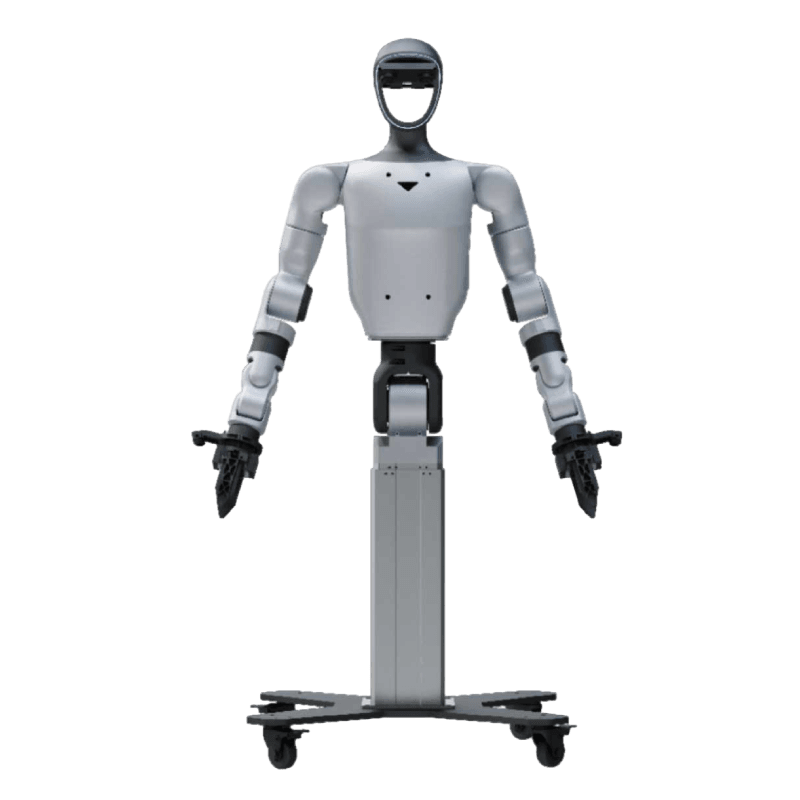
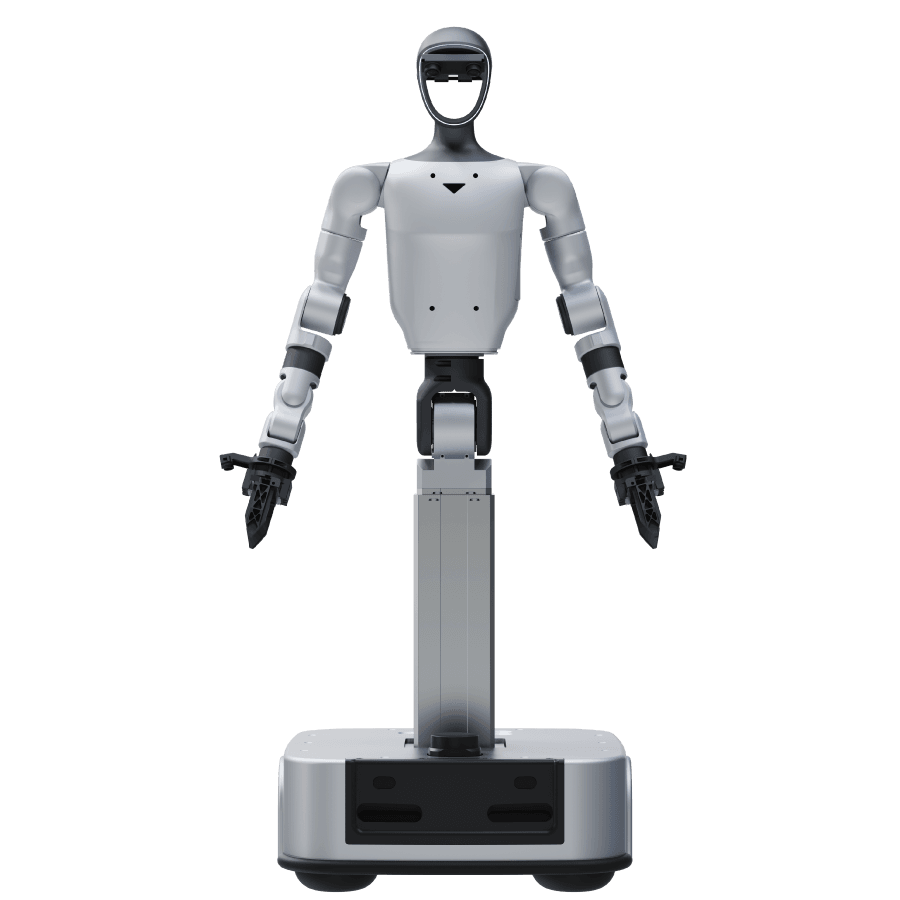
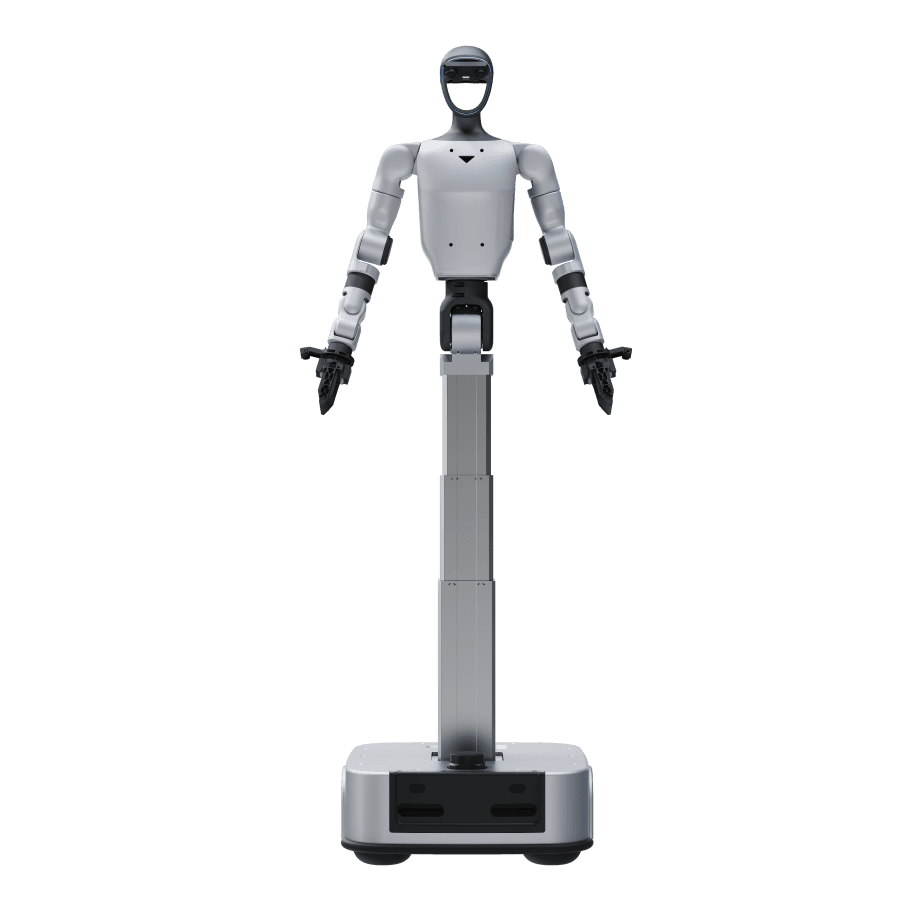
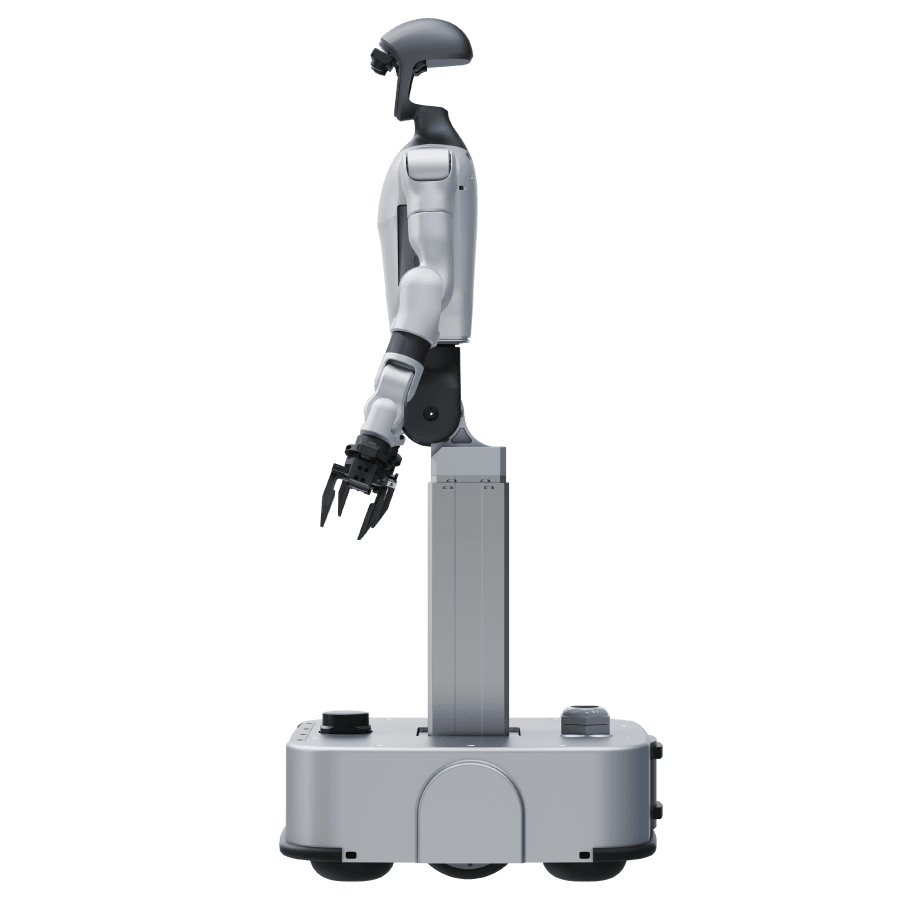
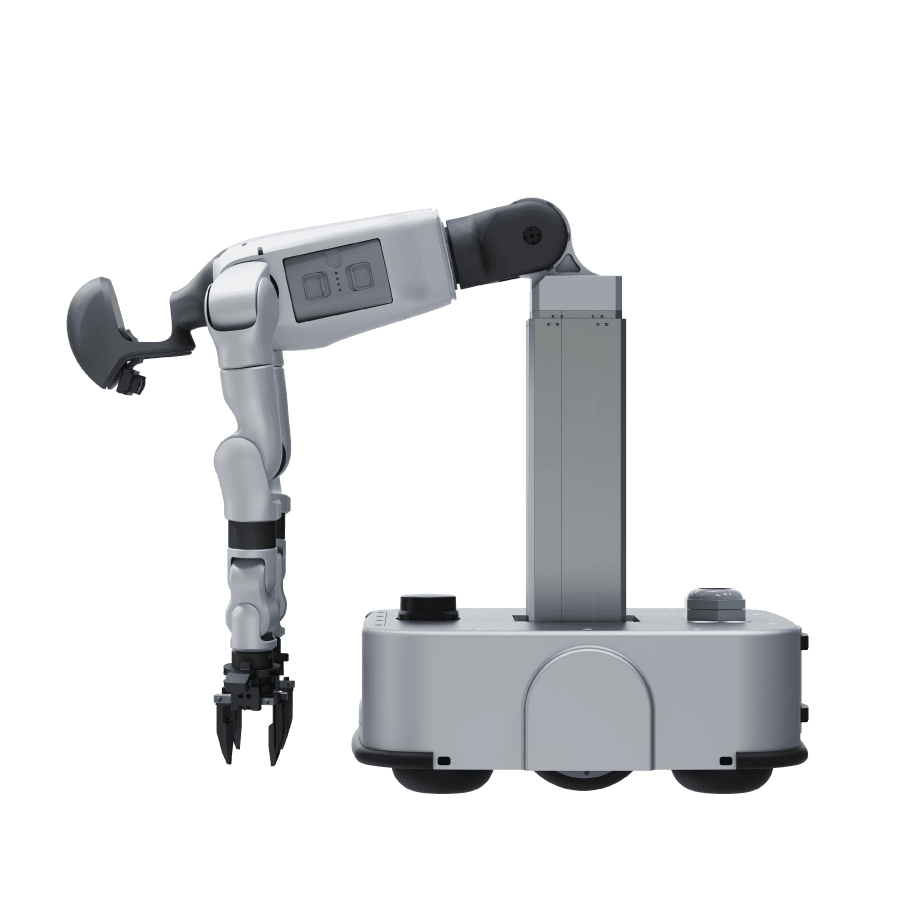
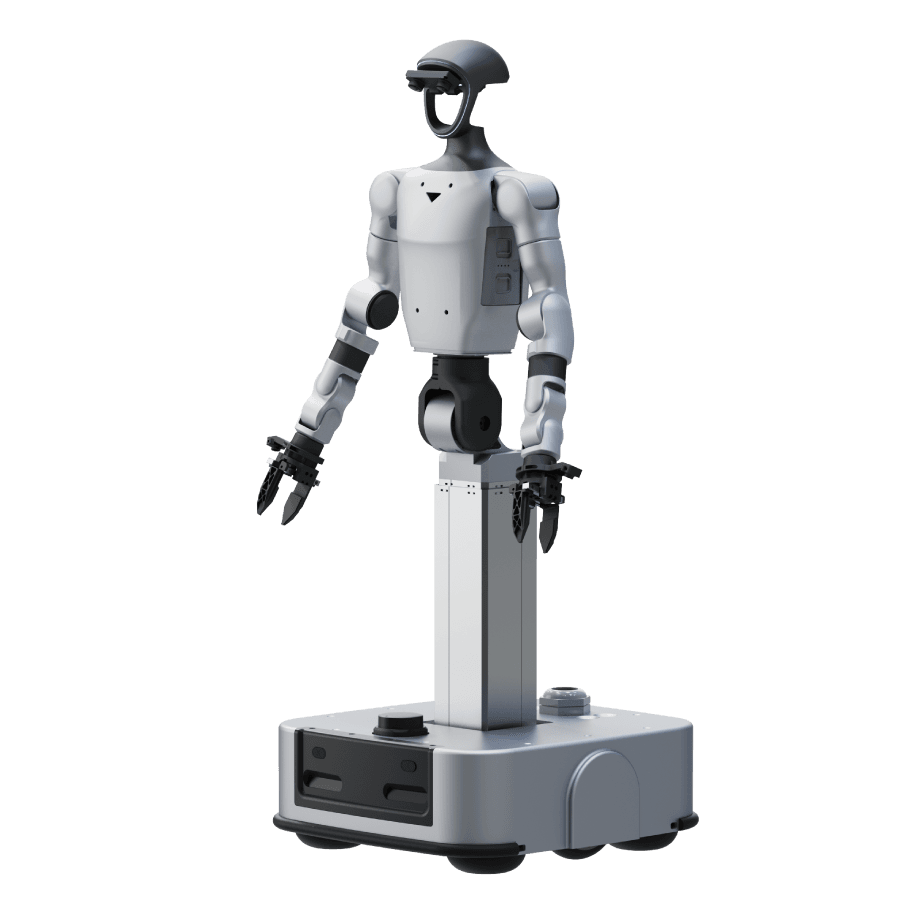
Unitree G1-D är en mobil humanoid robot utvecklad för datainsamling, testning och utveckling inom AI och robotik. Med rörlig bas och två armar kan den utföra moment, samla in rörelsedata och användas som plattform för träning av AI-modeller i verkliga miljöer. Den passar för forskning, utveckling och projekt där humanoid robotik och praktisk data är centralt.
En konfigurerbar mobil Unitree G1-D-plattform med Standard-konfigurationer och hjulförsedda Ultimate-konfigurationer.
G1-D Standard A kombinerar G1-D-plattformen för överkroppen med två Dex1-1 Plus gripdon för mobil manipulation och datainsamling.
Slutlig kompatibilitet, konfiguration, leverans och prissättning bekräftas i offerten.
G1-D Standard B kompletterar Standard A-plattformen med kraftstyrda och trefingrade Dex3-1-händer utan taktil avkänning.
Slutlig kompatibilitet, konfiguration, leverans och prissättning bekräftas i offerten.
G1-D Standard C kompletterar plattformen med taktila, kraftstyrda och trefingrade Dex3-1-händer med 33 taktila sensorer per hand.
Slutlig kompatibilitet, konfiguration, leverans och prissättning bekräftas i offerten.
G1-D Standard D utrustar Standard A-plattformen med två BrainCo Revo 2 Basic femfingrade fingerfärdiga händer.
Slutlig kompatibilitet, konfiguration, leverans och prissättning bekräftas i offerten.
G1-D Standard E utrustar Standard A-plattformen med två taktila BrainCo Revo 2 femfingrade fingerfärdiga händer.
Slutlig kompatibilitet, konfiguration, leverans och prissättning bekräftas i offerten.
G1-D Ultimate A kompletterar plattformen med en motordriven hjulbas, utökad perception och två avancerade kraftstyrda Dex1-1-gripdon.
Slutlig kompatibilitet, konfiguration, leverans och prissättning bekräftas i offerten.
G1-D Ultimate B kompletterar Ultimate A-plattformen med kraftstyrda och trefingrade Dex3-1-händer utan taktil avkänning.
Slutlig kompatibilitet, konfiguration, leverans och prissättning bekräftas i offerten.
G1-D Ultimate C kompletterar plattformen med taktila, kraftstyrda och trefingrade Dex3-1-händer med 33 taktila sensorer per hand.
Slutlig kompatibilitet, konfiguration, leverans och prissättning bekräftas i offerten.
G1-D Ultimate D utrustar Ultimate A-plattformen med två BrainCo Revo 2 Basic femfingrade fingerfärdiga händer.
Slutlig kompatibilitet, konfiguration, leverans och prissättning bekräftas i offerten.
G1-D Ultimate E utrustar Ultimate A-plattformen med två taktila BrainCo Revo 2 femfingrade fingerfärdiga händer.
Slutlig kompatibilitet, konfiguration, leverans och prissättning bekräftas i offerten.
| Specification | G1-D Standard A | G1-D Standard B | G1-D Standard C | G1-D Standard D | G1-D Standard E | G1-D Ultimate A | G1-D Ultimate B | G1-D Ultimate C | G1-D Ultimate D | G1-D Ultimate E |
|---|---|---|---|---|---|---|---|---|---|---|
| General | ||||||||||
| Manufacturer | Unitree | Unitree | Unitree | Unitree | Unitree | Unitree | Unitree | Unitree | Unitree | Unitree |
| Model / edition | G1-D Series | G1-D Series | G1-D Series | G1-D Series | G1-D Series | G1-D Series | G1-D Series | G1-D Series | G1-D Series | G1-D Series |
| Robot type | Humanoid upper-body robot platform | Humanoid upper-body robot platform | Humanoid upper-body robot platform | Humanoid upper-body robot platform | Humanoid upper-body robot platform | Humanoid upper-body robot platform | Humanoid upper-body robot platform | Humanoid upper-body robot platform | Humanoid upper-body robot platform | Humanoid upper-body robot platform |
| Functional description | Configurable upper-body humanoid robot for manipulation, teleoperation, secondary development and data collection. | Configurable upper-body humanoid robot for manipulation, teleoperation, secondary development and data collection. | Configurable upper-body humanoid robot for manipulation, teleoperation, secondary development and data collection. | Configurable upper-body humanoid robot for manipulation, teleoperation, secondary development and data collection. | Configurable upper-body humanoid robot for manipulation, teleoperation, secondary development and data collection. | Configurable upper-body humanoid robot for manipulation, teleoperation, secondary development and data collection. | Configurable upper-body humanoid robot for manipulation, teleoperation, secondary development and data collection. | Configurable upper-body humanoid robot for manipulation, teleoperation, secondary development and data collection. | Configurable upper-body humanoid robot for manipulation, teleoperation, secondary development and data collection. | Configurable upper-body humanoid robot for manipulation, teleoperation, secondary development and data collection. |
| Includes functions of | – | G1-D Standard A | G1-D Standard A | G1-D Standard A | G1-D Standard A | – | G1-D Ultimate A | G1-D Ultimate A | G1-D Ultimate A | G1-D Ultimate A |
| Dimensions & Structure | ||||||||||
| Minimum dimensions (H × W × D) | 1 260 × 500 × 500 mm | 1 260 × 500 × 500 mm | 1 260 × 500 × 500 mm | 1 260 × 500 × 500 mm | 1 260 × 500 × 500 mm | 1 260 × 525 × 570 mm | 1 260 × 525 × 570 mm | 1 260 × 525 × 570 mm | 1 260 × 525 × 570 mm | 1 260 × 525 × 570 mm |
| Maximum dimensions (H × W × D) | 1 680 × 500 × 500 mm | 1 680 × 500 × 500 mm | 1 680 × 500 × 500 mm | 1 680 × 500 × 500 mm | 1 680 × 500 × 500 mm | 1 680 × 525 × 570 mm | 1 680 × 525 × 570 mm | 1 680 × 525 × 570 mm | 1 680 × 525 × 570 mm | 1 680 × 525 × 570 mm |
| Robot weight with battery | 50 kg | 50 kg | 50 kg | 50 kg | 50 kg | 80 kg | 80 kg | 80 kg | 80 kg | 80 kg |
| Maximum operating height | 2 000 mm | 2 000 mm | 2 000 mm | 2 000 mm | 2 000 mm | 2 000 mm | 2 000 mm | 2 000 mm | 2 000 mm | 2 000 mm |
| Degrees of Freedom | ||||||||||
| Total system DoF | 19 | 31 | 31 | 29 | 29 | 21 | 33 | 33 | 31 | 31 |
| Robot DoF excluding end effectors | 17 | 17 | 17 | 17 | 17 | 19 | 19 | 19 | 19 | 19 |
| Single arm DoF | 7 | 7 | 7 | 7 | 7 | 7 | 7 | 7 | 7 | 7 |
| Waist DoF | 2 | 2 | 2 | 2 | 2 | 2 | 2 | 2 | 2 | 2 |
| Vertical column DoF | 1 | 1 | 1 | 1 | 1 | 1 | 1 | 1 | 1 | 1 |
| Mobile base DoF | – | – | – | – | – | 2 | 2 | 2 | 2 | 2 |
| Single hand/end-effector DoF | 1 | 7 | 7 | 6 | 6 | 1 | 7 | 7 | 6 | 6 |
| Single hand joint count | – | – | – | 11 | 11 | – | – | – | 11 | 11 |
| Motion & Performance | ||||||||||
| Arm payload | 3 kg | 3 kg | 3 kg | 3 kg | 3 kg | 3 kg | 3 kg | 3 kg | 3 kg | 3 kg |
| Arm reach | 0,45 m | 0,45 m | 0,45 m | 0,45 m | 0,45 m | 0,45 m | 0,45 m | 0,45 m | 0,45 m | 0,45 m |
| Waist Z-axis range | ±155° | ±155° | ±155° | ±155° | ±155° | ±155° | ±155° | ±155° | ±155° | ±155° |
| Waist Y-axis range | -2.5° to +135° | -2.5° to +135° | -2.5° to +135° | -2.5° to +135° | -2.5° to +135° | -2.5° to +135° | -2.5° to +135° | -2.5° to +135° | -2.5° to +135° | -2.5° to +135° |
| Lift stroke | 500 mm | 500 mm | 500 mm | 500 mm | 500 mm | 450 mm | 450 mm | 450 mm | 450 mm | 450 mm |
| Lift accuracy | 1 mm | 1 mm | 1 mm | 1 mm | 1 mm | 1 mm | 1 mm | 1 mm | 1 mm | 1 mm |
| Maximum lift speed | 60 mm/s | 60 mm/s | 60 mm/s | 60 mm/s | 60 mm/s | 60 mm/s | 60 mm/s | 60 mm/s | 60 mm/s | 60 mm/s |
| Cooling | Local air cooling | Local air cooling | Local air cooling | Local air cooling | Local air cooling | Local air cooling | Local air cooling | Local air cooling | Local air cooling | Local air cooling |
| Mobile Base | ||||||||||
| Base dimensions (L × W × H) | – | – | – | – | – | 570 × 525 × 197 mm | 570 × 525 × 197 mm | 570 × 525 × 197 mm | 570 × 525 × 197 mm | 570 × 525 × 197 mm |
| Drive system | – | – | – | – | – | Dual-wheel differential drive | Dual-wheel differential drive | Dual-wheel differential drive | Dual-wheel differential drive | Dual-wheel differential drive |
| Maximum base speed | – | – | – | – | – | 1,50 m/s | 1,50 m/s | 1,50 m/s | 1,50 m/s | 1,50 m/s |
| In-place 360° rotation | – | – | – | – | – | Yes | Yes | Yes | Yes | Yes |
| LiDAR units | – | – | – | – | – | 1 | 1 | 1 | 1 | 1 |
| Base depth cameras | – | – | – | – | – | 2 | 2 | 2 | 2 | 2 |
| Physical collision sensor | – | – | – | – | – | Yes | Yes | Yes | Yes | Yes |
| Low-lying obstacle recognition sensor | – | – | – | – | – | Yes | Yes | Yes | Yes | Yes |
| Battery & Power | ||||||||||
| Power modes | Smart quick-release battery or direct cable | Smart quick-release battery or direct cable | Smart quick-release battery or direct cable | Smart quick-release battery or direct cable | Smart quick-release battery or direct cable | Built-in base battery or charging pile | Built-in base battery or charging pile | Built-in base battery or charging pile | Built-in base battery or charging pile | Built-in base battery or charging pile |
| Battery type | Smart quick-release battery | Smart quick-release battery | Smart quick-release battery | Smart quick-release battery | Smart quick-release battery | Built-in base battery | Built-in base battery | Built-in base battery | Built-in base battery | Built-in base battery |
| Battery capacity | 9 Ah | 9 Ah | 9 Ah | 9 Ah | 9 Ah | 30 Ah | 30 Ah | 30 Ah | 30 Ah | 30 Ah |
| Battery life | 2 hours | 2 hours | 2 hours | 2 hours | 2 hours | 6 hours | 6 hours | 6 hours | 6 hours | 6 hours |
| Charger output voltage | 54 V | 54 V | 54 V | 54 V | 54 V | 54 V | 54 V | 54 V | 54 V | 54 V |
| Charger output current | 5 A | 5 A | 5 A | 5 A | 5 A | 5 A | 5 A | 5 A | 5 A | 5 A |
| Charging pile output voltage | – | – | – | – | – | 51 V | 51 V | 51 V | 51 V | 51 V |
| Charging pile output current | – | – | – | – | – | 10 A | 10 A | 10 A | 10 A | 10 A |
| Power / charging notes | 9000 mAh smart quick-release battery; 54 V 5 A charger | 9000 mAh smart quick-release battery; 54 V 5 A charger | 9000 mAh smart quick-release battery; 54 V 5 A charger | 9000 mAh smart quick-release battery; 54 V 5 A charger | 9000 mAh smart quick-release battery; 54 V 5 A charger | 30 Ah built-in base battery; 54 V 5 A onboard charger; 51 V 10 A base charging pile | 30 Ah built-in base battery; 54 V 5 A onboard charger; 51 V 10 A base charging pile | 30 Ah built-in base battery; 54 V 5 A onboard charger; 51 V 10 A base charging pile | 30 Ah built-in base battery; 54 V 5 A onboard charger; 51 V 10 A base charging pile | 30 Ah built-in base battery; 54 V 5 A onboard charger; 51 V 10 A base charging pile |
| Compute, Control & Software | ||||||||||
| CPU | 8-core CPU | 8-core CPU | 8-core CPU | 8-core CPU | 8-core CPU | 8-core CPU | 8-core CPU | 8-core CPU | 8-core CPU | 8-core CPU |
| Compute module | NVIDIA Jetson Orin 16 GB | NVIDIA Jetson Orin 16 GB | NVIDIA Jetson Orin 16 GB | NVIDIA Jetson Orin 16 GB | NVIDIA Jetson Orin 16 GB | NVIDIA Jetson Orin 16 GB | NVIDIA Jetson Orin 16 GB | NVIDIA Jetson Orin 16 GB | NVIDIA Jetson Orin 16 GB | NVIDIA Jetson Orin 16 GB |
| AI compute performance | 100 TOPS | 100 TOPS | 100 TOPS | 100 TOPS | 100 TOPS | 100 TOPS | 100 TOPS | 100 TOPS | 100 TOPS | 100 TOPS |
| Optional high-compute modules | Optional rear expansion docks: NVIDIA Jetson AGX Orin (275 TOPS) or NVIDIA Jetson Thor (2070 TOPS) | Optional rear expansion docks: NVIDIA Jetson AGX Orin (275 TOPS) or NVIDIA Jetson Thor (2070 TOPS) | Optional rear expansion docks: NVIDIA Jetson AGX Orin (275 TOPS) or NVIDIA Jetson Thor (2070 TOPS) | Optional rear expansion docks: NVIDIA Jetson AGX Orin (275 TOPS) or NVIDIA Jetson Thor (2070 TOPS) | Optional rear expansion docks: NVIDIA Jetson AGX Orin (275 TOPS) or NVIDIA Jetson Thor (2070 TOPS) | Optional rear expansion docks: NVIDIA Jetson AGX Orin (275 TOPS) or NVIDIA Jetson Thor (2070 TOPS) | Optional rear expansion docks: NVIDIA Jetson AGX Orin (275 TOPS) or NVIDIA Jetson Thor (2070 TOPS) | Optional rear expansion docks: NVIDIA Jetson AGX Orin (275 TOPS) or NVIDIA Jetson Thor (2070 TOPS) | Optional rear expansion docks: NVIDIA Jetson AGX Orin (275 TOPS) or NVIDIA Jetson Thor (2070 TOPS) | Optional rear expansion docks: NVIDIA Jetson AGX Orin (275 TOPS) or NVIDIA Jetson Thor (2070 TOPS) |
| Control | Handheld remote controller included | Handheld remote controller included | Handheld remote controller included | Handheld remote controller included | Handheld remote controller included | Handheld remote controller included | Handheld remote controller included | Handheld remote controller included | Handheld remote controller included | Handheld remote controller included |
| OTA updates | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes |
| Secondary development support | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes |
| Visualization PC included | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes |
| Perception, Audio & Connectivity | ||||||||||
| Perception sensors | Multiple perception sensors | Multiple perception sensors | Multiple perception sensors | Multiple perception sensors | Multiple perception sensors | Multiple perception sensors | Multiple perception sensors | Multiple perception sensors | Multiple perception sensors | Multiple perception sensors |
| Head camera | Binocular camera × 1 | Binocular camera × 1 | Binocular camera × 1 | Binocular camera × 1 | Binocular camera × 1 | Binocular camera × 1 | Binocular camera × 1 | Binocular camera × 1 | Binocular camera × 1 | Binocular camera × 1 |
| Head camera FOV | H 115° / V 80° / D 125° | H 115° / V 80° / D 125° | H 115° / V 80° / D 125° | H 115° / V 80° / D 125° | H 115° / V 80° / D 125° | H 115° / V 80° / D 125° | H 115° / V 80° / D 125° | H 115° / V 80° / D 125° | H 115° / V 80° / D 125° | H 115° / V 80° / D 125° |
| Head camera resolution | 3840 × 1200 | 3840 × 1200 | 3840 × 1200 | 3840 × 1200 | 3840 × 1200 | 3840 × 1200 | 3840 × 1200 | 3840 × 1200 | 3840 × 1200 | 3840 × 1200 |
| Wrist cameras | HD wrist cameras × 2 | HD wrist cameras × 2 | HD wrist cameras × 2 | HD wrist cameras × 2 | HD wrist cameras × 2 | HD wrist cameras × 2 | HD wrist cameras × 2 | HD wrist cameras × 2 | HD wrist cameras × 2 | HD wrist cameras × 2 |
| Wrist camera FOV | H 130° / V 60° / D 160° | H 130° / V 60° / D 160° | H 130° / V 60° / D 160° | H 130° / V 60° / D 160° | H 130° / V 60° / D 160° | H 130° / V 60° / D 160° | H 130° / V 60° / D 160° | H 130° / V 60° / D 160° | H 130° / V 60° / D 160° | H 130° / V 60° / D 160° |
| Wrist camera resolution | 1920 × 1080 | 1920 × 1080 | 1920 × 1080 | 1920 × 1080 | 1920 × 1080 | 1920 × 1080 | 1920 × 1080 | 1920 × 1080 | 1920 × 1080 | 1920 × 1080 |
| Audio input | 4-microphone array | 4-microphone array | 4-microphone array | 4-microphone array | 4-microphone array | 4-microphone array | 4-microphone array | 4-microphone array | 4-microphone array | 4-microphone array |
| Audio output | 5 W speaker | 5 W speaker | 5 W speaker | 5 W speaker | 5 W speaker | 5 W speaker | 5 W speaker | 5 W speaker | 5 W speaker | 5 W speaker |
| Wi-Fi | Wi-Fi 6 | Wi-Fi 6 | Wi-Fi 6 | Wi-Fi 6 | Wi-Fi 6 | Wi-Fi 6 | Wi-Fi 6 | Wi-Fi 6 | Wi-Fi 6 | Wi-Fi 6 |
| Bluetooth | Bluetooth 5.2 | Bluetooth 5.2 | Bluetooth 5.2 | Bluetooth 5.2 | Bluetooth 5.2 | Bluetooth 5.2 | Bluetooth 5.2 | Bluetooth 5.2 | Bluetooth 5.2 | Bluetooth 5.2 |
| Hand / End Effector | ||||||||||
| Hand / end-effector model | Dex1-1 Plus grippers × 2 | Dex3-1 force-controlled three-finger dexterous hands, non-tactile × 2 | Dex3-1 force-controlled three-finger dexterous hands, tactile × 2 | BrainCo Bionic Dexterous Hand Revo 2 Basic × 2 | BrainCo Bionic Dexterous Hand Revo 2 Tactile × 2 | Dex1-1 force-controlled grippers, Advanced Version × 2 | Dex3-1 force-controlled three-finger dexterous hands, non-tactile × 2 | Dex3-1 force-controlled three-finger dexterous hands, tactile × 2 | BrainCo Bionic Dexterous Hand Revo 2 Basic × 2 | BrainCo Bionic Dexterous Hand Revo 2 Tactile × 2 |
| Tactile sensing | No | No | Yes | No | Yes | – | No | Yes | No | Yes |
| Single hand/end-effector weight | 550 g | 650 g | 650 g | 383 g | 383 g | – | 650 g | 650 g | 383 g | 383 g |
| Hand/end-effector dimensions | 143 × 78 × 67 mm | 175 × 88 × 77 mm | 175 × 88 × 77 mm | – | – | – | 175 × 88 × 77 mm | 175 × 88 × 77 mm | – | – |
| Hand height | – | – | – | 160 mm | 160 mm | – | – | – | 160 mm | 160 mm |
| Single hand/end-effector DoF | 1 | 7 | 7 | 6 | 6 | 1 | 7 | 7 | 6 | 6 |
| Single hand joint count | – | – | – | 11 | 11 | – | – | – | 11 | 11 |
| Operating voltage | – | 12–58 V | 12–58 V | – | – | – | 12–58 V | 12–58 V | – | – |
| Static current | – | 0.2 A at 58 V | 0.2 A at 58 V | – | – | – | 0.2 A at 58 V | 0.2 A at 58 V | – | – |
| Communication interface / protocol | High-speed 485 | USB | USB | – | – | – | USB | USB | – | – |
| Repeatability / control accuracy | – | – | – | 0.1° | 0.1° | – | – | – | 0.1° | 0.1° |
| Whole-hand / gripping force | – | – | – | 50 N | 50 N | – | – | – | 50 N | 50 N |
| Single-finger pinch force | – | – | – | 15 N | 15 N | – | – | – | 15 N | 15 N |
| Adjustable force range | 5–120 N adjustable | – | – | – | – | – | – | – | – | – |
| Position resolution | 0.1 mm | – | – | – | – | – | – | – | – | – |
| Gripper stroke | 90 mm | – | – | – | – | – | – | – | – | – |
| Closing time | 0.24 s for full stroke | – | – | – | – | – | – | – | – | – |
| Claw length | 80 mm | – | – | – | – | – | – | – | – | – |
| Form-closure gripping payload | 20 kg | – | – | – | – | – | – | – | – | – |
| Friction gripping payload | 5 kg | – | – | – | – | – | – | – | – | – |
| Tactile sensors per hand | – | – | 33 | – | – | – | – | 33 | – | – |
| Tactile perception range | – | – | 10–2500 g | – | – | – | – | 10–2500 g | – | – |
| Tactile sensing capabilities | – | – | – | – | Pressure, friction, direction and proximity sensing | – | – | – | – | Pressure, friction, direction and proximity sensing |
| Hand/wrist RGB camera included | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes |
| Hand / end-effector notes | Two-finger grippers; specifications are per gripper unless otherwise stated. | Three-finger hand: thumb 3 DoF, index finger 2 DoF and middle finger 2 DoF; specifications are per hand. | Three-finger hand: thumb 3 DoF, index finger 2 DoF and middle finger 2 DoF; specifications are per hand. | Height is measured from the middle fingertip to the palm root; specifications are per hand. | Height is measured from the middle fingertip to the palm root; specifications are per hand. | The supplied document does not state detailed specifications for the Advanced Version gripper. | Three-finger hand: thumb 3 DoF, index finger 2 DoF and middle finger 2 DoF; specifications are per hand. | Three-finger hand: thumb 3 DoF, index finger 2 DoF and middle finger 2 DoF; specifications are per hand. | Height is measured from the middle fingertip to the palm root; specifications are per hand. | Height is measured from the middle fingertip to the palm root; specifications are per hand. |
| Package, Warranty & Notes | ||||||||||
| Included items | Dex1-1 Plus grippers × 2; handheld remote controller; visualization PC | Dex3-1 non-tactile dexterous hands × 2; handheld remote controller; visualization PC | Dex3-1 tactile dexterous hands × 2; handheld remote controller; visualization PC | BrainCo Revo 2 Basic hands × 2; handheld remote controller; visualization PC | BrainCo Revo 2 Tactile hands × 2; handheld remote controller; visualization PC | Dex1-1 Advanced grippers × 2; handheld remote controller; visualization PC | Dex3-1 non-tactile dexterous hands × 2; handheld remote controller; visualization PC | Dex3-1 tactile dexterous hands × 2; handheld remote controller; visualization PC | BrainCo Revo 2 Basic hands × 2; handheld remote controller; visualization PC | BrainCo Revo 2 Tactile hands × 2; handheld remote controller; visualization PC |
| Whole-unit warranty | 12 months | 12 months | 12 months | 12 months | 12 months | 12 months | 12 months | 12 months | 12 months | 12 months |
| Configuration | G1-D Standard A, G1-D Standard B, G1-D Standard C, G1-D Standard D, G1-D Standard E, G1-D Ultimate A, G1-D Ultimate B, G1-D Ultimate C, G1-D Ultimate D, G1-D Ultimate E |
|---|---|
| Brand | Unitree |
| Robot type | Humanoid mobile manipulator |
| Application | Research, Education, Development, Data collection, Teleoperation |
Unitree G1-D-serien är en konfigurerbar humanoid överkroppsplattform för manipulation, fjärrstyrning, vidareutveckling och datainsamling.
G1-D förflyttar sig själv i miljön med sin rörliga bas och kan ta sig fram mellan arbetsstationer, objekt och ytor där moment ska utföras. Med hjälp av sensorer och kameror uppfattar den sin omgivning och anpassar sina rörelser för att arbeta kontrollerat utan kollisioner.
Roboten är utvecklad för att användas i test, utveckling och forskningsprojekt där man snabbt vill kunna sätta upp scenarion och köra moment. Den kräver ingen avancerad handpåläggning för att komma igång och kan enkelt styras, justeras och användas som plattform för olika typer av uppgifter.
Med två rörliga armar och gripfunktion kan G1-D plocka upp, flytta och hantera objekt. Det gör att den kan utföra moment som liknar mänskliga rörelser och användas i projekt där manipulation av föremål är en central del.