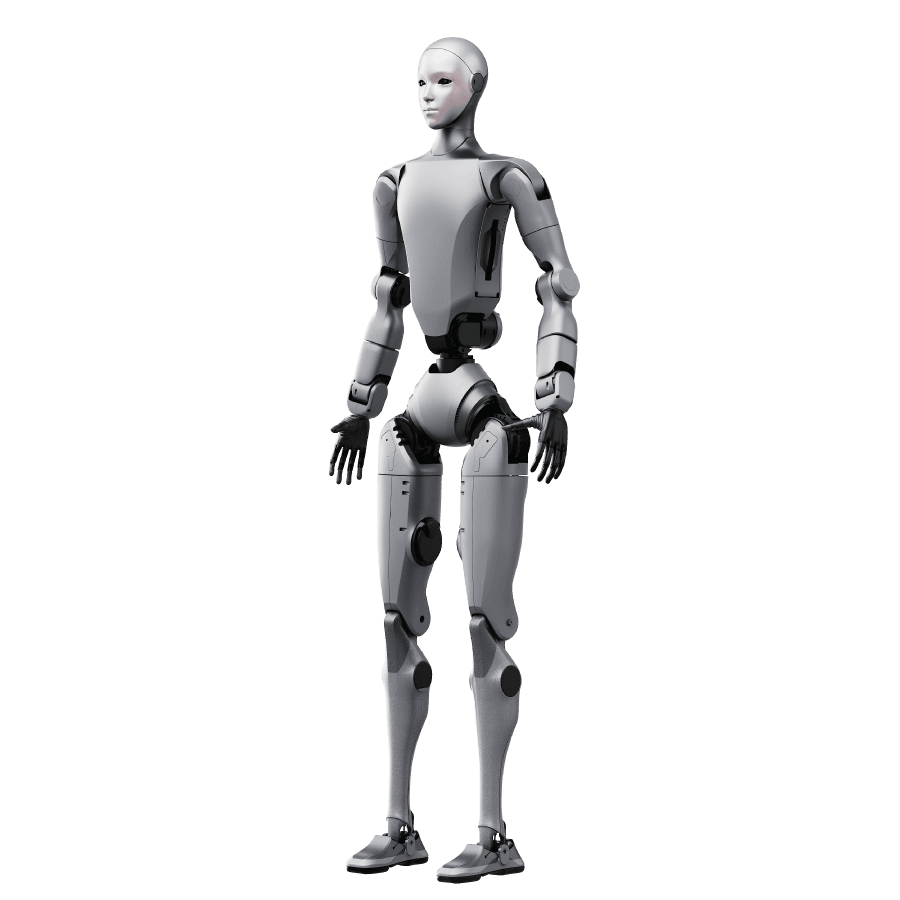
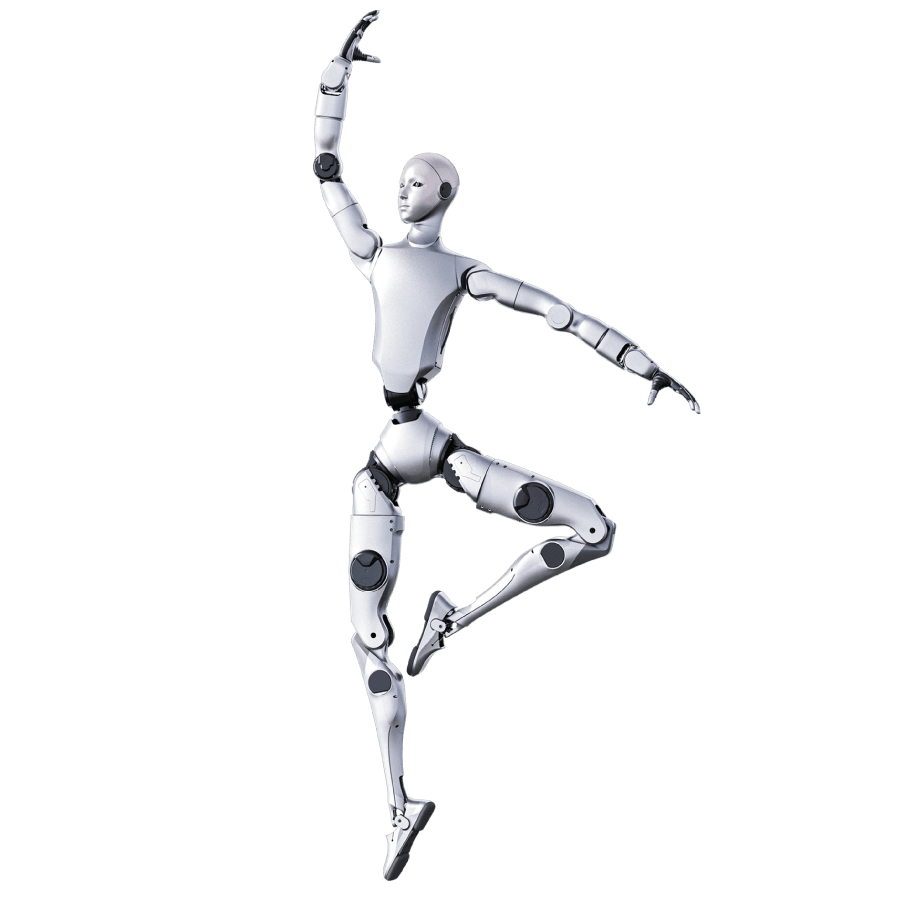
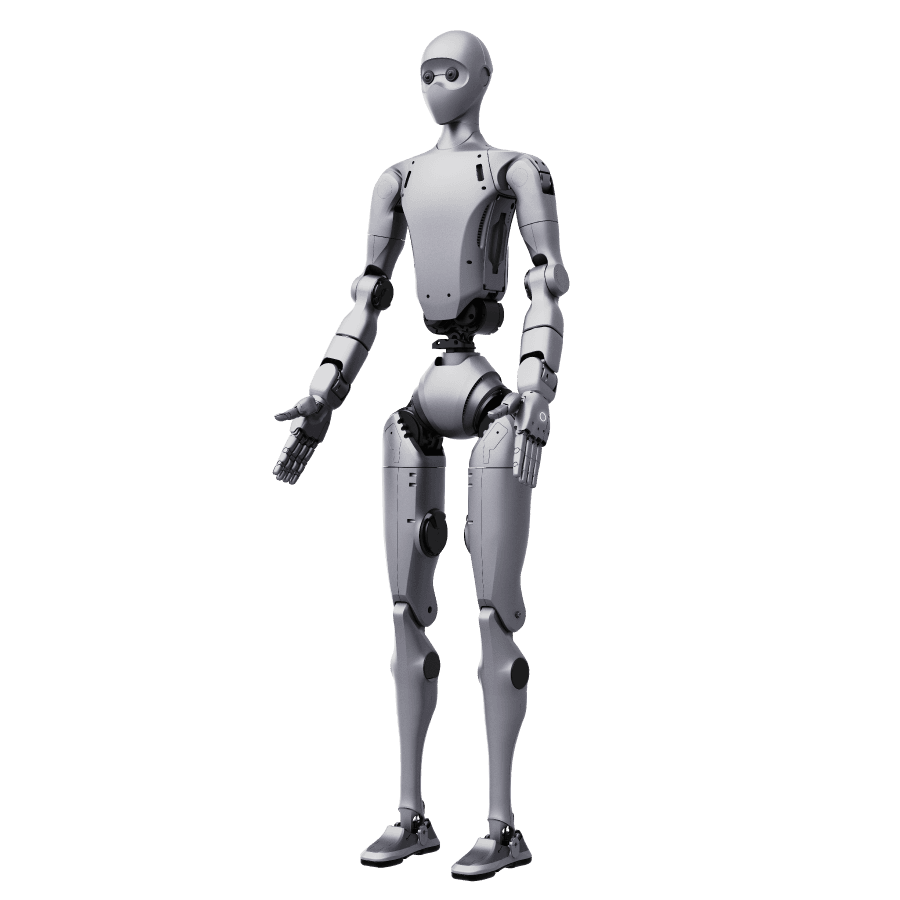
Unitree H2 är en avancerad tvåbent humanoidrobot i full storlek för forskning, robotutveckling och embodied AI. Med 31 frihetsgrader, kraftfull motorstyrning och avancerad beräkningskapacitet erbjuder H2 en plattform för utveckling av humanoid rörelse, AI-baserad styrning och objektmanipulation.
Välj mellan H2 Basic, H2 EDU och H2 PLUS med olika möjligheter till programmering, beräkningskapacitet och robotiska händer.
H2 Basic kombinerar H2-grundplattformen med en Intel Core i5-beräkningsenhet. Fingerfärdiga händer ingår inte som standard.
Slutlig kompatibilitet, konfiguration, leverans och prissättning bekräftas i offerten.
H2 EDU Standard kombinerar utvecklingsplattformen H2 EDU med beräkningsenheterna Intel Core i5 och Intel Core i7. Fingerfärdiga händer ingår inte som standard.
Slutlig kompatibilitet, konfiguration, leverans och prissättning bekräftas i offerten.
H2 EDU Smart A kombinerar utvecklingsplattformen H2 EDU med beräkningsenheterna Intel Core i5 och Intel Core i7. Den är utrustad med Dex1-1 Plus gripdon × 2.
Slutlig kompatibilitet, konfiguration, leverans och prissättning bekräftas i offerten.
H2 EDU Smart B kombinerar utvecklingsplattformen H2 EDU med beräkningsenheterna Intel Core i5 och Intel Core i7. Den är utrustad med Dex3-1 kraftstyrda trefingrade fingerfärdiga händer × 2.
Slutlig kompatibilitet, konfiguration, leverans och prissättning bekräftas i offerten.
H2 EDU Smart C kombinerar utvecklingsplattformen H2 EDU med beräkningsenheterna Intel Core i5 och Intel Core i7. Den är utrustad med Dex3-1 kraftstyrda trefingrade fingerfärdiga händer × 2.
Slutlig kompatibilitet, konfiguration, leverans och prissättning bekräftas i offerten.
H2 EDU Smart D kombinerar utvecklingsplattformen H2 EDU med beräkningsenheterna Intel Core i5 och Intel Core i7. Den är utrustad med Dex5-1 femfingrade fingerfärdiga händer × 2.
Slutlig kompatibilitet, konfiguration, leverans och prissättning bekräftas i offerten.
H2 EDU Smart E kombinerar utvecklingsplattformen H2 EDU med beräkningsenheterna Intel Core i5 och Intel Core i7. Den är utrustad med Dex5-1P femfingrade fingerfärdiga händer × 2.
Slutlig kompatibilitet, konfiguration, leverans och prissättning bekräftas i offerten.
H2 EDU Smart F kombinerar utvecklingsplattformen H2 EDU med beräkningsenheterna Intel Core i5 och Intel Core i7. Den är utrustad med BrainCo Bionic Dexterous Hand Revo 2 Basic × 2.
Slutlig kompatibilitet, konfiguration, leverans och prissättning bekräftas i offerten.
H2 EDU Smart G kombinerar utvecklingsplattformen H2 EDU med beräkningsenheterna Intel Core i5 och Intel Core i7. Den är utrustad med BrainCo Bionic Dexterous Hand Revo 2 Touch × 2.
Slutlig kompatibilitet, konfiguration, leverans och prissättning bekräftas i offerten.
H2 EDU Smart H kombinerar utvecklingsplattformen H2 EDU med beräkningsenheterna Intel Core i5 och Intel Core i7. Den är utrustad med Inspire DFQ fingerfärdiga händer × 2.
Slutlig kompatibilitet, konfiguration, leverans och prissättning bekräftas i offerten.
H2 EDU Smart I kombinerar utvecklingsplattformen H2 EDU med beräkningsenheterna Intel Core i5 och Intel Core i7. Den är utrustad med Inspire E2 fingerfärdiga händer × 2.
Slutlig kompatibilitet, konfiguration, leverans och prissättning bekräftas i offerten.
H2 EDU Smart J kombinerar utvecklingsplattformen H2 EDU med beräkningsenheterna Intel Core i5 och Intel Core i7. Den är utrustad med BrainCo Revo 3 U21 fingerfärdiga händer × 2.
Slutlig kompatibilitet, konfiguration, leverans och prissättning bekräftas i offerten.
H2 EDU Smart K kombinerar utvecklingsplattformen H2 EDU med beräkningsenheterna Intel Core i5 och Intel Core i7. Den är utrustad med BrainCo Revo 3 U21T fingerfärdiga händer × 2.
Slutlig kompatibilitet, konfiguration, leverans och prissättning bekräftas i offerten.
H2 EDU Smart L kombinerar utvecklingsplattformen H2 EDU med beräkningsenheterna Intel Core i5 och Intel Core i7. Den är utrustad med BrainCo Revo 3 U21VT visuellt-taktila fingerfärdiga händer × 2.
Slutlig kompatibilitet, konfiguration, leverans och prissättning bekräftas i offerten.
H2 EDU Smart M kombinerar utvecklingsplattformen H2 EDU med beräkningsenheterna Intel Core i5 och Intel Core i7. Den är utrustad med Wuji Hand 2 femfingrade fingerfärdiga händer × 2.
Slutlig kompatibilitet, konfiguration, leverans och prissättning bekräftas i offerten.
H2 PLUS Smart kombinerar H2 PLUS-plattformen med NVIDIA Jetson Thor för högpresterande beräkningar som standard. Fingerfärdiga händer ingår inte som standard.
Slutlig kompatibilitet, konfiguration, leverans och prissättning bekräftas i offerten.
H2 PLUS Ultimate A kombinerar H2 PLUS-plattformen med NVIDIA Jetson Thor för högpresterande beräkningar som standard. Den är utrustad med Dex1-1 Plus gripdon × 2.
Slutlig kompatibilitet, konfiguration, leverans och prissättning bekräftas i offerten.
H2 PLUS Ultimate B kombinerar H2 PLUS-plattformen med NVIDIA Jetson Thor för högpresterande beräkningar som standard. Den är utrustad med Dex3-1 kraftstyrda trefingrade fingerfärdiga händer × 2.
Slutlig kompatibilitet, konfiguration, leverans och prissättning bekräftas i offerten.
H2 PLUS Ultimate C kombinerar H2 PLUS-plattformen med NVIDIA Jetson Thor för högpresterande beräkningar som standard. Den är utrustad med Dex3-1 kraftstyrda trefingrade fingerfärdiga händer × 2.
Slutlig kompatibilitet, konfiguration, leverans och prissättning bekräftas i offerten.
H2 PLUS Ultimate D kombinerar H2 PLUS-plattformen med NVIDIA Jetson Thor för högpresterande beräkningar som standard. Den är utrustad med Dex5-1 femfingrade fingerfärdiga händer × 2.
Slutlig kompatibilitet, konfiguration, leverans och prissättning bekräftas i offerten.
H2 PLUS Ultimate E kombinerar H2 PLUS-plattformen med NVIDIA Jetson Thor för högpresterande beräkningar som standard. Den är utrustad med Dex5-1P femfingrade fingerfärdiga händer × 2.
Slutlig kompatibilitet, konfiguration, leverans och prissättning bekräftas i offerten.
H2 PLUS Ultimate F kombinerar H2 PLUS-plattformen med NVIDIA Jetson Thor för högpresterande beräkningar som standard. Den är utrustad med BrainCo Bionic Dexterous Hand Revo 2 Basic × 2.
Slutlig kompatibilitet, konfiguration, leverans och prissättning bekräftas i offerten.
H2 PLUS Ultimate G kombinerar H2 PLUS-plattformen med NVIDIA Jetson Thor för högpresterande beräkningar som standard. Den är utrustad med BrainCo Bionic Dexterous Hand Revo 2 Touch × 2.
Slutlig kompatibilitet, konfiguration, leverans och prissättning bekräftas i offerten.
H2 PLUS Ultimate H kombinerar H2 PLUS-plattformen med NVIDIA Jetson Thor för högpresterande beräkningar som standard. Den är utrustad med Inspire DFQ fingerfärdiga händer × 2.
Slutlig kompatibilitet, konfiguration, leverans och prissättning bekräftas i offerten.
H2 PLUS Ultimate I kombinerar H2 PLUS-plattformen med NVIDIA Jetson Thor för högpresterande beräkningar som standard. Den är utrustad med Inspire E2 fingerfärdiga händer × 2.
Slutlig kompatibilitet, konfiguration, leverans och prissättning bekräftas i offerten.
H2 PLUS Ultimate J kombinerar H2 PLUS-plattformen med NVIDIA Jetson Thor för högpresterande beräkningar som standard. Den är utrustad med BrainCo Revo 3 U21 fingerfärdiga händer × 2.
Slutlig kompatibilitet, konfiguration, leverans och prissättning bekräftas i offerten.
H2 PLUS Ultimate K kombinerar H2 PLUS-plattformen med NVIDIA Jetson Thor för högpresterande beräkningar som standard. Den är utrustad med BrainCo Revo 3 U21T fingerfärdiga händer × 2.
Slutlig kompatibilitet, konfiguration, leverans och prissättning bekräftas i offerten.
H2 PLUS Ultimate L kombinerar H2 PLUS-plattformen med NVIDIA Jetson Thor för högpresterande beräkningar som standard. Den är utrustad med BrainCo Revo 3 U21VT visuellt-taktila fingerfärdiga händer × 2.
Slutlig kompatibilitet, konfiguration, leverans och prissättning bekräftas i offerten.
H2 PLUS Ultimate M kombinerar H2 PLUS-plattformen med NVIDIA Jetson Thor för högpresterande beräkningar som standard. Den är utrustad med Wuji Hand 2 femfingrade fingerfärdiga händer × 2.
Slutlig kompatibilitet, konfiguration, leverans och prissättning bekräftas i offerten.
H2 PLUS Ultimate N kombinerar H2 PLUS-plattformen med NVIDIA Jetson Thor för högpresterande beräkningar som standard. Den är utrustad med Sharpa 5-finger visuellt-taktila fingerfärdiga händer × 2.
Slutlig kompatibilitet, konfiguration, leverans och prissättning bekräftas i offerten.
| Specification | H2 Basic | H2 EDU Standard | H2 EDU Smart A | H2 EDU Smart B | H2 EDU Smart C | H2 EDU Smart D | H2 EDU Smart E | H2 EDU Smart F | H2 EDU Smart G | H2 EDU Smart H | H2 EDU Smart I | H2 EDU Smart J | H2 EDU Smart K | H2 EDU Smart L | H2 EDU Smart M | H2 PLUS Smart | H2 PLUS Ultimate A | H2 PLUS Ultimate B | H2 PLUS Ultimate C | H2 PLUS Ultimate D | H2 PLUS Ultimate E | H2 PLUS Ultimate F | H2 PLUS Ultimate G | H2 PLUS Ultimate H | H2 PLUS Ultimate I | H2 PLUS Ultimate J | H2 PLUS Ultimate K | H2 PLUS Ultimate L | H2 PLUS Ultimate M | H2 PLUS Ultimate N |
|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|
| General | ||||||||||||||||||||||||||||||
| Manufacturer | Unitree | Unitree | Unitree | Unitree | Unitree | Unitree | Unitree | Unitree | Unitree | Unitree | Unitree | Unitree | Unitree | Unitree | Unitree | Unitree | Unitree | Unitree | Unitree | Unitree | Unitree | Unitree | Unitree | Unitree | Unitree | Unitree | Unitree | Unitree | Unitree | Unitree |
| Model / edition | H2 Series | H2 Series | H2 Series | H2 Series | H2 Series | H2 Series | H2 Series | H2 Series | H2 Series | H2 Series | H2 Series | H2 Series | H2 Series | H2 Series | H2 Series | H2 Series | H2 Series | H2 Series | H2 Series | H2 Series | H2 Series | H2 Series | H2 Series | H2 Series | H2 Series | H2 Series | H2 Series | H2 Series | H2 Series | H2 Series |
| Robot type | Humanoid robot | Humanoid robot | Humanoid robot | Humanoid robot | Humanoid robot | Humanoid robot | Humanoid robot | Humanoid robot | Humanoid robot | Humanoid robot | Humanoid robot | Humanoid robot | Humanoid robot | Humanoid robot | Humanoid robot | Humanoid robot | Humanoid robot | Humanoid robot | Humanoid robot | Humanoid robot | Humanoid robot | Humanoid robot | Humanoid robot | Humanoid robot | Humanoid robot | Humanoid robot | Humanoid robot | Humanoid robot | Humanoid robot | Humanoid robot |
| Includes functions of | – | – | H2 EDU Standard | H2 EDU Standard | H2 EDU Standard | H2 EDU Standard | H2 EDU Standard | H2 EDU Standard | H2 EDU Standard | H2 EDU Standard | H2 EDU Standard | H2 EDU Standard | H2 EDU Standard | H2 EDU Standard | H2 EDU Standard | H2 PLUS Standard | H2 PLUS Smart | H2 PLUS Smart | H2 PLUS Smart | H2 PLUS Smart | H2 PLUS Smart | H2 PLUS Smart | H2 PLUS Smart | H2 PLUS Smart | H2 PLUS Smart | H2 PLUS Smart | H2 PLUS Smart | H2 PLUS Smart | H2 PLUS Smart | H2 PLUS Smart |
| Dimensions & Construction | ||||||||||||||||||||||||||||||
| Standing dimensions (H × W × D) | 1 820 × 456 × 218 mm | 1 820 × 456 × 218 mm | 1 820 × 456 × 218 mm | 1 820 × 456 × 218 mm | 1 820 × 456 × 218 mm | 1 820 × 456 × 218 mm | 1 820 × 456 × 218 mm | 1 820 × 456 × 218 mm | 1 820 × 456 × 218 mm | 1 820 × 456 × 218 mm | 1 820 × 456 × 218 mm | 1 820 × 456 × 218 mm | 1 820 × 456 × 218 mm | 1 820 × 456 × 218 mm | 1 820 × 456 × 218 mm | 1 820 × 456 × 218 mm | 1 820 × 456 × 218 mm | 1 820 × 456 × 218 mm | 1 820 × 456 × 218 mm | 1 820 × 456 × 218 mm | 1 820 × 456 × 218 mm | 1 820 × 456 × 218 mm | 1 820 × 456 × 218 mm | 1 820 × 456 × 218 mm | 1 820 × 456 × 218 mm | 1 820 × 456 × 218 mm | 1 820 × 456 × 218 mm | 1 820 × 456 × 218 mm | 1 820 × 456 × 218 mm | 1 820 × 456 × 218 mm |
| Robot weight with battery | 70 kg | 70 kg | 70 kg | 70 kg | 70 kg | 70 kg | 70 kg | 70 kg | 70 kg | 70 kg | 70 kg | 70 kg | 70 kg | 70 kg | 70 kg | 70 kg | 70 kg | 70 kg | 70 kg | 70 kg | 70 kg | 70 kg | 70 kg | 70 kg | 70 kg | 70 kg | 70 kg | 70 kg | 70 kg | 70 kg |
| Materials and construction | Aviation aluminium, titanium alloy and high-strength engineering plastic | Aviation aluminium, titanium alloy and high-strength engineering plastic | Aviation aluminium, titanium alloy and high-strength engineering plastic | Aviation aluminium, titanium alloy and high-strength engineering plastic | Aviation aluminium, titanium alloy and high-strength engineering plastic | Aviation aluminium, titanium alloy and high-strength engineering plastic | Aviation aluminium, titanium alloy and high-strength engineering plastic | Aviation aluminium, titanium alloy and high-strength engineering plastic | Aviation aluminium, titanium alloy and high-strength engineering plastic | Aviation aluminium, titanium alloy and high-strength engineering plastic | Aviation aluminium, titanium alloy and high-strength engineering plastic | Aviation aluminium, titanium alloy and high-strength engineering plastic | Aviation aluminium, titanium alloy and high-strength engineering plastic | Aviation aluminium, titanium alloy and high-strength engineering plastic | Aviation aluminium, titanium alloy and high-strength engineering plastic | Aviation aluminium, titanium alloy and high-strength engineering plastic | Aviation aluminium, titanium alloy and high-strength engineering plastic | Aviation aluminium, titanium alloy and high-strength engineering plastic | Aviation aluminium, titanium alloy and high-strength engineering plastic | Aviation aluminium, titanium alloy and high-strength engineering plastic | Aviation aluminium, titanium alloy and high-strength engineering plastic | Aviation aluminium, titanium alloy and high-strength engineering plastic | Aviation aluminium, titanium alloy and high-strength engineering plastic | Aviation aluminium, titanium alloy and high-strength engineering plastic | Aviation aluminium, titanium alloy and high-strength engineering plastic | Aviation aluminium, titanium alloy and high-strength engineering plastic | Aviation aluminium, titanium alloy and high-strength engineering plastic | Aviation aluminium, titanium alloy and high-strength engineering plastic | Aviation aluminium, titanium alloy and high-strength engineering plastic | Aviation aluminium, titanium alloy and high-strength engineering plastic |
| Leg length | 1 045 mm | 1 045 mm | 1 045 mm | 1 045 mm | 1 045 mm | 1 045 mm | 1 045 mm | 1 045 mm | 1 045 mm | 1 045 mm | 1 045 mm | 1 045 mm | 1 045 mm | 1 045 mm | 1 045 mm | 1 045 mm | 1 045 mm | 1 045 mm | 1 045 mm | 1 045 mm | 1 045 mm | 1 045 mm | 1 045 mm | 1 045 mm | 1 045 mm | 1 045 mm | 1 045 mm | 1 045 mm | 1 045 mm | 1 045 mm |
| Arm length | 690 mm | 690 mm | 690 mm | 690 mm | 690 mm | 690 mm | 690 mm | 690 mm | 690 mm | 690 mm | 690 mm | 690 mm | 690 mm | 690 mm | 690 mm | 690 mm | 690 mm | 690 mm | 690 mm | 690 mm | 690 mm | 690 mm | 690 mm | 690 mm | 690 mm | 690 mm | 690 mm | 690 mm | 690 mm | 690 mm |
| Degrees of Freedom | ||||||||||||||||||||||||||||||
| Total robot/system DoF | 31 | 31 | 33 | 45 | 45 | 63 | 63 | 43 | 43 | 43 | 43 | 73 | 73 | 73 | 71 | 31 | 33 | 45 | 45 | 63 | 63 | 43 | 43 | 43 | 43 | 73 | 73 | 73 | 71 | 75 |
| Single leg DoF | 6 | 6 | 6 | 6 | 6 | 6 | 6 | 6 | 6 | 6 | 6 | 6 | 6 | 6 | 6 | 6 | 6 | 6 | 6 | 6 | 6 | 6 | 6 | 6 | 6 | 6 | 6 | 6 | 6 | 6 |
| Single arm DoF | 7 | 7 | 7 | 7 | 7 | 7 | 7 | 7 | 7 | 7 | 7 | 7 | 7 | 7 | 7 | 7 | 7 | 7 | 7 | 7 | 7 | 7 | 7 | 7 | 7 | 7 | 7 | 7 | 7 | 7 |
| Waist DoF | 3 | 3 | 3 | 3 | 3 | 3 | 3 | 3 | 3 | 3 | 3 | 3 | 3 | 3 | 3 | 3 | 3 | 3 | 3 | 3 | 3 | 3 | 3 | 3 | 3 | 3 | 3 | 3 | 3 | 3 |
| Head DoF | 2 | 2 | 2 | 2 | 2 | 2 | 2 | 2 | 2 | 2 | 2 | 2 | 2 | 2 | 2 | 2 | 2 | 2 | 2 | 2 | 2 | 2 | 2 | 2 | 2 | 2 | 2 | 2 | 2 | 2 |
| Single hand/end-effector DoF | – | – | 1 | 7 | 7 | 16 | 16 | 6 | 6 | 6 | 6 | 21 | 21 | 21 | 20 | – | 1 | 7 | 7 | 16 | 16 | 6 | 6 | 6 | 6 | 21 | 21 | 21 | 20 | 22 |
| Single hand joint count | – | – | – | – | – | 16 | 16 | 11 | 11 | 12 | 12 | – | – | – | – | – | – | – | – | 16 | 16 | 11 | 11 | 12 | 12 | – | – | – | – | – |
| Performance & Actuation | ||||||||||||||||||||||||||||||
| Maximum arm joint torque | 120 N·m | 120 N·m | 120 N·m | 120 N·m | 120 N·m | 120 N·m | 120 N·m | 120 N·m | 120 N·m | 120 N·m | 120 N·m | 120 N·m | 120 N·m | 120 N·m | 120 N·m | 120 N·m | 120 N·m | 120 N·m | 120 N·m | 120 N·m | 120 N·m | 120 N·m | 120 N·m | 120 N·m | 120 N·m | 120 N·m | 120 N·m | 120 N·m | 120 N·m | 120 N·m |
| Maximum leg joint torque | 360 N·m | 360 N·m | 360 N·m | 360 N·m | 360 N·m | 360 N·m | 360 N·m | 360 N·m | 360 N·m | 360 N·m | 360 N·m | 360 N·m | 360 N·m | 360 N·m | 360 N·m | 360 N·m | 360 N·m | 360 N·m | 360 N·m | 360 N·m | 360 N·m | 360 N·m | 360 N·m | 360 N·m | 360 N·m | 360 N·m | 360 N·m | 360 N·m | 360 N·m | 360 N·m |
| Peak arm payload | 15 kg | 15 kg | 15 kg | 15 kg | 15 kg | 15 kg | 15 kg | 15 kg | 15 kg | 15 kg | 15 kg | 15 kg | 15 kg | 15 kg | 15 kg | 15 kg | 15 kg | 15 kg | 15 kg | 15 kg | 15 kg | 15 kg | 15 kg | 15 kg | 15 kg | 15 kg | 15 kg | 15 kg | 15 kg | 15 kg |
| Rated arm payload | 7 kg | 7 kg | 7 kg | 7 kg | 7 kg | 7 kg | 7 kg | 7 kg | 7 kg | 7 kg | 7 kg | 7 kg | 7 kg | 7 kg | 7 kg | 7 kg | 7 kg | 7 kg | 7 kg | 7 kg | 7 kg | 7 kg | 7 kg | 7 kg | 7 kg | 7 kg | 7 kg | 7 kg | 7 kg | 7 kg |
| Actuation system | Low-inertia high-speed PMSM motors with industrial crossed-roller bearings | Low-inertia high-speed PMSM motors with industrial crossed-roller bearings | Low-inertia high-speed PMSM motors with industrial crossed-roller bearings | Low-inertia high-speed PMSM motors with industrial crossed-roller bearings | Low-inertia high-speed PMSM motors with industrial crossed-roller bearings | Low-inertia high-speed PMSM motors with industrial crossed-roller bearings | Low-inertia high-speed PMSM motors with industrial crossed-roller bearings | Low-inertia high-speed PMSM motors with industrial crossed-roller bearings | Low-inertia high-speed PMSM motors with industrial crossed-roller bearings | Low-inertia high-speed PMSM motors with industrial crossed-roller bearings | Low-inertia high-speed PMSM motors with industrial crossed-roller bearings | Low-inertia high-speed PMSM motors with industrial crossed-roller bearings | Low-inertia high-speed PMSM motors with industrial crossed-roller bearings | Low-inertia high-speed PMSM motors with industrial crossed-roller bearings | Low-inertia high-speed PMSM motors with industrial crossed-roller bearings | Low-inertia high-speed PMSM motors with industrial crossed-roller bearings | Low-inertia high-speed PMSM motors with industrial crossed-roller bearings | Low-inertia high-speed PMSM motors with industrial crossed-roller bearings | Low-inertia high-speed PMSM motors with industrial crossed-roller bearings | Low-inertia high-speed PMSM motors with industrial crossed-roller bearings | Low-inertia high-speed PMSM motors with industrial crossed-roller bearings | Low-inertia high-speed PMSM motors with industrial crossed-roller bearings | Low-inertia high-speed PMSM motors with industrial crossed-roller bearings | Low-inertia high-speed PMSM motors with industrial crossed-roller bearings | Low-inertia high-speed PMSM motors with industrial crossed-roller bearings | Low-inertia high-speed PMSM motors with industrial crossed-roller bearings | Low-inertia high-speed PMSM motors with industrial crossed-roller bearings | Low-inertia high-speed PMSM motors with industrial crossed-roller bearings | Low-inertia high-speed PMSM motors with industrial crossed-roller bearings | Low-inertia high-speed PMSM motors with industrial crossed-roller bearings |
| Cooling | Air cooling | Air cooling | Air cooling | Air cooling | Air cooling | Air cooling | Air cooling | Air cooling | Air cooling | Air cooling | Air cooling | Air cooling | Air cooling | Air cooling | Air cooling | Air cooling | Air cooling | Air cooling | Air cooling | Air cooling | Air cooling | Air cooling | Air cooling | Air cooling | Air cooling | Air cooling | Air cooling | Air cooling | Air cooling | Air cooling |
| Battery & Power | ||||||||||||||||||||||||||||||
| Battery type | Low-internal-resistance lithium-ion smart quick-release battery | Low-internal-resistance lithium-ion smart quick-release battery | Low-internal-resistance lithium-ion smart quick-release battery | Low-internal-resistance lithium-ion smart quick-release battery | Low-internal-resistance lithium-ion smart quick-release battery | Low-internal-resistance lithium-ion smart quick-release battery | Low-internal-resistance lithium-ion smart quick-release battery | Low-internal-resistance lithium-ion smart quick-release battery | Low-internal-resistance lithium-ion smart quick-release battery | Low-internal-resistance lithium-ion smart quick-release battery | Low-internal-resistance lithium-ion smart quick-release battery | Low-internal-resistance lithium-ion smart quick-release battery | Low-internal-resistance lithium-ion smart quick-release battery | Low-internal-resistance lithium-ion smart quick-release battery | Low-internal-resistance lithium-ion smart quick-release battery | Low-internal-resistance lithium-ion smart quick-release battery | Low-internal-resistance lithium-ion smart quick-release battery | Low-internal-resistance lithium-ion smart quick-release battery | Low-internal-resistance lithium-ion smart quick-release battery | Low-internal-resistance lithium-ion smart quick-release battery | Low-internal-resistance lithium-ion smart quick-release battery | Low-internal-resistance lithium-ion smart quick-release battery | Low-internal-resistance lithium-ion smart quick-release battery | Low-internal-resistance lithium-ion smart quick-release battery | Low-internal-resistance lithium-ion smart quick-release battery | Low-internal-resistance lithium-ion smart quick-release battery | Low-internal-resistance lithium-ion smart quick-release battery | Low-internal-resistance lithium-ion smart quick-release battery | Low-internal-resistance lithium-ion smart quick-release battery | Low-internal-resistance lithium-ion smart quick-release battery |
| Battery capacity | 15 Ah | 15 Ah | 15 Ah | 15 Ah | 15 Ah | 15 Ah | 15 Ah | 15 Ah | 15 Ah | 15 Ah | 15 Ah | 15 Ah | 15 Ah | 15 Ah | 15 Ah | 15 Ah | 15 Ah | 15 Ah | 15 Ah | 15 Ah | 15 Ah | 15 Ah | 15 Ah | 15 Ah | 15 Ah | 15 Ah | 15 Ah | 15 Ah | 15 Ah | 15 Ah |
| Battery energy | 0,97 kWh | 0,97 kWh | 0,97 kWh | 0,97 kWh | 0,97 kWh | 0,97 kWh | 0,97 kWh | 0,97 kWh | 0,97 kWh | 0,97 kWh | 0,97 kWh | 0,97 kWh | 0,97 kWh | 0,97 kWh | 0,97 kWh | 0,97 kWh | 0,97 kWh | 0,97 kWh | 0,97 kWh | 0,97 kWh | 0,97 kWh | 0,97 kWh | 0,97 kWh | 0,97 kWh | 0,97 kWh | 0,97 kWh | 0,97 kWh | 0,97 kWh | 0,97 kWh | 0,97 kWh |
| Maximum battery voltage | 75,60 V | 75,60 V | 75,60 V | 75,60 V | 75,60 V | 75,60 V | 75,60 V | 75,60 V | 75,60 V | 75,60 V | 75,60 V | 75,60 V | 75,60 V | 75,60 V | 75,60 V | 75,60 V | 75,60 V | 75,60 V | 75,60 V | 75,60 V | 75,60 V | 75,60 V | 75,60 V | 75,60 V | 75,60 V | 75,60 V | 75,60 V | 75,60 V | 75,60 V | 75,60 V |
| Battery life | 3 hours | 3 hours | 3 hours | 3 hours | 3 hours | 3 hours | 3 hours | 3 hours | 3 hours | 3 hours | 3 hours | 3 hours | 3 hours | 3 hours | 3 hours | 3 hours | 3 hours | 3 hours | 3 hours | 3 hours | 3 hours | 3 hours | 3 hours | 3 hours | 3 hours | 3 hours | 3 hours | 3 hours | 3 hours | 3 hours |
| Power system / battery notes | Approximately 3 hours runtime, depending on actual operating conditions | Approximately 3 hours runtime, depending on actual operating conditions | Approximately 3 hours runtime, depending on actual operating conditions | Approximately 3 hours runtime, depending on actual operating conditions | Approximately 3 hours runtime, depending on actual operating conditions | Approximately 3 hours runtime, depending on actual operating conditions | Approximately 3 hours runtime, depending on actual operating conditions | Approximately 3 hours runtime, depending on actual operating conditions | Approximately 3 hours runtime, depending on actual operating conditions | Approximately 3 hours runtime, depending on actual operating conditions | Approximately 3 hours runtime, depending on actual operating conditions | Approximately 3 hours runtime, depending on actual operating conditions | Approximately 3 hours runtime, depending on actual operating conditions | Approximately 3 hours runtime, depending on actual operating conditions | Approximately 3 hours runtime, depending on actual operating conditions | Approximately 3 hours runtime, depending on actual operating conditions | Approximately 3 hours runtime, depending on actual operating conditions | Approximately 3 hours runtime, depending on actual operating conditions | Approximately 3 hours runtime, depending on actual operating conditions | Approximately 3 hours runtime, depending on actual operating conditions | Approximately 3 hours runtime, depending on actual operating conditions | Approximately 3 hours runtime, depending on actual operating conditions | Approximately 3 hours runtime, depending on actual operating conditions | Approximately 3 hours runtime, depending on actual operating conditions | Approximately 3 hours runtime, depending on actual operating conditions | Approximately 3 hours runtime, depending on actual operating conditions | Approximately 3 hours runtime, depending on actual operating conditions | Approximately 3 hours runtime, depending on actual operating conditions | Approximately 3 hours runtime, depending on actual operating conditions | Approximately 3 hours runtime, depending on actual operating conditions |
| Compute & Software | ||||||||||||||||||||||||||||||
| PC1 / platform computer | Intel Core i5 (platform functions) | Intel Core i5 (platform functions) | Intel Core i5 (platform functions) | Intel Core i5 (platform functions) | Intel Core i5 (platform functions) | Intel Core i5 (platform functions) | Intel Core i5 (platform functions) | Intel Core i5 (platform functions) | Intel Core i5 (platform functions) | Intel Core i5 (platform functions) | Intel Core i5 (platform functions) | Intel Core i5 (platform functions) | Intel Core i5 (platform functions) | Intel Core i5 (platform functions) | Intel Core i5 (platform functions) | Intel Core i5 (platform functions) | Intel Core i5 (platform functions) | Intel Core i5 (platform functions) | Intel Core i5 (platform functions) | Intel Core i5 (platform functions) | Intel Core i5 (platform functions) | Intel Core i5 (platform functions) | Intel Core i5 (platform functions) | Intel Core i5 (platform functions) | Intel Core i5 (platform functions) | Intel Core i5 (platform functions) | Intel Core i5 (platform functions) | Intel Core i5 (platform functions) | Intel Core i5 (platform functions) | Intel Core i5 (platform functions) |
| PC2 / user-development computer | Not included | Intel Core i7 (user development) | Intel Core i7 (user development) | Intel Core i7 (user development) | Intel Core i7 (user development) | Intel Core i7 (user development) | Intel Core i7 (user development) | Intel Core i7 (user development) | Intel Core i7 (user development) | Intel Core i7 (user development) | Intel Core i7 (user development) | Intel Core i7 (user development) | Intel Core i7 (user development) | Intel Core i7 (user development) | Intel Core i7 (user development) | Intel Core i7 (user development) | Intel Core i7 (user development) | Intel Core i7 (user development) | Intel Core i7 (user development) | Intel Core i7 (user development) | Intel Core i7 (user development) | Intel Core i7 (user development) | Intel Core i7 (user development) | Intel Core i7 (user development) | Intel Core i7 (user development) | Intel Core i7 (user development) | Intel Core i7 (user development) | Intel Core i7 (user development) | Intel Core i7 (user development) | Intel Core i7 (user development) |
| PC3 / high-compute module | Not included | Empty by default; optional NVIDIA Jetson Thor × 1 | Empty by default; optional NVIDIA Jetson Thor × 1 | Empty by default; optional NVIDIA Jetson Thor × 1 | Empty by default; optional NVIDIA Jetson Thor × 1 | Empty by default; optional NVIDIA Jetson Thor × 1 | Empty by default; optional NVIDIA Jetson Thor × 1 | Empty by default; optional NVIDIA Jetson Thor × 1 | Empty by default; optional NVIDIA Jetson Thor × 1 | Empty by default; optional NVIDIA Jetson Thor × 1 | Empty by default; optional NVIDIA Jetson Thor × 1 | Empty by default; optional NVIDIA Jetson Thor × 1 | Empty by default; optional NVIDIA Jetson Thor × 1 | Empty by default; optional NVIDIA Jetson Thor × 1 | Empty by default; optional NVIDIA Jetson Thor × 1 | NVIDIA Jetson Thor × 1 (standard) | NVIDIA Jetson Thor × 1 (standard) | NVIDIA Jetson Thor × 1 (standard) | NVIDIA Jetson Thor × 1 (standard) | NVIDIA Jetson Thor × 1 (standard) | NVIDIA Jetson Thor × 1 (standard) | NVIDIA Jetson Thor × 1 (standard) | NVIDIA Jetson Thor × 1 (standard) | NVIDIA Jetson Thor × 1 (standard) | NVIDIA Jetson Thor × 1 (standard) | NVIDIA Jetson Thor × 1 (standard) | NVIDIA Jetson Thor × 1 (standard) | NVIDIA Jetson Thor × 1 (standard) | NVIDIA Jetson Thor × 1 (standard) | NVIDIA Jetson Thor × 1 (standard) |
| PC4 / optional module | Not included | Empty by default; optional Intel Core i7 × 1 or NVIDIA Jetson Orin NX × 1 | Empty by default; optional Intel Core i7 × 1 or NVIDIA Jetson Orin NX × 1 | Empty by default; optional Intel Core i7 × 1 or NVIDIA Jetson Orin NX × 1 | Empty by default; optional Intel Core i7 × 1 or NVIDIA Jetson Orin NX × 1 | Empty by default; optional Intel Core i7 × 1 or NVIDIA Jetson Orin NX × 1 | Empty by default; optional Intel Core i7 × 1 or NVIDIA Jetson Orin NX × 1 | Empty by default; optional Intel Core i7 × 1 or NVIDIA Jetson Orin NX × 1 | Empty by default; optional Intel Core i7 × 1 or NVIDIA Jetson Orin NX × 1 | Empty by default; optional Intel Core i7 × 1 or NVIDIA Jetson Orin NX × 1 | Empty by default; optional Intel Core i7 × 1 or NVIDIA Jetson Orin NX × 1 | Empty by default; optional Intel Core i7 × 1 or NVIDIA Jetson Orin NX × 1 | Empty by default; optional Intel Core i7 × 1 or NVIDIA Jetson Orin NX × 1 | Empty by default; optional Intel Core i7 × 1 or NVIDIA Jetson Orin NX × 1 | Empty by default; optional Intel Core i7 × 1 or NVIDIA Jetson Orin NX × 1 | Empty by default; optional Intel Core i7 × 1 | Empty by default; optional Intel Core i7 × 1 | Empty by default; optional Intel Core i7 × 1 | Empty by default; optional Intel Core i7 × 1 | Empty by default; optional Intel Core i7 × 1 | Empty by default; optional Intel Core i7 × 1 | Empty by default; optional Intel Core i7 × 1 | Empty by default; optional Intel Core i7 × 1 | Empty by default; optional Intel Core i7 × 1 | Empty by default; optional Intel Core i7 × 1 | Empty by default; optional Intel Core i7 × 1 | Empty by default; optional Intel Core i7 × 1 | Empty by default; optional Intel Core i7 × 1 | Empty by default; optional Intel Core i7 × 1 | Empty by default; optional Intel Core i7 × 1 |
| AI compute performance | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | 2070 TFLOPS (FP4 sparse) | 2070 TFLOPS (FP4 sparse) | 2070 TFLOPS (FP4 sparse) | 2070 TFLOPS (FP4 sparse) | 2070 TFLOPS (FP4 sparse) | 2070 TFLOPS (FP4 sparse) | 2070 TFLOPS (FP4 sparse) | 2070 TFLOPS (FP4 sparse) | 2070 TFLOPS (FP4 sparse) | 2070 TFLOPS (FP4 sparse) | 2070 TFLOPS (FP4 sparse) | 2070 TFLOPS (FP4 sparse) | 2070 TFLOPS (FP4 sparse) | 2070 TFLOPS (FP4 sparse) | 2070 TFLOPS (FP4 sparse) |
| GPU | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | 2560-core NVIDIA Blackwell architecture GPU; fifth-generation Tensor Cores; 10 TPC multi-instance GPU; up to 1.57 GHz | 2560-core NVIDIA Blackwell architecture GPU; fifth-generation Tensor Cores; 10 TPC multi-instance GPU; up to 1.57 GHz | 2560-core NVIDIA Blackwell architecture GPU; fifth-generation Tensor Cores; 10 TPC multi-instance GPU; up to 1.57 GHz | 2560-core NVIDIA Blackwell architecture GPU; fifth-generation Tensor Cores; 10 TPC multi-instance GPU; up to 1.57 GHz | 2560-core NVIDIA Blackwell architecture GPU; fifth-generation Tensor Cores; 10 TPC multi-instance GPU; up to 1.57 GHz | 2560-core NVIDIA Blackwell architecture GPU; fifth-generation Tensor Cores; 10 TPC multi-instance GPU; up to 1.57 GHz | 2560-core NVIDIA Blackwell architecture GPU; fifth-generation Tensor Cores; 10 TPC multi-instance GPU; up to 1.57 GHz | 2560-core NVIDIA Blackwell architecture GPU; fifth-generation Tensor Cores; 10 TPC multi-instance GPU; up to 1.57 GHz | 2560-core NVIDIA Blackwell architecture GPU; fifth-generation Tensor Cores; 10 TPC multi-instance GPU; up to 1.57 GHz | 2560-core NVIDIA Blackwell architecture GPU; fifth-generation Tensor Cores; 10 TPC multi-instance GPU; up to 1.57 GHz | 2560-core NVIDIA Blackwell architecture GPU; fifth-generation Tensor Cores; 10 TPC multi-instance GPU; up to 1.57 GHz | 2560-core NVIDIA Blackwell architecture GPU; fifth-generation Tensor Cores; 10 TPC multi-instance GPU; up to 1.57 GHz | 2560-core NVIDIA Blackwell architecture GPU; fifth-generation Tensor Cores; 10 TPC multi-instance GPU; up to 1.57 GHz | 2560-core NVIDIA Blackwell architecture GPU; fifth-generation Tensor Cores; 10 TPC multi-instance GPU; up to 1.57 GHz | 2560-core NVIDIA Blackwell architecture GPU; fifth-generation Tensor Cores; 10 TPC multi-instance GPU; up to 1.57 GHz |
| CPU | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | 14-core Arm Neoverse-V3AE 64-bit CPU; 1 MB L2 cache per core; 16 MB shared L3 cache; up to 2.6 GHz | 14-core Arm Neoverse-V3AE 64-bit CPU; 1 MB L2 cache per core; 16 MB shared L3 cache; up to 2.6 GHz | 14-core Arm Neoverse-V3AE 64-bit CPU; 1 MB L2 cache per core; 16 MB shared L3 cache; up to 2.6 GHz | 14-core Arm Neoverse-V3AE 64-bit CPU; 1 MB L2 cache per core; 16 MB shared L3 cache; up to 2.6 GHz | 14-core Arm Neoverse-V3AE 64-bit CPU; 1 MB L2 cache per core; 16 MB shared L3 cache; up to 2.6 GHz | 14-core Arm Neoverse-V3AE 64-bit CPU; 1 MB L2 cache per core; 16 MB shared L3 cache; up to 2.6 GHz | 14-core Arm Neoverse-V3AE 64-bit CPU; 1 MB L2 cache per core; 16 MB shared L3 cache; up to 2.6 GHz | 14-core Arm Neoverse-V3AE 64-bit CPU; 1 MB L2 cache per core; 16 MB shared L3 cache; up to 2.6 GHz | 14-core Arm Neoverse-V3AE 64-bit CPU; 1 MB L2 cache per core; 16 MB shared L3 cache; up to 2.6 GHz | 14-core Arm Neoverse-V3AE 64-bit CPU; 1 MB L2 cache per core; 16 MB shared L3 cache; up to 2.6 GHz | 14-core Arm Neoverse-V3AE 64-bit CPU; 1 MB L2 cache per core; 16 MB shared L3 cache; up to 2.6 GHz | 14-core Arm Neoverse-V3AE 64-bit CPU; 1 MB L2 cache per core; 16 MB shared L3 cache; up to 2.6 GHz | 14-core Arm Neoverse-V3AE 64-bit CPU; 1 MB L2 cache per core; 16 MB shared L3 cache; up to 2.6 GHz | 14-core Arm Neoverse-V3AE 64-bit CPU; 1 MB L2 cache per core; 16 MB shared L3 cache; up to 2.6 GHz | 14-core Arm Neoverse-V3AE 64-bit CPU; 1 MB L2 cache per core; 16 MB shared L3 cache; up to 2.6 GHz |
| Memory | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | 128 GB 256-bit LPDDR5X; 273 GB/s | 128 GB 256-bit LPDDR5X; 273 GB/s | 128 GB 256-bit LPDDR5X; 273 GB/s | 128 GB 256-bit LPDDR5X; 273 GB/s | 128 GB 256-bit LPDDR5X; 273 GB/s | 128 GB 256-bit LPDDR5X; 273 GB/s | 128 GB 256-bit LPDDR5X; 273 GB/s | 128 GB 256-bit LPDDR5X; 273 GB/s | 128 GB 256-bit LPDDR5X; 273 GB/s | 128 GB 256-bit LPDDR5X; 273 GB/s | 128 GB 256-bit LPDDR5X; 273 GB/s | 128 GB 256-bit LPDDR5X; 273 GB/s | 128 GB 256-bit LPDDR5X; 273 GB/s | 128 GB 256-bit LPDDR5X; 273 GB/s | 128 GB 256-bit LPDDR5X; 273 GB/s |
| Storage | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | NVMe SSD via PCIe; SSD via USB 3.2 | NVMe SSD via PCIe; SSD via USB 3.2 | NVMe SSD via PCIe; SSD via USB 3.2 | NVMe SSD via PCIe; SSD via USB 3.2 | NVMe SSD via PCIe; SSD via USB 3.2 | NVMe SSD via PCIe; SSD via USB 3.2 | NVMe SSD via PCIe; SSD via USB 3.2 | NVMe SSD via PCIe; SSD via USB 3.2 | NVMe SSD via PCIe; SSD via USB 3.2 | NVMe SSD via PCIe; SSD via USB 3.2 | NVMe SSD via PCIe; SSD via USB 3.2 | NVMe SSD via PCIe; SSD via USB 3.2 | NVMe SSD via PCIe; SSD via USB 3.2 | NVMe SSD via PCIe; SSD via USB 3.2 | NVMe SSD via PCIe; SSD via USB 3.2 |
| Vision accelerator | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | 1 × PVA v3 | 1 × PVA v3 | 1 × PVA v3 | 1 × PVA v3 | 1 × PVA v3 | 1 × PVA v3 | 1 × PVA v3 | 1 × PVA v3 | 1 × PVA v3 | 1 × PVA v3 | 1 × PVA v3 | 1 × PVA v3 | 1 × PVA v3 | 1 × PVA v3 | 1 × PVA v3 |
| Video encoding | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | 2 × NVENC | 2 × NVENC | 2 × NVENC | 2 × NVENC | 2 × NVENC | 2 × NVENC | 2 × NVENC | 2 × NVENC | 2 × NVENC | 2 × NVENC | 2 × NVENC | 2 × NVENC | 2 × NVENC | 2 × NVENC | 2 × NVENC |
| Video decoding | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | 2 × NVDEC | 2 × NVDEC | 2 × NVDEC | 2 × NVDEC | 2 × NVDEC | 2 × NVDEC | 2 × NVDEC | 2 × NVDEC | 2 × NVDEC | 2 × NVDEC | 2 × NVDEC | 2 × NVDEC | 2 × NVDEC | 2 × NVDEC | 2 × NVDEC |
| Expansion slots / options | – | PC3 and PC4 use a B2-style card-slot form factor; high-performance modules are optional | PC3 and PC4 use a B2-style card-slot form factor; high-performance modules are optional | PC3 and PC4 use a B2-style card-slot form factor; high-performance modules are optional | PC3 and PC4 use a B2-style card-slot form factor; high-performance modules are optional | PC3 and PC4 use a B2-style card-slot form factor; high-performance modules are optional | PC3 and PC4 use a B2-style card-slot form factor; high-performance modules are optional | PC3 and PC4 use a B2-style card-slot form factor; high-performance modules are optional | PC3 and PC4 use a B2-style card-slot form factor; high-performance modules are optional | PC3 and PC4 use a B2-style card-slot form factor; high-performance modules are optional | PC3 and PC4 use a B2-style card-slot form factor; high-performance modules are optional | PC3 and PC4 use a B2-style card-slot form factor; high-performance modules are optional | PC3 and PC4 use a B2-style card-slot form factor; high-performance modules are optional | PC3 and PC4 use a B2-style card-slot form factor; high-performance modules are optional | PC3 and PC4 use a B2-style card-slot form factor; high-performance modules are optional | NVIDIA Jetson Thor installed in PC3; PC4 supports an optional Intel Core i7 | NVIDIA Jetson Thor installed in PC3; PC4 supports an optional Intel Core i7 | NVIDIA Jetson Thor installed in PC3; PC4 supports an optional Intel Core i7 | NVIDIA Jetson Thor installed in PC3; PC4 supports an optional Intel Core i7 | NVIDIA Jetson Thor installed in PC3; PC4 supports an optional Intel Core i7 | NVIDIA Jetson Thor installed in PC3; PC4 supports an optional Intel Core i7 | NVIDIA Jetson Thor installed in PC3; PC4 supports an optional Intel Core i7 | NVIDIA Jetson Thor installed in PC3; PC4 supports an optional Intel Core i7 | NVIDIA Jetson Thor installed in PC3; PC4 supports an optional Intel Core i7 | NVIDIA Jetson Thor installed in PC3; PC4 supports an optional Intel Core i7 | NVIDIA Jetson Thor installed in PC3; PC4 supports an optional Intel Core i7 | NVIDIA Jetson Thor installed in PC3; PC4 supports an optional Intel Core i7 | NVIDIA Jetson Thor installed in PC3; PC4 supports an optional Intel Core i7 | NVIDIA Jetson Thor installed in PC3; PC4 supports an optional Intel Core i7 | NVIDIA Jetson Thor installed in PC3; PC4 supports an optional Intel Core i7 |
| Smart OTA updates | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes |
| Secondary development | No | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes |
| Development level | Secondary development is not supported | Secondary development supported | Secondary development supported | Secondary development supported | Secondary development supported | Secondary development supported | Secondary development supported | Secondary development supported | Secondary development supported | Secondary development supported | Secondary development supported | Secondary development supported | Secondary development supported | Secondary development supported | Secondary development supported | User development via Intel Core i7 with NVIDIA Jetson Thor high-performance computing | User development via Intel Core i7 with NVIDIA Jetson Thor high-performance computing | User development via Intel Core i7 with NVIDIA Jetson Thor high-performance computing | User development via Intel Core i7 with NVIDIA Jetson Thor high-performance computing | User development via Intel Core i7 with NVIDIA Jetson Thor high-performance computing | User development via Intel Core i7 with NVIDIA Jetson Thor high-performance computing | User development via Intel Core i7 with NVIDIA Jetson Thor high-performance computing | User development via Intel Core i7 with NVIDIA Jetson Thor high-performance computing | User development via Intel Core i7 with NVIDIA Jetson Thor high-performance computing | User development via Intel Core i7 with NVIDIA Jetson Thor high-performance computing | User development via Intel Core i7 with NVIDIA Jetson Thor high-performance computing | User development via Intel Core i7 with NVIDIA Jetson Thor high-performance computing | User development via Intel Core i7 with NVIDIA Jetson Thor high-performance computing | User development via Intel Core i7 with NVIDIA Jetson Thor high-performance computing | User development via Intel Core i7 with NVIDIA Jetson Thor high-performance computing |
| Perception, Audio & Connectivity | ||||||||||||||||||||||||||||||
| Perception sensors | Wide-FOV bionic binocular camera and array microphones | Wide-FOV bionic binocular camera and array microphones | Wide-FOV bionic binocular camera and array microphones | Wide-FOV bionic binocular camera and array microphones | Wide-FOV bionic binocular camera and array microphones | Wide-FOV bionic binocular camera and array microphones | Wide-FOV bionic binocular camera and array microphones | Wide-FOV bionic binocular camera and array microphones | Wide-FOV bionic binocular camera and array microphones | Wide-FOV bionic binocular camera and array microphones | Wide-FOV bionic binocular camera and array microphones | Wide-FOV bionic binocular camera and array microphones | Wide-FOV bionic binocular camera and array microphones | Wide-FOV bionic binocular camera and array microphones | Wide-FOV bionic binocular camera and array microphones | Wide-FOV bionic binocular camera and array microphones | Wide-FOV bionic binocular camera and array microphones | Wide-FOV bionic binocular camera and array microphones | Wide-FOV bionic binocular camera and array microphones | Wide-FOV bionic binocular camera and array microphones | Wide-FOV bionic binocular camera and array microphones | Wide-FOV bionic binocular camera and array microphones | Wide-FOV bionic binocular camera and array microphones | Wide-FOV bionic binocular camera and array microphones | Wide-FOV bionic binocular camera and array microphones | Wide-FOV bionic binocular camera and array microphones | Wide-FOV bionic binocular camera and array microphones | Wide-FOV bionic binocular camera and array microphones | Wide-FOV bionic binocular camera and array microphones | Wide-FOV bionic binocular camera and array microphones |
| Head binocular camera | Wide-FOV bionic binocular camera | Wide-FOV bionic binocular camera | Wide-FOV bionic binocular camera | Wide-FOV bionic binocular camera | Wide-FOV bionic binocular camera | Wide-FOV bionic binocular camera | Wide-FOV bionic binocular camera | Wide-FOV bionic binocular camera | Wide-FOV bionic binocular camera | Wide-FOV bionic binocular camera | Wide-FOV bionic binocular camera | Wide-FOV bionic binocular camera | Wide-FOV bionic binocular camera | Wide-FOV bionic binocular camera | Wide-FOV bionic binocular camera | Wide-FOV bionic binocular camera | Wide-FOV bionic binocular camera | Wide-FOV bionic binocular camera | Wide-FOV bionic binocular camera | Wide-FOV bionic binocular camera | Wide-FOV bionic binocular camera | Wide-FOV bionic binocular camera | Wide-FOV bionic binocular camera | Wide-FOV bionic binocular camera | Wide-FOV bionic binocular camera | Wide-FOV bionic binocular camera | Wide-FOV bionic binocular camera | Wide-FOV bionic binocular camera | Wide-FOV bionic binocular camera | Wide-FOV bionic binocular camera |
| Audio input | Array microphones | Array microphones | Array microphones | Array microphones | Array microphones | Array microphones | Array microphones | Array microphones | Array microphones | Array microphones | Array microphones | Array microphones | Array microphones | Array microphones | Array microphones | Array microphones | Array microphones | Array microphones | Array microphones | Array microphones | Array microphones | Array microphones | Array microphones | Array microphones | Array microphones | Array microphones | Array microphones | Array microphones | Array microphones | Array microphones |
| Audio output | – | High-power speaker | High-power speaker | High-power speaker | High-power speaker | High-power speaker | High-power speaker | High-power speaker | High-power speaker | High-power speaker | High-power speaker | High-power speaker | High-power speaker | High-power speaker | High-power speaker | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – |
| Wi-Fi | WiFi 6 | WiFi 6 | WiFi 6 | WiFi 6 | WiFi 6 | WiFi 6 | WiFi 6 | WiFi 6 | WiFi 6 | WiFi 6 | WiFi 6 | WiFi 6 | WiFi 6 | WiFi 6 | WiFi 6 | WiFi 6 | WiFi 6 | WiFi 6 | WiFi 6 | WiFi 6 | WiFi 6 | WiFi 6 | WiFi 6 | WiFi 6 | WiFi 6 | WiFi 6 | WiFi 6 | WiFi 6 | WiFi 6 | WiFi 6 |
| Bluetooth | Bluetooth 5.2 | Bluetooth 5.2 | Bluetooth 5.2 | Bluetooth 5.2 | Bluetooth 5.2 | Bluetooth 5.2 | Bluetooth 5.2 | Bluetooth 5.2 | Bluetooth 5.2 | Bluetooth 5.2 | Bluetooth 5.2 | Bluetooth 5.2 | Bluetooth 5.2 | Bluetooth 5.2 | Bluetooth 5.2 | Bluetooth 5.2 | Bluetooth 5.2 | Bluetooth 5.2 | Bluetooth 5.2 | Bluetooth 5.2 | Bluetooth 5.2 | Bluetooth 5.2 | Bluetooth 5.2 | Bluetooth 5.2 | Bluetooth 5.2 | Bluetooth 5.2 | Bluetooth 5.2 | Bluetooth 5.2 | Bluetooth 5.2 | Bluetooth 5.2 |
| Hand / End Effector | ||||||||||||||||||||||||||||||
| Hand / end-effector model | No dexterous hands included | Dexterous hands are optional and not included as standard | Dex1-1 Plus grippers × 2 | Dex3-1 force-controlled three-finger dexterous hands × 2 | Dex3-1 force-controlled three-finger dexterous hands × 2 | Dex5-1 five-finger dexterous hands × 2 | Dex5-1P five-finger dexterous hands × 2 | BrainCo Revo 2 Basic dexterous hands × 2 | BrainCo Revo 2 Touch dexterous hands × 2 | Inspire DFQ dexterous hands × 2 | Inspire E2 dexterous hands × 2 | BrainCo Revo 3 U21 dexterous hands × 2 | BrainCo Revo 3 U21T dexterous hands × 2 | BrainCo Revo 3 U21VT visual-tactile dexterous hands × 2 | Wuji Hand 2 five-finger dexterous hands × 2 | Dexterous hands are optional and not included as standard | Dex1-1 Plus grippers × 2 | Dex3-1 force-controlled three-finger dexterous hands × 2 | Dex3-1 force-controlled three-finger dexterous hands × 2 | Dex5-1 five-finger dexterous hands × 2 | Dex5-1P five-finger dexterous hands × 2 | BrainCo Revo 2 Basic dexterous hands × 2 | BrainCo Revo 2 Touch dexterous hands × 2 | Inspire DFQ dexterous hands × 2 | Inspire E2 dexterous hands × 2 | BrainCo Revo 3 U21 dexterous hands × 2 | BrainCo Revo 3 U21T dexterous hands × 2 | BrainCo Revo 3 U21VT visual-tactile dexterous hands × 2 | Wuji Hand 2 five-finger dexterous hands × 2 | Sharpa five-finger visual-tactile dexterous hands × 2 |
| Tactile sensing | – | – | No | No | Yes | No | Yes | No | Yes | No | Yes | No | Yes | Yes | No | – | No | No | Yes | No | Yes | No | Yes | No | Yes | No | Yes | Yes | No | Yes |
| Single hand/end-effector weight | – | – | 550 g | 650 g | 650 g | – | – | 383 g | 383 g | – | 800 g | – | – | – | – | – | 550 g | 650 g | 650 g | – | – | 383 g | 383 g | – | 800 g | – | – | – | – | 1 300 g |
| Hand/end-effector dimensions | – | – | 143 × 78 × 67 mm | 175 × 88 × 77 mm | 175 × 88 × 77 mm | – | – | – | – | – | – | 215 × 105 × 50 mm | 215 × 105 × 50 mm | 215 × 105 × 50 mm | Approximately 185 × 80 × 40 mm | – | 143 × 78 × 67 mm | 175 × 88 × 77 mm | 175 × 88 × 77 mm | – | – | – | – | – | – | 215 × 105 × 50 mm | 215 × 105 × 50 mm | 215 × 105 × 50 mm | Approximately 185 × 80 × 40 mm | 208 × 90 × 50 mm |
| Operating voltage | – | – | – | 12–58 V | 12–58 V | 24–60 V | 24–60 V | – | – | – | 24 V ±10% | 12–80 V | 12–80 V | 12–80 V | 16–58 V DC | – | – | 12–58 V | 12–58 V | 24–60 V | 24–60 V | – | – | – | 24 V ±10% | 12–80 V | 12–80 V | 12–80 V | 16–58 V DC | – |
| Static current | – | – | – | 58 V @ 0.2 A | 58 V @ 0.2 A | 58 V @ 0.2 A | 58 V @ 0.2 A | – | – | – | 0.25 A | – | – | – | – | – | – | 58 V @ 0.2 A | 58 V @ 0.2 A | 58 V @ 0.2 A | 58 V @ 0.2 A | – | – | – | 0.25 A | – | – | – | – | – |
| Maximum current | – | – | – | – | – | 58 V @ 3 A | 58 V @ 3 A | – | – | – | 4 A | 10 A @ 24 V | 10 A @ 24 V | 10 A @ 24 V | – | – | – | – | – | 58 V @ 3 A | 58 V @ 3 A | – | – | – | 4 A | 10 A @ 24 V | 10 A @ 24 V | 10 A @ 24 V | – | – |
| Communication interface / protocol | – | – | High-speed 485 | USB | USB | USB 2.0 | USB 2.0 | – | – | – | – | – | – | – | Ethernet 1000BASE-T | – | High-speed 485 | USB | USB | USB 2.0 | USB 2.0 | – | – | – | – | – | – | – | Ethernet 1000BASE-T | – |
| Repeatability / control accuracy | – | – | – | – | – | ±1 mm | ±1 mm | 0.1° | 0.1° | ±0.20 mm | ±0.20 mm | 0.1° | 0.1° | – | – | – | – | – | – | ±1 mm | ±1 mm | 0.1° | 0.1° | ±0.20 mm | ±0.20 mm | 0.1° | 0.1° | – | – | ±1 mm |
| Whole-hand / gripping force | – | – | 5–120 N adjustable | – | – | – | – | 50 N | 50 N | – | – | 70 N | 70 N | 70 N | – | – | 5–120 N adjustable | – | – | – | – | 50 N | 50 N | – | – | 70 N | 70 N | 70 N | – | 150 N |
| Fingertip / pinch force | – | – | – | – | – | 10 N fingertip force | 10 N fingertip force | 15 N | 15 N | – | – | 20 N | 20 N | 20 N | ≥15 N fingertip peak force | – | – | – | – | 10 N fingertip force | 10 N fingertip force | 15 N | 15 N | – | – | 20 N | 20 N | 20 N | ≥15 N fingertip peak force | 20 N fingertip force |
| Thumb gripping force | – | – | – | – | – | – | – | – | – | 6 N | 30 N | – | – | – | – | – | – | – | – | – | – | – | – | 6 N | 30 N | – | – | – | – | – |
| Four-finger gripping force | – | – | – | – | – | – | – | – | – | 4 N | 28 N | – | – | – | – | – | – | – | – | – | – | – | – | 4 N | 28 N | – | – | – | – | – |
| Whole-hand payload | – | – | – | – | – | Maximum 3.5 kg palm down; maximum 4.5 kg palm left | Maximum 3.5 kg palm down; maximum 4.5 kg palm left | – | – | – | – | 20 kg | 20 kg | – | – | – | – | – | – | Maximum 3.5 kg palm down; maximum 4.5 kg palm left | Maximum 3.5 kg palm down; maximum 4.5 kg palm left | – | – | – | – | 20 kg | 20 kg | – | – | 30 kg |
| Four-finger payload | – | – | – | – | – | – | – | – | – | – | – | 5 kg | 5 kg | – | – | – | – | – | – | – | – | – | – | – | – | 5 kg | 5 kg | – | – | – |
| Form-closure gripping payload | – | – | 20 kg | – | – | – | – | – | – | – | – | – | – | – | – | – | 20 kg | – | – | – | – | – | – | – | – | – | – | – | – | – |
| Friction gripping payload | – | – | 5 kg | – | – | – | – | – | – | – | – | – | – | – | – | – | 5 kg | – | – | – | – | – | – | – | – | – | – | – | – | – |
| Tactile sensors / pixels per hand | – | – | – | – | 33 per hand | – | 12 arrays / 94 pressure sensors per hand | – | – | – | 17 per hand | – | – | – | – | – | – | – | 33 per hand | – | 12 arrays / 94 pressure sensors per hand | – | – | – | 17 per hand | – | – | – | – | >1000 pixels per fingertip |
| Tactile sensing capabilities | – | – | – | – | – | – | Pressure sensing plus joint mode, position, velocity, torque and IMU feedback | – | Pressure, friction, direction and proximity | – | – | – | Full-palm array tactile sensing | Full-palm array tactile and fingertip visual-tactile sensing | – | – | – | – | – | – | Pressure sensing plus joint mode, position, velocity, torque and IMU feedback | – | Pressure, friction, direction and proximity | – | – | – | Full-palm array tactile sensing | Full-palm array tactile and fingertip visual-tactile sensing | – | – |
| Tactile / force-detection range | – | – | – | – | – | – | 10 g–2500 g | – | – | – | 0–30 N | – | 0–25 N | 0–25 N | 0–30 N | – | – | – | – | – | 10 g–2500 g | – | – | – | 0–30 N | – | 0–25 N | 0–25 N | 0–30 N | 0–30 N |
| Tactile accuracy / sensitivity | – | – | – | – | – | – | – | – | – | – | ≤5% FS | – | 0.01 N resolution | 0.01 N resolution | 0.005 N sensitivity | – | – | – | – | – | – | – | – | – | ≤5% FS | – | 0.01 N resolution | 0.01 N resolution | 0.005 N sensitivity | 0.005 N sensitivity |
| Minimum visual-tactile deformation | – | – | – | – | – | – | – | – | – | – | – | – | – | 130 µm | – | – | – | – | – | – | – | – | – | – | – | – | – | 130 µm | – | – |
| Hand motion speed | – | – | – | – | – | – | – | – | – | Thumb lateral swing 235°/s; thumb flexion 150°/s; four-finger flexion 570°/s | Thumb lateral swing >130°/s; thumb flexion >130°/s; four-finger flexion >200°/s | 3 Hz opening/closing | 3 Hz opening/closing | 3 Hz opening/closing | ≥4 cycles/s | – | – | – | – | – | – | – | – | Thumb lateral swing 235°/s; thumb flexion 150°/s; four-finger flexion 570°/s | Thumb lateral swing >130°/s; thumb flexion >130°/s; four-finger flexion >200°/s | 3 Hz opening/closing | 3 Hz opening/closing | 3 Hz opening/closing | ≥4 cycles/s | >4 Hz |
| Gripper stroke | – | – | 90 mm | – | – | – | – | – | – | – | – | – | – | – | – | – | 90 mm | – | – | – | – | – | – | – | – | – | – | – | – | – |
| Closing time | – | – | 0.24 s minimum for full stroke | – | – | – | – | – | – | – | 0.8 s palm closing time | – | – | – | – | – | 0.24 s minimum for full stroke | – | – | – | – | – | – | – | 0.8 s palm closing time | – | – | – | – | – |
| Finger / claw length | – | – | 80 mm | – | – | – | – | – | – | – | – | – | – | – | – | – | 80 mm | – | – | – | – | – | – | – | – | – | – | – | – | – |
| Minimum grasping diameter | – | – | – | – | – | 10 mm | 10 mm | – | – | – | – | 10 mm | 10 mm | 10 mm | 0 mm | – | – | – | – | 10 mm | 10 mm | – | – | – | – | 10 mm | 10 mm | 10 mm | 0 mm | – |
| Maximum grasping diameter | – | – | – | – | – | – | – | – | – | – | – | 150 mm | 150 mm | – | – | – | – | – | – | – | – | – | – | – | – | 150 mm | 150 mm | – | – | – |
| Control frequency | – | – | – | – | – | 1000 Hz | 1000 Hz | – | – | – | – | 500 Hz | 500 Hz | 500 Hz | 1000 Hz × 20 axes | – | – | – | – | 1000 Hz | 1000 Hz | – | – | – | – | 500 Hz | 500 Hz | 500 Hz | 1000 Hz × 20 axes | – |
| Control mode | – | – | – | – | – | – | – | – | – | – | – | – | – | – | MIT hybrid force/position control | – | – | – | – | – | – | – | – | – | – | – | – | – | MIT hybrid force/position control | – |
| Joint backlash | – | – | – | – | – | – | – | – | – | – | – | – | – | – | <1° | – | – | – | – | – | – | – | – | – | – | – | – | – | <1° | – |
| Hand operating temperature | – | – | – | – | – | −20°C to 60°C | −20°C to 60°C | – | – | – | – | – | – | – | – | – | – | – | – | −20°C to 60°C | −20°C to 60°C | – | – | – | – | – | – | – | – | – |
| Hand / end-effector notes | – | – | Fingertip position resolution: 0.1 mm. | Per hand: thumb 3 DoF, index finger 2 DoF and middle finger 2 DoF. | Per hand: thumb 3 DoF, index finger 2 DoF and middle finger 2 DoF. | Four direct-drive joints and 12 proprietary micro force-controlled compound transmission joints; proprioceptive feedback. | Maximum non-destructive tactile force: 20 kg. Four direct-drive joints and 12 proprietary micro force-controlled compound transmission joints. | Height from middle fingertip to palm base: 160 mm. | Height from middle fingertip to palm base: 160 mm. | Grip-force resolution: 0.50 N. Thumb lateral rotation range: >65°. | – | Fully direct-drive and back-drivable. | Fully direct-drive and back-drivable. | Fully direct-drive and back-drivable. The variant card calls this hand U21VT; the accessory card calls it U21V. | Direct-drive rotary joints, back-drivable, with full opposition and lateral movement. | – | Fingertip position resolution: 0.1 mm. | Per hand: thumb 3 DoF, index finger 2 DoF and middle finger 2 DoF. | Per hand: thumb 3 DoF, index finger 2 DoF and middle finger 2 DoF. | Four direct-drive joints and 12 proprietary micro force-controlled compound transmission joints; proprioceptive feedback. | Maximum non-destructive tactile force: 20 kg. Four direct-drive joints and 12 proprietary micro force-controlled compound transmission joints. | Height from middle fingertip to palm base: 160 mm. | Height from middle fingertip to palm base: 160 mm. | Grip-force resolution: 0.50 N. Thumb lateral rotation range: >65°. | – | Fully direct-drive and back-drivable. | Fully direct-drive and back-drivable. | Fully direct-drive and back-drivable. The variant card calls this hand U21VT; the accessory card calls it U21V. | Direct-drive rotary joints, back-drivable, with full opposition and lateral movement. | Visual-tactile hand with 22 active DoF per hand. |
| Wrist Camera | ||||||||||||||||||||||||||||||
| Wrist camera model | – | Optional; not included as standard | Wrist RGB cameras × 2 | Wrist RGB cameras × 2 | Wrist RGB cameras × 2 | Wrist RGB cameras × 2 | Wrist RGB cameras × 2 | Wrist RGB cameras × 2 | Wrist RGB cameras × 2 | Wrist RGB cameras × 2 | Wrist RGB cameras × 2 | Wrist RGB cameras × 2 | Wrist RGB cameras × 2 | Wrist RGB cameras × 2 | Wrist RGB cameras × 2 | Optional; not included as standard | Wrist RGB cameras × 2 | Wrist RGB cameras × 2 | Wrist RGB cameras × 2 | Wrist RGB cameras × 2 | Wrist RGB cameras × 2 | Wrist RGB cameras × 2 | Wrist RGB cameras × 2 | Wrist RGB cameras × 2 | Wrist RGB cameras × 2 | Senyun SHF3L wrist RGB cameras × 2 | Senyun SHF3L wrist RGB cameras × 2 | Senyun SHF3L wrist RGB cameras × 2 | Wrist RGB cameras × 2 | Senyun SHF3L wrist RGB cameras × 2 |
| Wrist camera FOV | – | – | D 130°; H 120°; V 81° | D 130°; H 120°; V 81° | D 130°; H 120°; V 81° | D 130°; H 120°; V 81° | D 130°; H 120°; V 81° | D 130°; H 120°; V 81° | D 130°; H 120°; V 81° | D 130°; H 120°; V 81° | D 130°; H 120°; V 81° | D 130°; H 120°; V 81° | D 130°; H 120°; V 81° | D 130°; H 120°; V 81° | D 130°; H 120°; V 81° | – | D 130°; H 120°; V 81° | D 130°; H 120°; V 81° | D 130°; H 120°; V 81° | D 130°; H 120°; V 81° | D 130°; H 120°; V 81° | D 130°; H 120°; V 81° | D 130°; H 120°; V 81° | D 130°; H 120°; V 81° | D 130°; H 120°; V 81° | HFOV 196° | HFOV 196° | HFOV 196° | D 130°; H 120°; V 81° | HFOV 196° |
| Wrist camera resolution | – | – | 1920 × 1080 | 1920 × 1080 | 1920 × 1080 | 1920 × 1080 | 1920 × 1080 | 1920 × 1080 | 1920 × 1080 | 1920 × 1080 | 1920 × 1080 | 1920 × 1080 | 1920 × 1080 | 1920 × 1080 | 1920 × 1080 | – | 1920 × 1080 | 1920 × 1080 | 1920 × 1080 | 1920 × 1080 | 1920 × 1080 | 1920 × 1080 | 1920 × 1080 | 1920 × 1080 | 1920 × 1080 | 1920 × 1536 | 1920 × 1536 | 1920 × 1536 | 1920 × 1080 | 1920 × 1536 |
| Wrist camera weight | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | <50 g per camera | <50 g per camera | <50 g per camera | – | <50 g per camera |
| Wrist camera dimensions | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | 25 × 25 × 33.54 mm | 25 × 25 × 33.54 mm | 25 × 25 × 33.54 mm | – | 25 × 25 × 33.54 mm |
| Wrist camera frame rate | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | 1920 × 1536 @ 30 fps | 1920 × 1536 @ 30 fps | 1920 × 1536 @ 30 fps | – | 1920 × 1536 @ 30 fps |
| Image sensor | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | RGGB | RGGB | RGGB | – | RGGB |
| ISP | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | Built-in | Built-in | Built-in | – | Built-in |
| Output format | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | YUV422 8-bit | YUV422 8-bit | YUV422 8-bit | – | YUV422 8-bit |
| Shutter type | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | Rolling shutter | Rolling shutter | Rolling shutter | – | Rolling shutter |
| Wrist camera operating temperature | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | −40°C to 85°C | −40°C to 85°C | −40°C to 85°C | – | −40°C to 85°C |
| Development-kit compatibility | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | NVIDIA Jetson AGX Thor | NVIDIA Jetson AGX Thor | NVIDIA Jetson AGX Thor | – | NVIDIA Jetson AGX Thor |
| Package, Warranty & Notes | ||||||||||||||||||||||||||||||
| Included items | 1 smart quick-release battery; 1 charger; 1 handheld remote controller; protective bracket | 1 charger; 1 smart quick-release battery; 1 handheld remote controller; protective bracket | 1 charger; 1 smart quick-release battery; 1 handheld remote controller; protective bracket | 1 charger; 1 smart quick-release battery; 1 handheld remote controller; protective bracket | 1 charger; 1 smart quick-release battery; 1 handheld remote controller; protective bracket | 1 charger; 1 smart quick-release battery; 1 handheld remote controller; protective bracket | 1 charger; 1 smart quick-release battery; 1 handheld remote controller; protective bracket | 1 charger; 1 smart quick-release battery; 1 handheld remote controller; protective bracket | 1 charger; 1 smart quick-release battery; 1 handheld remote controller; protective bracket | 1 charger; 1 smart quick-release battery; 1 handheld remote controller; protective bracket | 1 charger; 1 smart quick-release battery; 1 handheld remote controller; protective bracket | 1 charger; 1 smart quick-release battery; 1 handheld remote controller; protective bracket | 1 charger; 1 smart quick-release battery; 1 handheld remote controller; protective bracket | 1 charger; 1 smart quick-release battery; 1 handheld remote controller; protective bracket | 1 charger; 1 smart quick-release battery; 1 handheld remote controller; protective bracket | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – |
| Protective bracket included | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – |
| Whole-unit warranty | 8 months | 12 months | 12 months | 12 months | 12 months | 12 months | 12 months | 12 months | 12 months | 12 months | 12 months | 12 months | 12 months | 12 months | 12 months | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – |
| Warranty / option notes | – | Dexterous hands and wrist cameras are available as paid options | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – |
| Additional specification notes | H2 has a bionic face. Dimensions and weight are stated for the standing robot with battery. Arm payload is approximately 15 kg peak and approximately 7 kg rated. | H2 has a bionic face. Dimensions and weight are stated for the standing robot with battery. Arm payload is approximately 15 kg peak and approximately 7 kg rated. | H2 has a bionic face. Dimensions and weight are stated for the standing robot with battery. Arm payload is approximately 15 kg peak and approximately 7 kg rated. | H2 has a bionic face. Dimensions and weight are stated for the standing robot with battery. Arm payload is approximately 15 kg peak and approximately 7 kg rated. | H2 has a bionic face. Dimensions and weight are stated for the standing robot with battery. Arm payload is approximately 15 kg peak and approximately 7 kg rated. | H2 has a bionic face. Dimensions and weight are stated for the standing robot with battery. Arm payload is approximately 15 kg peak and approximately 7 kg rated. | H2 has a bionic face. Dimensions and weight are stated for the standing robot with battery. Arm payload is approximately 15 kg peak and approximately 7 kg rated. | H2 has a bionic face. Dimensions and weight are stated for the standing robot with battery. Arm payload is approximately 15 kg peak and approximately 7 kg rated. | H2 has a bionic face. Dimensions and weight are stated for the standing robot with battery. Arm payload is approximately 15 kg peak and approximately 7 kg rated. | H2 has a bionic face. Dimensions and weight are stated for the standing robot with battery. Arm payload is approximately 15 kg peak and approximately 7 kg rated. | H2 has a bionic face. Dimensions and weight are stated for the standing robot with battery. Arm payload is approximately 15 kg peak and approximately 7 kg rated. | H2 has a bionic face. Dimensions and weight are stated for the standing robot with battery. Arm payload is approximately 15 kg peak and approximately 7 kg rated. | H2 has a bionic face. Dimensions and weight are stated for the standing robot with battery. Arm payload is approximately 15 kg peak and approximately 7 kg rated. | H2 has a bionic face. Dimensions and weight are stated for the standing robot with battery. Arm payload is approximately 15 kg peak and approximately 7 kg rated. | H2 has a bionic face. Dimensions and weight are stated for the standing robot with battery. Arm payload is approximately 15 kg peak and approximately 7 kg rated. | H2 has a bionic face. Dimensions and weight are stated for the standing robot with battery. Arm payload is approximately 15 kg peak and approximately 7 kg rated. | H2 has a bionic face. Dimensions and weight are stated for the standing robot with battery. Arm payload is approximately 15 kg peak and approximately 7 kg rated. | H2 has a bionic face. Dimensions and weight are stated for the standing robot with battery. Arm payload is approximately 15 kg peak and approximately 7 kg rated. | H2 has a bionic face. Dimensions and weight are stated for the standing robot with battery. Arm payload is approximately 15 kg peak and approximately 7 kg rated. | H2 has a bionic face. Dimensions and weight are stated for the standing robot with battery. Arm payload is approximately 15 kg peak and approximately 7 kg rated. | H2 has a bionic face. Dimensions and weight are stated for the standing robot with battery. Arm payload is approximately 15 kg peak and approximately 7 kg rated. | H2 has a bionic face. Dimensions and weight are stated for the standing robot with battery. Arm payload is approximately 15 kg peak and approximately 7 kg rated. | H2 has a bionic face. Dimensions and weight are stated for the standing robot with battery. Arm payload is approximately 15 kg peak and approximately 7 kg rated. | H2 has a bionic face. Dimensions and weight are stated for the standing robot with battery. Arm payload is approximately 15 kg peak and approximately 7 kg rated. | H2 has a bionic face. Dimensions and weight are stated for the standing robot with battery. Arm payload is approximately 15 kg peak and approximately 7 kg rated. | H2 has a bionic face. Dimensions and weight are stated for the standing robot with battery. Arm payload is approximately 15 kg peak and approximately 7 kg rated. | H2 has a bionic face. Dimensions and weight are stated for the standing robot with battery. Arm payload is approximately 15 kg peak and approximately 7 kg rated. | H2 has a bionic face. Dimensions and weight are stated for the standing robot with battery. Arm payload is approximately 15 kg peak and approximately 7 kg rated. | H2 has a bionic face. Dimensions and weight are stated for the standing robot with battery. Arm payload is approximately 15 kg peak and approximately 7 kg rated. | H2 has a bionic face. Dimensions and weight are stated for the standing robot with battery. Arm payload is approximately 15 kg peak and approximately 7 kg rated. |
| Configuration | H2 Basic, H2 EDU Standard, H2 EDU Smart A, H2 EDU Smart B, H2 EDU Smart C, H2 EDU Smart D, H2 EDU Smart E, H2 EDU Smart F, H2 EDU Smart G, H2 EDU Smart H, H2 EDU Smart I, H2 EDU Smart J, H2 EDU Smart K, H2 EDU Smart L, H2 EDU Smart M, H2 PLUS Smart, H2 PLUS Ultimate A, H2 PLUS Ultimate B, H2 PLUS Ultimate C, H2 PLUS Ultimate D, H2 PLUS Ultimate E, H2 PLUS Ultimate F, H2 PLUS Ultimate G, H2 PLUS Ultimate H, H2 PLUS Ultimate I, H2 PLUS Ultimate J, H2 PLUS Ultimate K, H2 PLUS Ultimate L, H2 PLUS Ultimate M, H2 PLUS Ultimate N |
|---|---|
| Brand | Unitree |
| Robot type | Humanoid robot |
| Application | Research, Education, Development, Embodied AI, Manipulation |
Unitree H2 är en tvåbent humanoidrobot i full storlek från Unitree Robotics, utvecklad för forskning, robotutveckling och avancerade tillämpningar inom artificiell intelligens. Roboten kombinerar en människoliknande konstruktion med kraftfulla ledmotorer, rörelsekontroll, sensorer och beräkningskapacitet. Med 31 frihetsgrader i grundplattformen finns förutsättningar för att utveckla och studera humanoid gång, balans, samordnade rörelser och fysisk interaktion med omgivningen.
Unitree H2 finns i flera konfigurationer med olika tekniska förutsättningar. Från H2 Basic till utvecklingsplattformarna H2 EDU och H2 PLUS kan roboten anpassas efter projektets krav på programmering, AI-beräkningar och robotiska händer.
H2 är en avancerad robotplattform, men specialiserade autonoma arbetsuppgifter kan kräva ytterligare programmering, integration och tester.
Unitree H2 kan användas för forskning och utveckling inom tvåbent rörelse, balans och styrning av humanoida robotsystem. Robotens ledkonstruktion och motorstyrning gör det möjligt att undersöka hur olika rörelser samordnas och hur roboten kan förflytta sig i fysiska miljöer.
Det gör H2 relevant för universitet, forskningsinstitutioner och utvecklingsteam som arbetar med avancerad humanoid robotik.
Unitree H2 är relevant för utveckling inom embodied AI, där artificiell intelligens används tillsammans med robotens sensorer och rörelsesystem. Genom att kombinera perception, beslutsfattande och motorstyrning kan utvecklare undersöka hur AI-modeller kan användas för att styra fysiska handlingar.
För projekt som kräver egen algoritmutveckling bör en konfiguration med stöd för vidareutveckling väljas.
Med H2 EDU och H2 PLUS kan robotplattformen användas för utvecklingsarbete där programmering, styralgoritmer och beräkningskapacitet är viktiga delar av projektet. Det kan exempelvis handla om rörelseplanering, samordning av flera robotleder eller integration av AI-baserade styrsystem.
Tillgängliga utvecklingsgränssnitt och funktioner behöver kontrolleras för vald konfiguration och programvaruversion.
Flera H2-konfigurationer kan utrustas med robotiska händer eller gripdon för forskning och utveckling inom objektmanipulation. Beroende på vald version finns alternativ för tvåfingersgrepp, trefingrad manipulation och mer avancerade fingerfärdiga händer.
Vissa konfigurationer omfattar även taktil eller visuellt-taktil avkänning, vilket är relevant för projekt där kontakt med föremål behöver registreras och analyseras.
Valet av robothand påverkar möjligheterna att utveckla olika grepp, handrörelser och manipulationsuppgifter.
Unitree H2 kan även användas i forskningsmiljöer, teknikutställningar och utvecklingsprojekt där humanoid robotik ska demonstreras eller utvärderas. Tillgängliga rörelser och funktioner beror på konfiguration, programvara och förutsättningarna i den aktuella miljön.
H2 bör inte betraktas som en färdig autonom lösning för industriella arbetsuppgifter utan att funktionerna har utvecklats och verifierats för den specifika tillämpningen.
Unitree H2 finns i flera konfigurationer med olika beräkningsplattformar, utvecklingsmöjligheter och robotiska händer. På Webot.se kan du jämföra 30 konfigurationer, fördelade mellan H2 Basic, H2 EDU och H2 PLUS.
Det viktigaste är att välja utifrån projektets krav på egen programmering, AI-beräkningar och objektmanipulation.
H2 Basic är grundkonfigurationen i serien. Den erbjuder H2 tvåbenta konstruktion med 31 frihetsgrader och en Intel Core i5-baserad beräkningsplattform. Fingerfärdiga robothänder ingår inte som standard, och H2 Basic saknar stöd för extern vidareutveckling enligt tillverkarens specifikationer.
Basic är därför främst relevant för användning som utgår från robotens befintliga funktioner, snarare än projekt där egen programmering är ett centralt krav.
H2 EDU är avsedd för projekt som kräver egen utveckling, programmering och integration. Utöver den grundläggande beräkningsplattformen har EDU-versionen en Intel Core i7-baserad utvecklingsdator enligt tillverkarens produktinformation. Webot erbjuder H2 EDU både utan fingerfärdiga händer och med olika gripdon eller robothänder.
Det gör EDU-serien relevant för universitet, forskningsinstitutioner och utvecklingsteam som vill arbeta med rörelsestyrning, AI-system och robotmanipulation.
H2 PLUS är ett alternativ för projekt med höga krav på lokal beräkningskapacitet. Konfigurationerna på Webot.se omfattar NVIDIA Jetson Thor som standard och finns med flera olika alternativ för robotiska händer. Det gör H2 PLUS relevant när utvecklingsprojektet kräver en kraftfull beräkningsplattform för exempelvis perception, AI-modeller och avancerad robotstyrning.
Vilken prestanda och vilka AI-funktioner som kan uppnås beror på programvara, modellval och den aktuella tillämpningen.
Utöver valet mellan Basic, EDU och PLUS behöver många utvecklingsprojekt ta ställning till vilken typ av gripdon eller robothand som behövs.
Dex1-1 Plus är ett alternativ för projekt där roboten ska arbeta med tvåfingersgrepp och hantering av föremål. Det kan vara relevant för forskning inom greppstyrning, objektförflyttning och utveckling av enklare manipulationsuppgifter.
Dex3-1 är en trefingrad robothand med flera frihetsgrader och kraftstyrning. Den är relevant för projekt som kräver mer avancerade grepp och samordning mellan flera fingrar. Vilka sensorfunktioner som finns beror på vald version.
Unitree H2 kan även erbjudas i konfigurationer med femfingrade händer, exempelvis från Unitrees Dex-serie och andra tillverkare. Det finns alternativ med olika antal frihetsgrader och funktioner för kraftstyrning, taktil avkänning eller visuellt-taktil återkoppling.
Dessa konfigurationer är särskilt relevanta för forskning där roboten behöver kunna utföra komplexa handrörelser och samla in information om kontakten med föremål.
Vilken robothand som ingår beror på den valda H2-konfigurationen. Separata tillbehör ska därför inte automatiskt läggas till en beställning utan att leveransomfattning och kompatibilitet har kontrollerats.
Använd produktens konfigurationsväljare och specifikationstabell för att jämföra alternativen.
Unitree H1 och H1-2 är tvåbenta humanoidrobotar i full storlek med fokus på forskning, rörelsekontroll och robotutveckling. H1 är särskilt intressant för projekt som undersöker dynamisk tvåbent rörelse, medan H1-2 erbjuder utökad rörelsefrihet i armar och ben.
Läs mer om Unitree H1/H1-2 Humanoid.
För projekt där en mindre humanoidplattform är lämpligare kan Unitree G1 vara ett alternativ. G1 finns i flera konfigurationer med olika utvecklingsmöjligheter och stöd för robotiska händer. Den är relevant för bland annat utbildning, forskning och embodied AI.
Om projektet framför allt handlar om utveckling av robotarmar och objektmanipulation, snarare än tvåbent gång, kan en överkroppsplattform vara mer ändamålsenlig.
Unitree H2-A är en kompakt humanoid överkroppsplattform för bland annat forskning och manipulation.
Unitree H2-D är en pelarmonterad humanoidplattform som erbjuds med stationär eller mobil bas, beroende på konfiguration.
Dessa alternativ kan vara relevanta för utvecklingsmiljöer där fokus ligger på gripfunktioner, rörelsedata och hantering av föremål.
Läs mer om Unitree H2-A och Unitree H2-D.
För Unitree H2 finns olika gripdon, robotiska händer och andra tillbehör som kan vara relevanta beroende på utvecklingsprojektets krav.
Valet bör utgå från önskade greppfunktioner, antal frihetsgrader, sensorfunktioner och kompatibilitet med robotens konfiguration.
När du väljer Unitree H2 bör du utgå från projektets krav på programmering, rörelsefunktioner, beräkningskapacitet och robotiska händer.
På produktsidan kan du jämföra H2 Basic, H2 EDU och H2 PLUS samt välja mellan olika konfigurationer för manipulation och AI-utveckling.
Välj önskad konfiguration och kontakta Webot för offert på Unitree H2.
Unitree H2 är en tvåbent humanoidrobot i full storlek från Unitree Robotics, utvecklad för forskning, robotutveckling och tillämpningar inom embodied AI. Roboten har 31 frihetsgrader i grundplattformen och finns i flera konfigurationer med olika möjligheter till programmering, beräkningskapacitet och robotiska händer.
Priset på Unitree H2 beror på vilken konfiguration och vilka eventuella tillbehör som väljs. Webot erbjuder roboten via offert, där pris, utrustning och leveransvillkor fastställs utifrån den aktuella beställningen. Kontakta Webot för prisuppgifter på önskad H2-version.
H2 Basic är grundmodellen med en Intel Core i5-baserad beräkningsplattform och utan stöd för extern vidareutveckling enligt tillverkarens specifikationer. H2 EDU är utvecklad för forskning och programmering och finns med olika alternativ för gripdon och robothänder. H2 PLUS-konfigurationerna på Webot.se omfattar NVIDIA Jetson Thor för högpresterande beräkningar och erbjuds med flera olika ändeffektorer.
Ja, H2 EDU stöder egen programmering och vidareutveckling. H2 Basic saknar däremot stöd för extern vidareutveckling enligt Unitrees produktinformation. För H2 PLUS bör tillgängliga utvecklingsgränssnitt och programvarufunktioner bekräftas för den aktuella konfigurationen innan beställning.
Unitree H2 har 31 frihetsgrader i grundplattformen, fördelade mellan ben, armar, midja och huvud. När roboten utrustas med fingerfärdiga händer kan det totala antalet frihetsgrader bli högre beroende på vilka händer som används. Antalet varierar därför mellan H2-konfigurationerna.
Unitree anger en batteritid på cirka tre timmar för H2. Den faktiska drifttiden påverkas av bland annat robotens rörelser, belastning, utrustning och användning. Batteritiden ska därför ses som en ungefärlig uppgift snarare än en garanterad drifttid för varje tillämpning.
Ja. Unitree H2 finns i konfigurationer med olika typer av gripdon och fingerfärdiga robothänder. Alternativen omfattar bland annat tvåfingersgripdon, trefingrade händer och femfingrade händer, med olika funktioner för kraftstyrning och taktil avkänning. Vilken utrustning som ingår beror på vald konfiguration.
Ja, H2 är relevant för forskning och utveckling inom embodied AI, där AI-modeller används tillsammans med en fysisk robots sensorer och rörelsesystem. För projekt som kräver egen programmering och modellintegration är det viktigt att välja en lämplig utvecklingskonfiguration.
Unitree H2 har avancerad rörelsekontroll och beräkningskapacitet, men är inte en färdig autonom lösning för alla industriella arbetsuppgifter. Specialiserade tillämpningar kan kräva programmering, integration, riskbedömning och tester. Tillgängliga funktioner varierar beroende på konfiguration och programvara.
Unitree H2 är en tvåbent humanoidrobot i full storlek som kan användas för forskning inom bland annat gång, balans och AI-baserad styrning. Unitree H2-D är i stället en humanoid överkroppsplattform med stationär eller mobil bas, främst inriktad på robotmanipulation och utveckling av arbetsmoment med robotarmar.