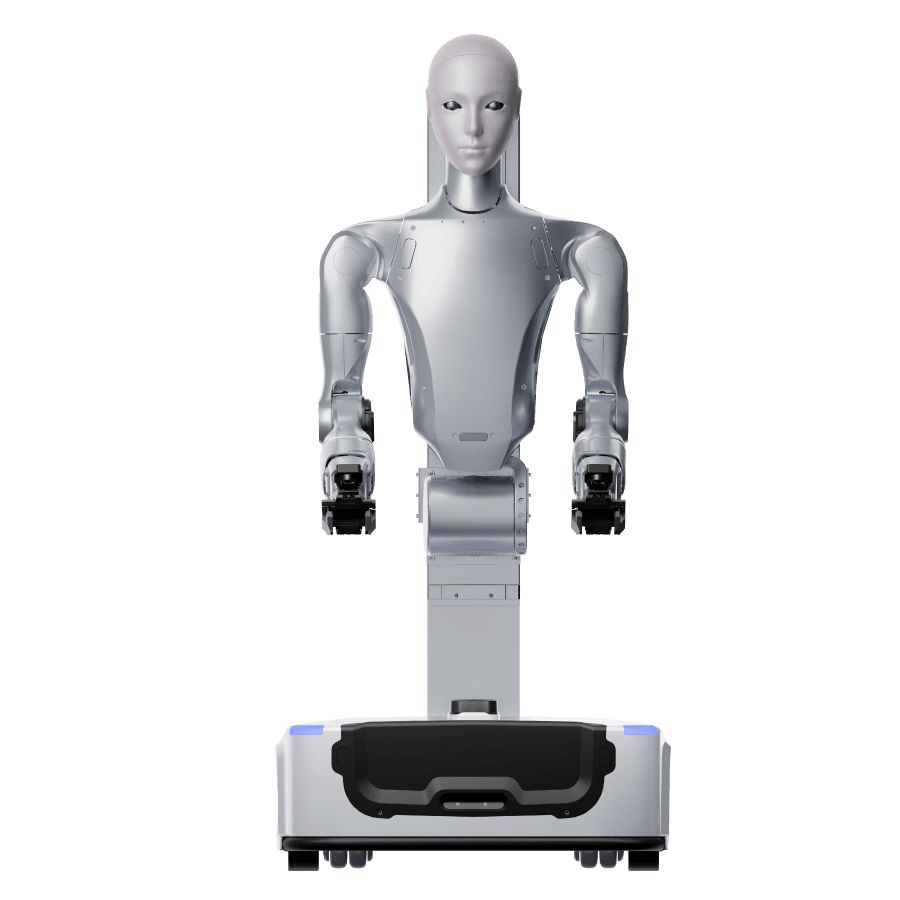
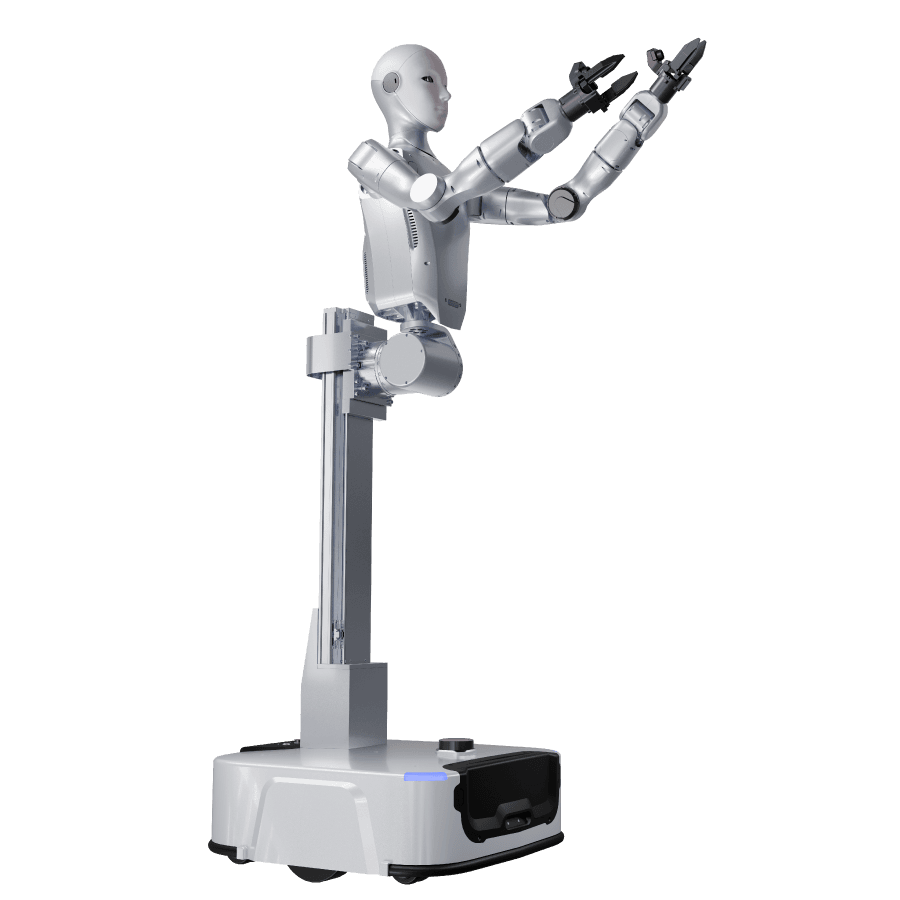
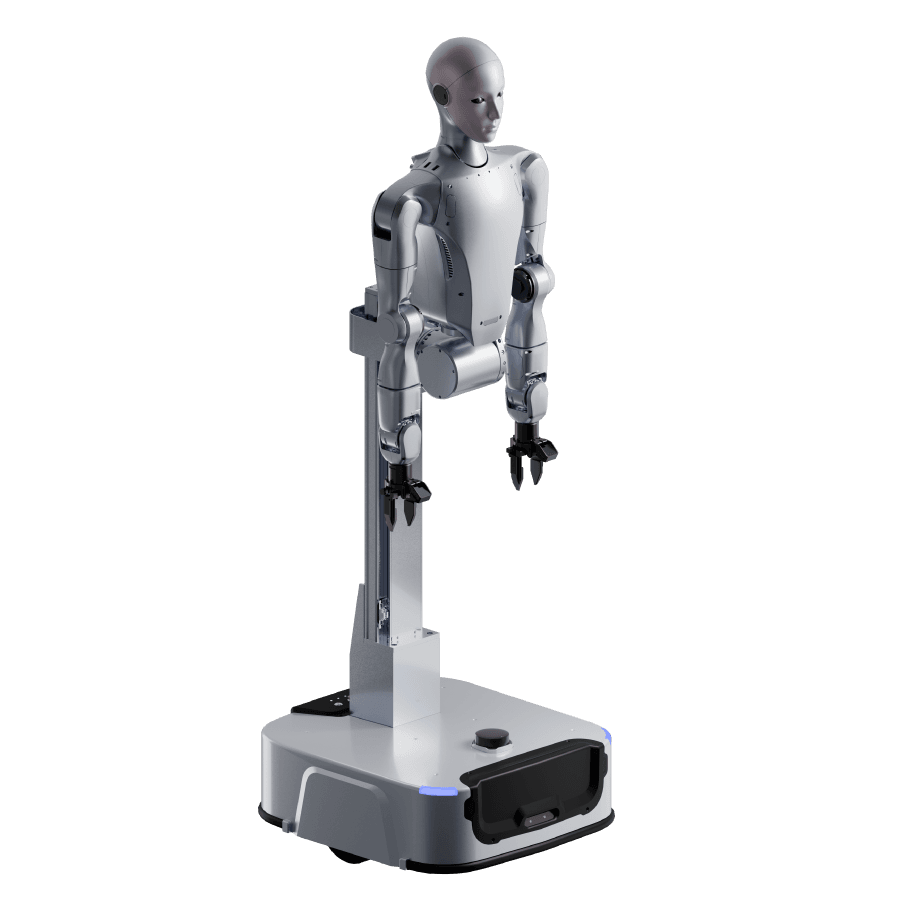
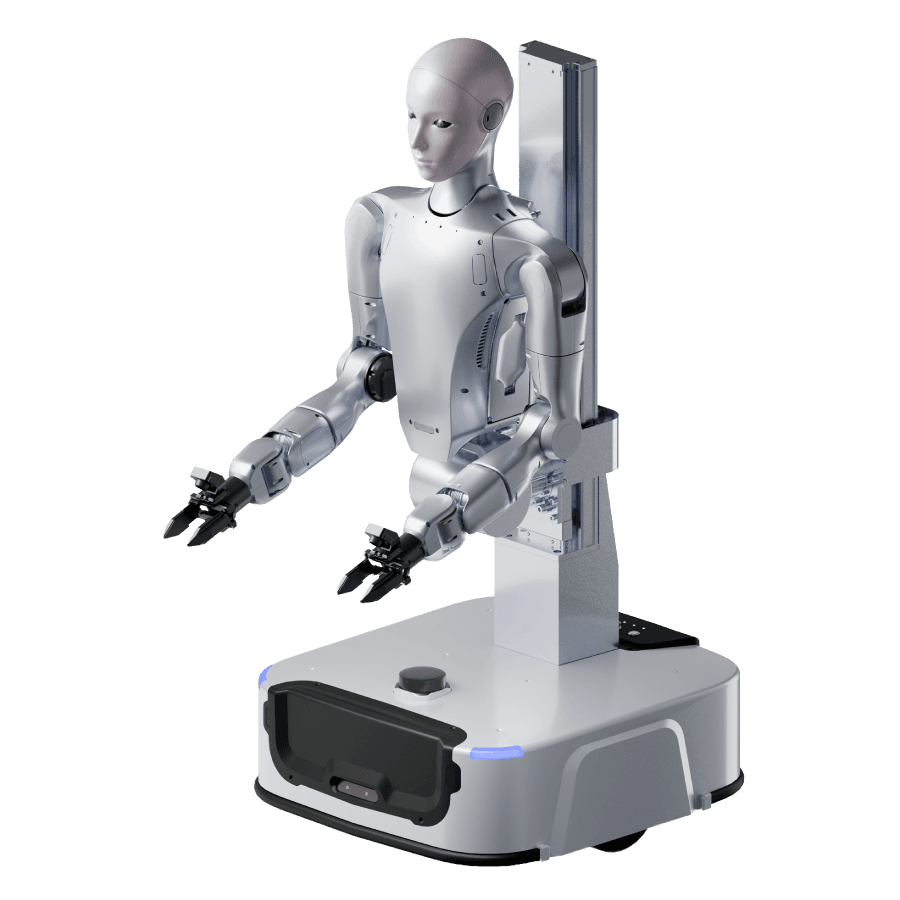
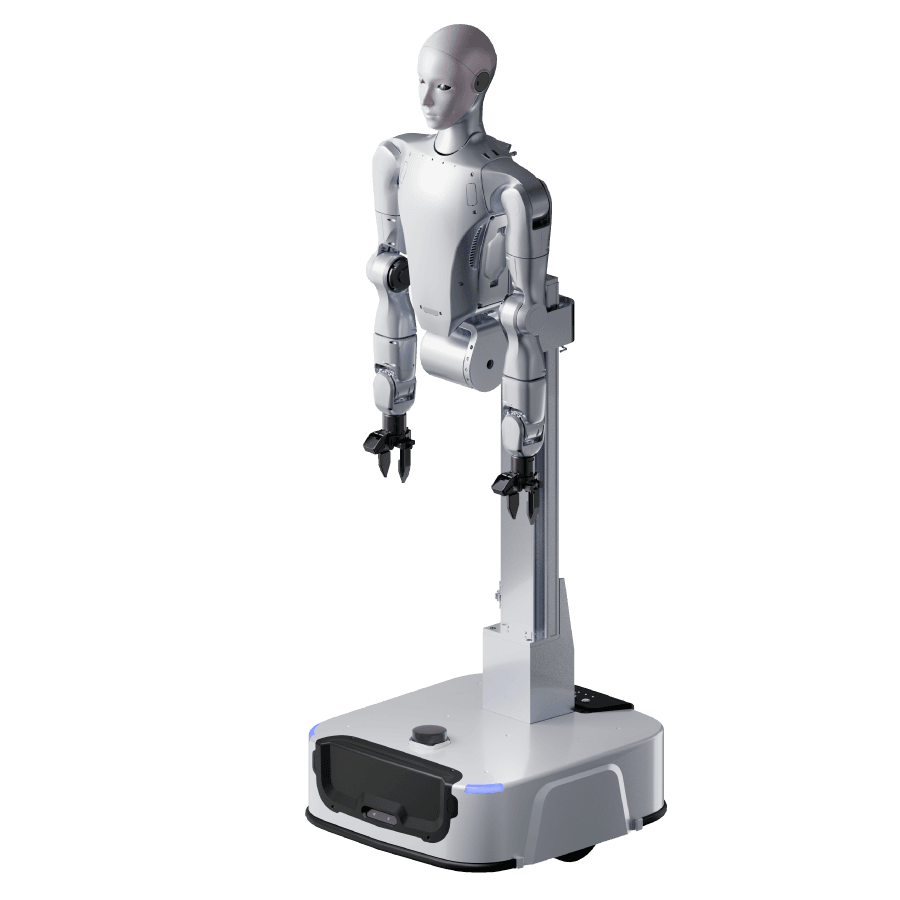
Unitree H2-D är en höjdjusterbar humanoid överkroppsplattform för forskning, embodied AI och avancerad objektmanipulation. Roboten kombinerar två robotarmar, sensorer och stöd för olika gripdon och fingerfärdiga robothänder.
Välj mellan H2-D Standard med stationär, roterande bas och H2-D Ultimate med mobil bas, LiDAR, djupkamera och automatisk laddning. Plattformen finns i 26 konfigurationer med olika möjligheter till manipulation och taktil avkänning.
H2-D Standard A kombinerar den stationära, höjdjusterbara H2-D-plattformen med Dex1-1 Standard gripdon × 2.
Slutlig kompatibilitet, leverans och prissättning bekräftas i offerten.
H2-D Standard B kombinerar den stationära, höjdjusterbara H2-D-plattformen med Dex3-1 kraftstyrda trefingrade fingerfärdiga händer × 2.
Slutlig kompatibilitet, leverans och prissättning bekräftas i offerten.
H2-D Standard C kombinerar den stationära, höjdjusterbara H2-D-plattformen med Dex3-1 kraftstyrda trefingrade fingerfärdiga händer × 2.
Slutlig kompatibilitet, leverans och prissättning bekräftas i offerten.
H2-D Standard D kombinerar den stationära, höjdjusterbara H2-D-plattformen med Dex5-1 femfingrade fingerfärdiga händer × 2.
Slutlig kompatibilitet, leverans och prissättning bekräftas i offerten.
H2-D Standard E kombinerar den stationära, höjdjusterbara H2-D-plattformen med Dex5-1P femfingrade fingerfärdiga händer × 2.
Slutlig kompatibilitet, leverans och prissättning bekräftas i offerten.
H2-D Standard F kombinerar den stationära, höjdjusterbara H2-D-plattformen med BrainCo Revo 2 Basic fingerfärdiga händer × 2.
Slutlig kompatibilitet, leverans och prissättning bekräftas i offerten.
H2-D Standard G kombinerar den stationära, höjdjusterbara H2-D-plattformen med BrainCo Revo 2 Touch fingerfärdiga händer × 2.
Slutlig kompatibilitet, leverans och prissättning bekräftas i offerten.
H2-D Standard H kombinerar den stationära, höjdjusterbara H2-D-plattformen med Inspire DFQ fingerfärdiga händer × 2.
Slutlig kompatibilitet, leverans och prissättning bekräftas i offerten.
H2-D Standard I kombinerar den stationära, höjdjusterbara H2-D-plattformen med Inspire E2 fingerfärdiga händer × 2.
Slutlig kompatibilitet, leverans och prissättning bekräftas i offerten.
H2-D Standard J kombinerar den stationära, höjdjusterbara H2-D-plattformen med BrainCo Revo 3 U21 fingerfärdiga händer × 2.
Slutlig kompatibilitet, leverans och prissättning bekräftas i offerten.
H2-D Standard K kombinerar den stationära, höjdjusterbara H2-D-plattformen med BrainCo Revo 3 U21T fingerfärdiga händer × 2.
Slutlig kompatibilitet, leverans och prissättning bekräftas i offerten.
H2-D Standard L kombinerar den stationära, höjdjusterbara H2-D-plattformen med BrainCo Revo 3 U21VT visuellt-taktila fingerfärdiga händer × 2.
Slutlig kompatibilitet, leverans och prissättning bekräftas i offerten.
H2-D Standard M kombinerar den stationära, höjdjusterbara H2-D-plattformen med Wuji Hand 2 femfingrade fingerfärdiga händer × 2.
Slutlig kompatibilitet, leverans och prissättning bekräftas i offerten.
H2-D Ultimate A kombinerar den mobila, höjdjusterbara H2-D-plattformen med Dex1-1 Advanced gripdon × 2.
Slutlig kompatibilitet, leverans och prissättning bekräftas i offerten.
H2-D Ultimate B kombinerar den mobila, höjdjusterbara H2-D-plattformen med Dex3-1 kraftstyrda trefingrade fingerfärdiga händer × 2.
Slutlig kompatibilitet, leverans och prissättning bekräftas i offerten.
H2-D Ultimate C kombinerar den mobila, höjdjusterbara H2-D-plattformen med Dex3-1 kraftstyrda trefingrade fingerfärdiga händer × 2.
Slutlig kompatibilitet, leverans och prissättning bekräftas i offerten.
H2-D Ultimate D kombinerar den mobila, höjdjusterbara H2-D-plattformen med Dex5-1 femfingrade fingerfärdiga händer × 2.
Slutlig kompatibilitet, leverans och prissättning bekräftas i offerten.
H2-D Ultimate E kombinerar den mobila, höjdjusterbara H2-D-plattformen med Dex5-1P femfingrade fingerfärdiga händer × 2.
Slutlig kompatibilitet, leverans och prissättning bekräftas i offerten.
H2-D Ultimate F kombinerar den mobila, höjdjusterbara H2-D-plattformen med BrainCo Revo 2 Basic fingerfärdiga händer × 2.
Slutlig kompatibilitet, leverans och prissättning bekräftas i offerten.
H2-D Ultimate G kombinerar den mobila, höjdjusterbara H2-D-plattformen med BrainCo Revo 2 Touch fingerfärdiga händer × 2.
Slutlig kompatibilitet, leverans och prissättning bekräftas i offerten.
H2-D Ultimate H kombinerar den mobila, höjdjusterbara H2-D-plattformen med Inspire DFQ fingerfärdiga händer × 2.
Slutlig kompatibilitet, leverans och prissättning bekräftas i offerten.
H2-D Ultimate I kombinerar den mobila, höjdjusterbara H2-D-plattformen med Inspire E2 fingerfärdiga händer × 2.
Slutlig kompatibilitet, leverans och prissättning bekräftas i offerten.
H2-D Ultimate J kombinerar den mobila, höjdjusterbara H2-D-plattformen med BrainCo Revo 3 U21 fingerfärdiga händer × 2.
Slutlig kompatibilitet, leverans och prissättning bekräftas i offerten.
H2-D Ultimate K kombinerar den mobila, höjdjusterbara H2-D-plattformen med BrainCo Revo 3 U21T fingerfärdiga händer × 2.
Slutlig kompatibilitet, leverans och prissättning bekräftas i offerten.
H2-D Ultimate L kombinerar den mobila, höjdjusterbara H2-D-plattformen med BrainCo Revo 3 U21VT visuellt-taktila fingerfärdiga händer × 2.
Slutlig kompatibilitet, leverans och prissättning bekräftas i offerten.
H2-D Ultimate M kombinerar den mobila, höjdjusterbara H2-D-plattformen med Wuji Hand 2 femfingrade fingerfärdiga händer × 2.
Slutlig kompatibilitet, leverans och prissättning bekräftas i offerten.
| Specification | H2-D Standard A | H2-D Standard B | H2-D Standard C | H2-D Standard D | H2-D Standard E | H2-D Standard F | H2-D Standard G | H2-D Standard H | H2-D Standard I | H2-D Standard J | H2-D Standard K | H2-D Standard L | H2-D Standard M | H2-D Ultimate A | H2-D Ultimate B | H2-D Ultimate C | H2-D Ultimate D | H2-D Ultimate E | H2-D Ultimate F | H2-D Ultimate G | H2-D Ultimate H | H2-D Ultimate I | H2-D Ultimate J | H2-D Ultimate K | H2-D Ultimate L | H2-D Ultimate M |
|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|
| General | ||||||||||||||||||||||||||
| Manufacturer | Unitree | Unitree | Unitree | Unitree | Unitree | Unitree | Unitree | Unitree | Unitree | Unitree | Unitree | Unitree | Unitree | Unitree | Unitree | Unitree | Unitree | Unitree | Unitree | Unitree | Unitree | Unitree | Unitree | Unitree | Unitree | Unitree |
| Model / edition | H2-D Series | H2-D Series | H2-D Series | H2-D Series | H2-D Series | H2-D Series | H2-D Series | H2-D Series | H2-D Series | H2-D Series | H2-D Series | H2-D Series | H2-D Series | H2-D Series | H2-D Series | H2-D Series | H2-D Series | H2-D Series | H2-D Series | H2-D Series | H2-D Series | H2-D Series | H2-D Series | H2-D Series | H2-D Series | H2-D Series |
| Robot type | Column-mounted humanoid upper-body robot platform | Column-mounted humanoid upper-body robot platform | Column-mounted humanoid upper-body robot platform | Column-mounted humanoid upper-body robot platform | Column-mounted humanoid upper-body robot platform | Column-mounted humanoid upper-body robot platform | Column-mounted humanoid upper-body robot platform | Column-mounted humanoid upper-body robot platform | Column-mounted humanoid upper-body robot platform | Column-mounted humanoid upper-body robot platform | Column-mounted humanoid upper-body robot platform | Column-mounted humanoid upper-body robot platform | Column-mounted humanoid upper-body robot platform | Column-mounted humanoid upper-body robot platform | Column-mounted humanoid upper-body robot platform | Column-mounted humanoid upper-body robot platform | Column-mounted humanoid upper-body robot platform | Column-mounted humanoid upper-body robot platform | Column-mounted humanoid upper-body robot platform | Column-mounted humanoid upper-body robot platform | Column-mounted humanoid upper-body robot platform | Column-mounted humanoid upper-body robot platform | Column-mounted humanoid upper-body robot platform | Column-mounted humanoid upper-body robot platform | Column-mounted humanoid upper-body robot platform | Column-mounted humanoid upper-body robot platform |
| Functional description | Configurable humanoid upper-body platform with height-adjustable column, offered with stationary rotating or mobile base. | Configurable humanoid upper-body platform with height-adjustable column, offered with stationary rotating or mobile base. | Configurable humanoid upper-body platform with height-adjustable column, offered with stationary rotating or mobile base. | Configurable humanoid upper-body platform with height-adjustable column, offered with stationary rotating or mobile base. | Configurable humanoid upper-body platform with height-adjustable column, offered with stationary rotating or mobile base. | Configurable humanoid upper-body platform with height-adjustable column, offered with stationary rotating or mobile base. | Configurable humanoid upper-body platform with height-adjustable column, offered with stationary rotating or mobile base. | Configurable humanoid upper-body platform with height-adjustable column, offered with stationary rotating or mobile base. | Configurable humanoid upper-body platform with height-adjustable column, offered with stationary rotating or mobile base. | Configurable humanoid upper-body platform with height-adjustable column, offered with stationary rotating or mobile base. | Configurable humanoid upper-body platform with height-adjustable column, offered with stationary rotating or mobile base. | Configurable humanoid upper-body platform with height-adjustable column, offered with stationary rotating or mobile base. | Configurable humanoid upper-body platform with height-adjustable column, offered with stationary rotating or mobile base. | Configurable humanoid upper-body platform with height-adjustable column, offered with stationary rotating or mobile base. | Configurable humanoid upper-body platform with height-adjustable column, offered with stationary rotating or mobile base. | Configurable humanoid upper-body platform with height-adjustable column, offered with stationary rotating or mobile base. | Configurable humanoid upper-body platform with height-adjustable column, offered with stationary rotating or mobile base. | Configurable humanoid upper-body platform with height-adjustable column, offered with stationary rotating or mobile base. | Configurable humanoid upper-body platform with height-adjustable column, offered with stationary rotating or mobile base. | Configurable humanoid upper-body platform with height-adjustable column, offered with stationary rotating or mobile base. | Configurable humanoid upper-body platform with height-adjustable column, offered with stationary rotating or mobile base. | Configurable humanoid upper-body platform with height-adjustable column, offered with stationary rotating or mobile base. | Configurable humanoid upper-body platform with height-adjustable column, offered with stationary rotating or mobile base. | Configurable humanoid upper-body platform with height-adjustable column, offered with stationary rotating or mobile base. | Configurable humanoid upper-body platform with height-adjustable column, offered with stationary rotating or mobile base. | Configurable humanoid upper-body platform with height-adjustable column, offered with stationary rotating or mobile base. |
| Includes functions of | – | H2-D Standard A | H2-D Standard A | H2-D Standard A | H2-D Standard A | H2-D Standard A | H2-D Standard A | H2-D Standard A | H2-D Standard A | H2-D Standard A | H2-D Standard A | H2-D Standard A | H2-D Standard A | – | H2-D Ultimate A | H2-D Ultimate A | H2-D Ultimate A | H2-D Ultimate A | H2-D Ultimate A | H2-D Ultimate A | H2-D Ultimate A | H2-D Ultimate A | H2-D Ultimate A | H2-D Ultimate A | H2-D Ultimate A | H2-D Ultimate A |
| Dimensions & Structure | ||||||||||||||||||||||||||
| Minimum height | 1 200 mm | 1 200 mm | 1 200 mm | 1 200 mm | 1 200 mm | 1 200 mm | 1 200 mm | 1 200 mm | 1 200 mm | 1 200 mm | 1 200 mm | 1 200 mm | 1 200 mm | 1 200 mm | 1 200 mm | 1 200 mm | 1 200 mm | 1 200 mm | 1 200 mm | 1 200 mm | 1 200 mm | 1 200 mm | 1 200 mm | 1 200 mm | 1 200 mm | 1 200 mm |
| Minimum width | 576 mm | 576 mm | 576 mm | 576 mm | 576 mm | 576 mm | 576 mm | 576 mm | 576 mm | 576 mm | 576 mm | 576 mm | 576 mm | 576 mm | 576 mm | 576 mm | 576 mm | 576 mm | 576 mm | 576 mm | 576 mm | 576 mm | 576 mm | 576 mm | 576 mm | 576 mm |
| Minimum depth | 620 mm | 620 mm | 620 mm | 620 mm | 620 mm | 620 mm | 620 mm | 620 mm | 620 mm | 620 mm | 620 mm | 620 mm | 620 mm | 620 mm | 620 mm | 620 mm | 620 mm | 620 mm | 620 mm | 620 mm | 620 mm | 620 mm | 620 mm | 620 mm | 620 mm | 620 mm |
| Maximum height | 1 700 mm | 1 700 mm | 1 700 mm | 1 700 mm | 1 700 mm | 1 700 mm | 1 700 mm | 1 700 mm | 1 700 mm | 1 700 mm | 1 700 mm | 1 700 mm | 1 700 mm | 1 700 mm | 1 700 mm | 1 700 mm | 1 700 mm | 1 700 mm | 1 700 mm | 1 700 mm | 1 700 mm | 1 700 mm | 1 700 mm | 1 700 mm | 1 700 mm | 1 700 mm |
| Maximum width | 576 mm | 576 mm | 576 mm | 576 mm | 576 mm | 576 mm | 576 mm | 576 mm | 576 mm | 576 mm | 576 mm | 576 mm | 576 mm | 576 mm | 576 mm | 576 mm | 576 mm | 576 mm | 576 mm | 576 mm | 576 mm | 576 mm | 576 mm | 576 mm | 576 mm | 576 mm |
| Maximum depth | 620 mm | 620 mm | 620 mm | 620 mm | 620 mm | 620 mm | 620 mm | 620 mm | 620 mm | 620 mm | 620 mm | 620 mm | 620 mm | 620 mm | 620 mm | 620 mm | 620 mm | 620 mm | 620 mm | 620 mm | 620 mm | 620 mm | 620 mm | 620 mm | 620 mm | 620 mm |
| Weight including battery | 135 kg | 135 kg | 135 kg | 135 kg | 135 kg | 135 kg | 135 kg | 135 kg | 135 kg | 135 kg | 135 kg | 135 kg | 135 kg | 135 kg | 135 kg | 135 kg | 135 kg | 135 kg | 135 kg | 135 kg | 135 kg | 135 kg | 135 kg | 135 kg | 135 kg | 135 kg |
| Degrees of Freedom | ||||||||||||||||||||||||||
| Total system DoF | 21 | 33 | 33 | 51 | 51 | 31 | 31 | 31 | 31 | 61 | 61 | 61 | 59 | 22 | 34 | 34 | 52 | 52 | 32 | 32 | 32 | 32 | 62 | 62 | 62 | 60 |
| Robot DoF excluding end effectors | 19 | 19 | 19 | 19 | 19 | 19 | 19 | 19 | 19 | 19 | 19 | 19 | 19 | 20 | 20 | 20 | 20 | 20 | 20 | 20 | 20 | 20 | 20 | 20 | 20 | 20 |
| Single arm DoF | 7 | 7 | 7 | 7 | 7 | 7 | 7 | 7 | 7 | 7 | 7 | 7 | 7 | 7 | 7 | 7 | 7 | 7 | 7 | 7 | 7 | 7 | 7 | 7 | 7 | 7 |
| Waist DoF | 1 | 1 | 1 | 1 | 1 | 1 | 1 | 1 | 1 | 1 | 1 | 1 | 1 | 1 | 1 | 1 | 1 | 1 | 1 | 1 | 1 | 1 | 1 | 1 | 1 | 1 |
| Head DoF | 2 | 2 | 2 | 2 | 2 | 2 | 2 | 2 | 2 | 2 | 2 | 2 | 2 | 2 | 2 | 2 | 2 | 2 | 2 | 2 | 2 | 2 | 2 | 2 | 2 | 2 |
| Column DoF | 2 | 2 | 2 | 2 | 2 | 2 | 2 | 2 | 2 | 2 | 2 | 2 | 2 | 1 | 1 | 1 | 1 | 1 | 1 | 1 | 1 | 1 | 1 | 1 | 1 | 1 |
| Mobile base DoF | – | – | – | – | – | – | – | – | – | – | – | – | – | 2 | 2 | 2 | 2 | 2 | 2 | 2 | 2 | 2 | 2 | 2 | 2 | 2 |
| Single hand/end-effector DoF | 1 | 7 | 7 | 16 | 16 | 6 | 6 | 6 | 6 | 21 | 21 | 21 | 20 | 1 | 7 | 7 | 16 | 16 | 6 | 6 | 6 | 6 | 21 | 21 | 21 | 20 |
| Single hand joint count | – | – | – | 16 | 16 | 11 | 11 | 12 | 12 | – | – | – | – | – | – | – | 16 | 16 | 11 | 11 | 12 | 12 | – | – | – | – |
| Performance | ||||||||||||||||||||||||||
| Peak arm payload | 7 kg | 7 kg | 7 kg | 7 kg | 7 kg | 7 kg | 7 kg | 7 kg | 7 kg | 7 kg | 7 kg | 7 kg | 7 kg | 7 kg | 7 kg | 7 kg | 7 kg | 7 kg | 7 kg | 7 kg | 7 kg | 7 kg | 7 kg | 7 kg | 7 kg | 7 kg |
| Single arm reach | 620 mm | 620 mm | 620 mm | 620 mm | 620 mm | 620 mm | 620 mm | 620 mm | 620 mm | 620 mm | 620 mm | 620 mm | 620 mm | 620 mm | 620 mm | 620 mm | 620 mm | 620 mm | 620 mm | 620 mm | 620 mm | 620 mm | 620 mm | 620 mm | 620 mm | 620 mm |
| Waist joint range | Pitch 0–115° | Pitch 0–115° | Pitch 0–115° | Pitch 0–115° | Pitch 0–115° | Pitch 0–115° | Pitch 0–115° | Pitch 0–115° | Pitch 0–115° | Pitch 0–115° | Pitch 0–115° | Pitch 0–115° | Pitch 0–115° | Pitch 0–115° | Pitch 0–115° | Pitch 0–115° | Pitch 0–115° | Pitch 0–115° | Pitch 0–115° | Pitch 0–115° | Pitch 0–115° | Pitch 0–115° | Pitch 0–115° | Pitch 0–115° | Pitch 0–115° | Pitch 0–115° |
| Lift stroke | 500 mm | 500 mm | 500 mm | 500 mm | 500 mm | 500 mm | 500 mm | 500 mm | 500 mm | 500 mm | 500 mm | 500 mm | 500 mm | 500 mm | 500 mm | 500 mm | 500 mm | 500 mm | 500 mm | 500 mm | 500 mm | 500 mm | 500 mm | 500 mm | 500 mm | 500 mm |
| Maximum lift speed | 200 mm/s | 200 mm/s | 200 mm/s | 200 mm/s | 200 mm/s | 200 mm/s | 200 mm/s | 200 mm/s | 200 mm/s | 200 mm/s | 200 mm/s | 200 mm/s | 200 mm/s | 200 mm/s | 200 mm/s | 200 mm/s | 200 mm/s | 200 mm/s | 200 mm/s | 200 mm/s | 200 mm/s | 200 mm/s | 200 mm/s | 200 mm/s | 200 mm/s | 200 mm/s |
| Mobile Base | ||||||||||||||||||||||||||
| Base type | Stationary base with lift and rotating column | Stationary base with lift and rotating column | Stationary base with lift and rotating column | Stationary base with lift and rotating column | Stationary base with lift and rotating column | Stationary base with lift and rotating column | Stationary base with lift and rotating column | Stationary base with lift and rotating column | Stationary base with lift and rotating column | Stationary base with lift and rotating column | Stationary base with lift and rotating column | Stationary base with lift and rotating column | Stationary base with lift and rotating column | Mobile differential-drive base | Mobile differential-drive base | Mobile differential-drive base | Mobile differential-drive base | Mobile differential-drive base | Mobile differential-drive base | Mobile differential-drive base | Mobile differential-drive base | Mobile differential-drive base | Mobile differential-drive base | Mobile differential-drive base | Mobile differential-drive base | Mobile differential-drive base |
| Drive system | No autonomous travel; supports Z-axis rotation in place | No autonomous travel; supports Z-axis rotation in place | No autonomous travel; supports Z-axis rotation in place | No autonomous travel; supports Z-axis rotation in place | No autonomous travel; supports Z-axis rotation in place | No autonomous travel; supports Z-axis rotation in place | No autonomous travel; supports Z-axis rotation in place | No autonomous travel; supports Z-axis rotation in place | No autonomous travel; supports Z-axis rotation in place | No autonomous travel; supports Z-axis rotation in place | No autonomous travel; supports Z-axis rotation in place | No autonomous travel; supports Z-axis rotation in place | No autonomous travel; supports Z-axis rotation in place | Servo-motor differential drive | Servo-motor differential drive | Servo-motor differential drive | Servo-motor differential drive | Servo-motor differential drive | Servo-motor differential drive | Servo-motor differential drive | Servo-motor differential drive | Servo-motor differential drive | Servo-motor differential drive | Servo-motor differential drive | Servo-motor differential drive | Servo-motor differential drive |
| Maximum base speed | – | – | – | – | – | – | – | – | – | – | – | – | – | 1,50 m/s | 1,50 m/s | 1,50 m/s | 1,50 m/s | 1,50 m/s | 1,50 m/s | 1,50 m/s | 1,50 m/s | 1,50 m/s | 1,50 m/s | 1,50 m/s | 1,50 m/s | 1,50 m/s |
| Autonomous base movement | No | No | No | No | No | No | No | No | No | No | No | No | No | – | – | – | – | – | – | – | – | – | – | – | – | – |
| In-place rotation | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes |
| Rotation diameter | – | – | – | – | – | – | – | – | – | – | – | – | – | 0,75 m | 0,75 m | 0,75 m | 0,75 m | 0,75 m | 0,75 m | 0,75 m | 0,75 m | 0,75 m | 0,75 m | 0,75 m | 0,75 m | 0,75 m |
| Base / column rotation range | ±90° left/right | ±90° left/right | ±90° left/right | ±90° left/right | ±90° left/right | ±90° left/right | ±90° left/right | ±90° left/right | ±90° left/right | ±90° left/right | ±90° left/right | ±90° left/right | ±90° left/right | 360° | 360° | 360° | 360° | 360° | 360° | 360° | 360° | 360° | 360° | 360° | 360° | 360° |
| LiDAR units | – | – | – | – | – | – | – | – | – | – | – | – | – | 1 | 1 | 1 | 1 | 1 | 1 | 1 | 1 | 1 | 1 | 1 | 1 | 1 |
| Base depth cameras | – | – | – | – | – | – | – | – | – | – | – | – | – | 1 | 1 | 1 | 1 | 1 | 1 | 1 | 1 | 1 | 1 | 1 | 1 | 1 |
| Physical collision sensors | – | – | – | – | – | – | – | – | – | – | – | – | – | 2 | 2 | 2 | 2 | 2 | 2 | 2 | 2 | 2 | 2 | 2 | 2 | 2 |
| Ultrasonic sensors | – | – | – | – | – | – | – | – | – | – | – | – | – | 2 | 2 | 2 | 2 | 2 | 2 | 2 | 2 | 2 | 2 | 2 | 2 | 2 |
| Battery & Power | ||||||||||||||||||||||||||
| Power supply methods | External power supply; two swappable base batteries store regenerative/back-EMF energy | External power supply; two swappable base batteries store regenerative/back-EMF energy | External power supply; two swappable base batteries store regenerative/back-EMF energy | External power supply; two swappable base batteries store regenerative/back-EMF energy | External power supply; two swappable base batteries store regenerative/back-EMF energy | External power supply; two swappable base batteries store regenerative/back-EMF energy | External power supply; two swappable base batteries store regenerative/back-EMF energy | External power supply; two swappable base batteries store regenerative/back-EMF energy | External power supply; two swappable base batteries store regenerative/back-EMF energy | External power supply; two swappable base batteries store regenerative/back-EMF energy | External power supply; two swappable base batteries store regenerative/back-EMF energy | External power supply; two swappable base batteries store regenerative/back-EMF energy | External power supply; two swappable base batteries store regenerative/back-EMF energy | Removable internal base battery, charging pile or external power supply | Removable internal base battery, charging pile or external power supply | Removable internal base battery, charging pile or external power supply | Removable internal base battery, charging pile or external power supply | Removable internal base battery, charging pile or external power supply | Removable internal base battery, charging pile or external power supply | Removable internal base battery, charging pile or external power supply | Removable internal base battery, charging pile or external power supply | Removable internal base battery, charging pile or external power supply | Removable internal base battery, charging pile or external power supply | Removable internal base battery, charging pile or external power supply | Removable internal base battery, charging pile or external power supply | Removable internal base battery, charging pile or external power supply |
| Battery type | Two swappable base energy-storage batteries | Two swappable base energy-storage batteries | Two swappable base energy-storage batteries | Two swappable base energy-storage batteries | Two swappable base energy-storage batteries | Two swappable base energy-storage batteries | Two swappable base energy-storage batteries | Two swappable base energy-storage batteries | Two swappable base energy-storage batteries | Two swappable base energy-storage batteries | Two swappable base energy-storage batteries | Two swappable base energy-storage batteries | Two swappable base energy-storage batteries | Removable internal base battery | Removable internal base battery | Removable internal base battery | Removable internal base battery | Removable internal base battery | Removable internal base battery | Removable internal base battery | Removable internal base battery | Removable internal base battery | Removable internal base battery | Removable internal base battery | Removable internal base battery | Removable internal base battery |
| Battery voltage | – | – | – | – | – | – | – | – | – | – | – | – | – | 48 V | 48 V | 48 V | 48 V | 48 V | 48 V | 48 V | 48 V | 48 V | 48 V | 48 V | 48 V | 48 V |
| Battery capacity | – | – | – | – | – | – | – | – | – | – | – | – | – | 30 Ah | 30 Ah | 30 Ah | 30 Ah | 30 Ah | 30 Ah | 30 Ah | 30 Ah | 30 Ah | 30 Ah | 30 Ah | 30 Ah | 30 Ah |
| Battery energy | – | – | – | – | – | – | – | – | – | – | – | – | – | 1,44 kWh | 1,44 kWh | 1,44 kWh | 1,44 kWh | 1,44 kWh | 1,44 kWh | 1,44 kWh | 1,44 kWh | 1,44 kWh | 1,44 kWh | 1,44 kWh | 1,44 kWh | 1,44 kWh |
| Battery endurance | – | – | – | – | – | – | – | – | – | – | – | – | – | 5 hours | 5 hours | 5 hours | 5 hours | 5 hours | 5 hours | 5 hours | 5 hours | 5 hours | 5 hours | 5 hours | 5 hours | 5 hours |
| Base battery count | 2 | 2 | 2 | 2 | 2 | 2 | 2 | 2 | 2 | 2 | 2 | 2 | 2 | 1 | 1 | 1 | 1 | 1 | 1 | 1 | 1 | 1 | 1 | 1 | 1 | 1 |
| Swappable battery | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes |
| Automatic recharge supported | – | – | – | – | – | – | – | – | – | – | – | – | – | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes |
| Charging pile kit included | – | – | – | – | – | – | – | – | – | – | – | – | – | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes |
| Continuous external power supported | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes |
| Power notes | The upper body cannot hold batteries. Base batteries are for regenerative/back-EMF energy storage and provide only short-duration operation. Supports direct continuous charging for 7 × 24-hour operation. | The upper body cannot hold batteries. Base batteries are for regenerative/back-EMF energy storage and provide only short-duration operation. Supports direct continuous charging for 7 × 24-hour operation. | The upper body cannot hold batteries. Base batteries are for regenerative/back-EMF energy storage and provide only short-duration operation. Supports direct continuous charging for 7 × 24-hour operation. | The upper body cannot hold batteries. Base batteries are for regenerative/back-EMF energy storage and provide only short-duration operation. Supports direct continuous charging for 7 × 24-hour operation. | The upper body cannot hold batteries. Base batteries are for regenerative/back-EMF energy storage and provide only short-duration operation. Supports direct continuous charging for 7 × 24-hour operation. | The upper body cannot hold batteries. Base batteries are for regenerative/back-EMF energy storage and provide only short-duration operation. Supports direct continuous charging for 7 × 24-hour operation. | The upper body cannot hold batteries. Base batteries are for regenerative/back-EMF energy storage and provide only short-duration operation. Supports direct continuous charging for 7 × 24-hour operation. | The upper body cannot hold batteries. Base batteries are for regenerative/back-EMF energy storage and provide only short-duration operation. Supports direct continuous charging for 7 × 24-hour operation. | The upper body cannot hold batteries. Base batteries are for regenerative/back-EMF energy storage and provide only short-duration operation. Supports direct continuous charging for 7 × 24-hour operation. | The upper body cannot hold batteries. Base batteries are for regenerative/back-EMF energy storage and provide only short-duration operation. Supports direct continuous charging for 7 × 24-hour operation. | The upper body cannot hold batteries. Base batteries are for regenerative/back-EMF energy storage and provide only short-duration operation. Supports direct continuous charging for 7 × 24-hour operation. | The upper body cannot hold batteries. Base batteries are for regenerative/back-EMF energy storage and provide only short-duration operation. Supports direct continuous charging for 7 × 24-hour operation. | The upper body cannot hold batteries. Base batteries are for regenerative/back-EMF energy storage and provide only short-duration operation. Supports direct continuous charging for 7 × 24-hour operation. | Upper body cannot hold batteries. Supports battery replacement and automatic recharge; charging pile kit and external power supply are included. | Upper body cannot hold batteries. Supports battery replacement and automatic recharge; charging pile kit and external power supply are included. | Upper body cannot hold batteries. Supports battery replacement and automatic recharge; charging pile kit and external power supply are included. | Upper body cannot hold batteries. Supports battery replacement and automatic recharge; charging pile kit and external power supply are included. | Upper body cannot hold batteries. Supports battery replacement and automatic recharge; charging pile kit and external power supply are included. | Upper body cannot hold batteries. Supports battery replacement and automatic recharge; charging pile kit and external power supply are included. | Upper body cannot hold batteries. Supports battery replacement and automatic recharge; charging pile kit and external power supply are included. | Upper body cannot hold batteries. Supports battery replacement and automatic recharge; charging pile kit and external power supply are included. | Upper body cannot hold batteries. Supports battery replacement and automatic recharge; charging pile kit and external power supply are included. | Upper body cannot hold batteries. Supports battery replacement and automatic recharge; charging pile kit and external power supply are included. | Upper body cannot hold batteries. Supports battery replacement and automatic recharge; charging pile kit and external power supply are included. | Upper body cannot hold batteries. Supports battery replacement and automatic recharge; charging pile kit and external power supply are included. | Upper body cannot hold batteries. Supports battery replacement and automatic recharge; charging pile kit and external power supply are included. |
| Compute, Control & Software | ||||||||||||||||||||||||||
| PC1 / platform computer | Intel Core i5 platform computer | Intel Core i5 platform computer | Intel Core i5 platform computer | Intel Core i5 platform computer | Intel Core i5 platform computer | Intel Core i5 platform computer | Intel Core i5 platform computer | Intel Core i5 platform computer | Intel Core i5 platform computer | Intel Core i5 platform computer | Intel Core i5 platform computer | Intel Core i5 platform computer | Intel Core i5 platform computer | Intel Core i5 platform computer | Intel Core i5 platform computer | Intel Core i5 platform computer | Intel Core i5 platform computer | Intel Core i5 platform computer | Intel Core i5 platform computer | Intel Core i5 platform computer | Intel Core i5 platform computer | Intel Core i5 platform computer | Intel Core i5 platform computer | Intel Core i5 platform computer | Intel Core i5 platform computer | Intel Core i5 platform computer |
| PC2 / user-development computer | Intel Core i7 user-development computer | Intel Core i7 user-development computer | Intel Core i7 user-development computer | Intel Core i7 user-development computer | Intel Core i7 user-development computer | Intel Core i7 user-development computer | Intel Core i7 user-development computer | Intel Core i7 user-development computer | Intel Core i7 user-development computer | Intel Core i7 user-development computer | Intel Core i7 user-development computer | Intel Core i7 user-development computer | Intel Core i7 user-development computer | Intel Core i7 user-development computer | Intel Core i7 user-development computer | Intel Core i7 user-development computer | Intel Core i7 user-development computer | Intel Core i7 user-development computer | Intel Core i7 user-development computer | Intel Core i7 user-development computer | Intel Core i7 user-development computer | Intel Core i7 user-development computer | Intel Core i7 user-development computer | Intel Core i7 user-development computer | Intel Core i7 user-development computer | Intel Core i7 user-development computer |
| PC3 / optional high-compute module | Empty slot; optional NVIDIA Jetson Thor × 1 | Empty slot; optional NVIDIA Jetson Thor × 1 | Empty slot; optional NVIDIA Jetson Thor × 1 | Empty slot; optional NVIDIA Jetson Thor × 1 | Empty slot; optional NVIDIA Jetson Thor × 1 | Empty slot; optional NVIDIA Jetson Thor × 1 | Empty slot; optional NVIDIA Jetson Thor × 1 | Empty slot; optional NVIDIA Jetson Thor × 1 | Empty slot; optional NVIDIA Jetson Thor × 1 | Empty slot; optional NVIDIA Jetson Thor × 1 | Empty slot; optional NVIDIA Jetson Thor × 1 | Empty slot; optional NVIDIA Jetson Thor × 1 | Empty slot; optional NVIDIA Jetson Thor × 1 | Empty slot; optional NVIDIA Jetson Thor × 1 | Empty slot; optional NVIDIA Jetson Thor × 1 | Empty slot; optional NVIDIA Jetson Thor × 1 | Empty slot; optional NVIDIA Jetson Thor × 1 | Empty slot; optional NVIDIA Jetson Thor × 1 | Empty slot; optional NVIDIA Jetson Thor × 1 | Empty slot; optional NVIDIA Jetson Thor × 1 | Empty slot; optional NVIDIA Jetson Thor × 1 | Empty slot; optional NVIDIA Jetson Thor × 1 | Empty slot; optional NVIDIA Jetson Thor × 1 | Empty slot; optional NVIDIA Jetson Thor × 1 | Empty slot; optional NVIDIA Jetson Thor × 1 | Empty slot; optional NVIDIA Jetson Thor × 1 |
| PC4 / optional module | Empty slot; optional Intel Core i7 × 1 or NVIDIA Jetson Orin NX × 1 | Empty slot; optional Intel Core i7 × 1 or NVIDIA Jetson Orin NX × 1 | Empty slot; optional Intel Core i7 × 1 or NVIDIA Jetson Orin NX × 1 | Empty slot; optional Intel Core i7 × 1 or NVIDIA Jetson Orin NX × 1 | Empty slot; optional Intel Core i7 × 1 or NVIDIA Jetson Orin NX × 1 | Empty slot; optional Intel Core i7 × 1 or NVIDIA Jetson Orin NX × 1 | Empty slot; optional Intel Core i7 × 1 or NVIDIA Jetson Orin NX × 1 | Empty slot; optional Intel Core i7 × 1 or NVIDIA Jetson Orin NX × 1 | Empty slot; optional Intel Core i7 × 1 or NVIDIA Jetson Orin NX × 1 | Empty slot; optional Intel Core i7 × 1 or NVIDIA Jetson Orin NX × 1 | Empty slot; optional Intel Core i7 × 1 or NVIDIA Jetson Orin NX × 1 | Empty slot; optional Intel Core i7 × 1 or NVIDIA Jetson Orin NX × 1 | Empty slot; optional Intel Core i7 × 1 or NVIDIA Jetson Orin NX × 1 | Empty slot; optional Intel Core i7 × 1 or NVIDIA Jetson Orin NX × 1 | Empty slot; optional Intel Core i7 × 1 or NVIDIA Jetson Orin NX × 1 | Empty slot; optional Intel Core i7 × 1 or NVIDIA Jetson Orin NX × 1 | Empty slot; optional Intel Core i7 × 1 or NVIDIA Jetson Orin NX × 1 | Empty slot; optional Intel Core i7 × 1 or NVIDIA Jetson Orin NX × 1 | Empty slot; optional Intel Core i7 × 1 or NVIDIA Jetson Orin NX × 1 | Empty slot; optional Intel Core i7 × 1 or NVIDIA Jetson Orin NX × 1 | Empty slot; optional Intel Core i7 × 1 or NVIDIA Jetson Orin NX × 1 | Empty slot; optional Intel Core i7 × 1 or NVIDIA Jetson Orin NX × 1 | Empty slot; optional Intel Core i7 × 1 or NVIDIA Jetson Orin NX × 1 | Empty slot; optional Intel Core i7 × 1 or NVIDIA Jetson Orin NX × 1 | Empty slot; optional Intel Core i7 × 1 or NVIDIA Jetson Orin NX × 1 | Empty slot; optional Intel Core i7 × 1 or NVIDIA Jetson Orin NX × 1 |
| Optional computing performance | NVIDIA Jetson Thor: 2070 TOPS; NVIDIA Jetson Orin NX: 100 TOPS | NVIDIA Jetson Thor: 2070 TOPS; NVIDIA Jetson Orin NX: 100 TOPS | NVIDIA Jetson Thor: 2070 TOPS; NVIDIA Jetson Orin NX: 100 TOPS | NVIDIA Jetson Thor: 2070 TOPS; NVIDIA Jetson Orin NX: 100 TOPS | NVIDIA Jetson Thor: 2070 TOPS; NVIDIA Jetson Orin NX: 100 TOPS | NVIDIA Jetson Thor: 2070 TOPS; NVIDIA Jetson Orin NX: 100 TOPS | NVIDIA Jetson Thor: 2070 TOPS; NVIDIA Jetson Orin NX: 100 TOPS | NVIDIA Jetson Thor: 2070 TOPS; NVIDIA Jetson Orin NX: 100 TOPS | NVIDIA Jetson Thor: 2070 TOPS; NVIDIA Jetson Orin NX: 100 TOPS | NVIDIA Jetson Thor: 2070 TOPS; NVIDIA Jetson Orin NX: 100 TOPS | NVIDIA Jetson Thor: 2070 TOPS; NVIDIA Jetson Orin NX: 100 TOPS | NVIDIA Jetson Thor: 2070 TOPS; NVIDIA Jetson Orin NX: 100 TOPS | NVIDIA Jetson Thor: 2070 TOPS; NVIDIA Jetson Orin NX: 100 TOPS | NVIDIA Jetson Thor: 2070 TOPS; NVIDIA Jetson Orin NX: 100 TOPS | NVIDIA Jetson Thor: 2070 TOPS; NVIDIA Jetson Orin NX: 100 TOPS | NVIDIA Jetson Thor: 2070 TOPS; NVIDIA Jetson Orin NX: 100 TOPS | NVIDIA Jetson Thor: 2070 TOPS; NVIDIA Jetson Orin NX: 100 TOPS | NVIDIA Jetson Thor: 2070 TOPS; NVIDIA Jetson Orin NX: 100 TOPS | NVIDIA Jetson Thor: 2070 TOPS; NVIDIA Jetson Orin NX: 100 TOPS | NVIDIA Jetson Thor: 2070 TOPS; NVIDIA Jetson Orin NX: 100 TOPS | NVIDIA Jetson Thor: 2070 TOPS; NVIDIA Jetson Orin NX: 100 TOPS | NVIDIA Jetson Thor: 2070 TOPS; NVIDIA Jetson Orin NX: 100 TOPS | NVIDIA Jetson Thor: 2070 TOPS; NVIDIA Jetson Orin NX: 100 TOPS | NVIDIA Jetson Thor: 2070 TOPS; NVIDIA Jetson Orin NX: 100 TOPS | NVIDIA Jetson Thor: 2070 TOPS; NVIDIA Jetson Orin NX: 100 TOPS | NVIDIA Jetson Thor: 2070 TOPS; NVIDIA Jetson Orin NX: 100 TOPS |
| Control | Handheld remote controller included | Handheld remote controller included | Handheld remote controller included | Handheld remote controller included | Handheld remote controller included | Handheld remote controller included | Handheld remote controller included | Handheld remote controller included | Handheld remote controller included | Handheld remote controller included | Handheld remote controller included | Handheld remote controller included | Handheld remote controller included | Handheld remote controller included | Handheld remote controller included | Handheld remote controller included | Handheld remote controller included | Handheld remote controller included | Handheld remote controller included | Handheld remote controller included | Handheld remote controller included | Handheld remote controller included | Handheld remote controller included | Handheld remote controller included | Handheld remote controller included | Handheld remote controller included |
| Smart OTA updates | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes |
| Secondary development support | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes |
| Visualization PC included | – | – | – | – | – | – | – | – | – | – | – | – | – | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes |
| Perception & Connectivity | ||||||||||||||||||||||||||
| Perception sensors | Wide-field-of-view humanoid binocular head camera and two HD wrist cameras | Wide-field-of-view humanoid binocular head camera and two HD wrist cameras | Wide-field-of-view humanoid binocular head camera and two HD wrist cameras | Wide-field-of-view humanoid binocular head camera and two HD wrist cameras | Wide-field-of-view humanoid binocular head camera and two HD wrist cameras | Wide-field-of-view humanoid binocular head camera and two HD wrist cameras | Wide-field-of-view humanoid binocular head camera and two HD wrist cameras | Wide-field-of-view humanoid binocular head camera and two HD wrist cameras | Wide-field-of-view humanoid binocular head camera and two HD wrist cameras | Wide-field-of-view humanoid binocular head camera and two HD wrist cameras | Wide-field-of-view humanoid binocular head camera and two HD wrist cameras | Wide-field-of-view humanoid binocular head camera and two HD wrist cameras | Wide-field-of-view humanoid binocular head camera and two HD wrist cameras | Wide-FOV humanoid binocular head camera; two HD wrist cameras; 1 LiDAR; 1 base depth camera; 2 physical collision sensors; 2 ultrasonic sensors | Wide-FOV humanoid binocular head camera; two HD wrist cameras; 1 LiDAR; 1 base depth camera; 2 physical collision sensors; 2 ultrasonic sensors | Wide-FOV humanoid binocular head camera; two HD wrist cameras; 1 LiDAR; 1 base depth camera; 2 physical collision sensors; 2 ultrasonic sensors | Wide-FOV humanoid binocular head camera; two HD wrist cameras; 1 LiDAR; 1 base depth camera; 2 physical collision sensors; 2 ultrasonic sensors | Wide-FOV humanoid binocular head camera; two HD wrist cameras; 1 LiDAR; 1 base depth camera; 2 physical collision sensors; 2 ultrasonic sensors | Wide-FOV humanoid binocular head camera; two HD wrist cameras; 1 LiDAR; 1 base depth camera; 2 physical collision sensors; 2 ultrasonic sensors | Wide-FOV humanoid binocular head camera; two HD wrist cameras; 1 LiDAR; 1 base depth camera; 2 physical collision sensors; 2 ultrasonic sensors | Wide-FOV humanoid binocular head camera; two HD wrist cameras; 1 LiDAR; 1 base depth camera; 2 physical collision sensors; 2 ultrasonic sensors | Wide-FOV humanoid binocular head camera; two HD wrist cameras; 1 LiDAR; 1 base depth camera; 2 physical collision sensors; 2 ultrasonic sensors | Wide-FOV humanoid binocular head camera; two HD wrist cameras; 1 LiDAR; 1 base depth camera; 2 physical collision sensors; 2 ultrasonic sensors | Wide-FOV humanoid binocular head camera; two HD wrist cameras; 1 LiDAR; 1 base depth camera; 2 physical collision sensors; 2 ultrasonic sensors | Wide-FOV humanoid binocular head camera; two HD wrist cameras; 1 LiDAR; 1 base depth camera; 2 physical collision sensors; 2 ultrasonic sensors | Wide-FOV humanoid binocular head camera; two HD wrist cameras; 1 LiDAR; 1 base depth camera; 2 physical collision sensors; 2 ultrasonic sensors |
| Head camera | Wide-FOV humanoid binocular camera × 1 | Wide-FOV humanoid binocular camera × 1 | Wide-FOV humanoid binocular camera × 1 | Wide-FOV humanoid binocular camera × 1 | Wide-FOV humanoid binocular camera × 1 | Wide-FOV humanoid binocular camera × 1 | Wide-FOV humanoid binocular camera × 1 | Wide-FOV humanoid binocular camera × 1 | Wide-FOV humanoid binocular camera × 1 | Wide-FOV humanoid binocular camera × 1 | Wide-FOV humanoid binocular camera × 1 | Wide-FOV humanoid binocular camera × 1 | Wide-FOV humanoid binocular camera × 1 | Wide-FOV humanoid binocular camera × 1 | Wide-FOV humanoid binocular camera × 1 | Wide-FOV humanoid binocular camera × 1 | Wide-FOV humanoid binocular camera × 1 | Wide-FOV humanoid binocular camera × 1 | Wide-FOV humanoid binocular camera × 1 | Wide-FOV humanoid binocular camera × 1 | Wide-FOV humanoid binocular camera × 1 | Wide-FOV humanoid binocular camera × 1 | Wide-FOV humanoid binocular camera × 1 | Wide-FOV humanoid binocular camera × 1 | Wide-FOV humanoid binocular camera × 1 | Wide-FOV humanoid binocular camera × 1 |
| Wrist cameras | HD wrist cameras × 2 | HD wrist cameras × 2 | HD wrist cameras × 2 | HD wrist cameras × 2 | HD wrist cameras × 2 | HD wrist cameras × 2 | HD wrist cameras × 2 | HD wrist cameras × 2 | HD wrist cameras × 2 | HD wrist cameras × 2 | HD wrist cameras × 2 | HD wrist cameras × 2 | HD wrist cameras × 2 | HD wrist cameras × 2 | HD wrist cameras × 2 | HD wrist cameras × 2 | HD wrist cameras × 2 | HD wrist cameras × 2 | HD wrist cameras × 2 | HD wrist cameras × 2 | HD wrist cameras × 2 | HD wrist cameras × 2 | HD wrist cameras × 2 | HD wrist cameras × 2 | HD wrist cameras × 2 | HD wrist cameras × 2 |
| Wrist camera FOV | D 130° / H 120° / V 81° | D 130° / H 120° / V 81° | D 130° / H 120° / V 81° | D 130° / H 120° / V 81° | D 130° / H 120° / V 81° | D 130° / H 120° / V 81° | D 130° / H 120° / V 81° | D 130° / H 120° / V 81° | D 130° / H 120° / V 81° | D 130° / H 120° / V 81° | D 130° / H 120° / V 81° | D 130° / H 120° / V 81° | D 130° / H 120° / V 81° | D 130° / H 120° / V 81° | D 130° / H 120° / V 81° | D 130° / H 120° / V 81° | D 130° / H 120° / V 81° | D 130° / H 120° / V 81° | D 130° / H 120° / V 81° | D 130° / H 120° / V 81° | D 130° / H 120° / V 81° | D 130° / H 120° / V 81° | D 130° / H 120° / V 81° | D 130° / H 120° / V 81° | D 130° / H 120° / V 81° | D 130° / H 120° / V 81° |
| Wrist camera resolution | 1920 × 1080 | 1920 × 1080 | 1920 × 1080 | 1920 × 1080 | 1920 × 1080 | 1920 × 1080 | 1920 × 1080 | 1920 × 1080 | 1920 × 1080 | 1920 × 1080 | 1920 × 1080 | 1920 × 1080 | 1920 × 1080 | 1920 × 1080 | 1920 × 1080 | 1920 × 1080 | 1920 × 1080 | 1920 × 1080 | 1920 × 1080 | 1920 × 1080 | 1920 × 1080 | 1920 × 1080 | 1920 × 1080 | 1920 × 1080 | 1920 × 1080 | 1920 × 1080 |
| Wi-Fi | Wi-Fi 6 | Wi-Fi 6 | Wi-Fi 6 | Wi-Fi 6 | Wi-Fi 6 | Wi-Fi 6 | Wi-Fi 6 | Wi-Fi 6 | Wi-Fi 6 | Wi-Fi 6 | Wi-Fi 6 | Wi-Fi 6 | Wi-Fi 6 | Wi-Fi 6 | Wi-Fi 6 | Wi-Fi 6 | Wi-Fi 6 | Wi-Fi 6 | Wi-Fi 6 | Wi-Fi 6 | Wi-Fi 6 | Wi-Fi 6 | Wi-Fi 6 | Wi-Fi 6 | Wi-Fi 6 | Wi-Fi 6 |
| Bluetooth | Bluetooth 5.2 | Bluetooth 5.2 | Bluetooth 5.2 | Bluetooth 5.2 | Bluetooth 5.2 | Bluetooth 5.2 | Bluetooth 5.2 | Bluetooth 5.2 | Bluetooth 5.2 | Bluetooth 5.2 | Bluetooth 5.2 | Bluetooth 5.2 | Bluetooth 5.2 | Bluetooth 5.2 | Bluetooth 5.2 | Bluetooth 5.2 | Bluetooth 5.2 | Bluetooth 5.2 | Bluetooth 5.2 | Bluetooth 5.2 | Bluetooth 5.2 | Bluetooth 5.2 | Bluetooth 5.2 | Bluetooth 5.2 | Bluetooth 5.2 | Bluetooth 5.2 |
| Hand / End Effector | ||||||||||||||||||||||||||
| Hand / end-effector model | Dex1-1 Standard grippers × 2 | Dex3-1 force-controlled three-finger dexterous hands, non-tactile × 2 | Dex3-1 force-controlled three-finger dexterous hands, tactile × 2 | Dex5-1 force-controlled dexterous hands, non-tactile × 2 | Dex5-1P force-controlled dexterous hands, tactile × 2 | BrainCo Revo2 Basic bionic dexterous hands × 2 | BrainCo Revo2 Touch tactile bionic dexterous hands × 2 | Inspire DFQ dexterous hands, non-tactile × 2 | Inspire E2 dexterous hands, tactile × 2 | BrainCo Revo3 U21 dexterous hands, non-tactile × 2 | BrainCo Revo3 U21T tactile dexterous hands × 2 | BrainCo Revo3 U21VT visual-tactile dexterous hands × 2 | Wuji Hand 2 dexterous hands, non-tactile × 2 | Dex1-1 Advanced Version grippers × 2 | Dex3-1 force-controlled three-finger dexterous hands, non-tactile × 2 | Dex3-1 force-controlled three-finger dexterous hands, tactile × 2 | Dex5-1 force-controlled dexterous hands, non-tactile × 2 | Dex5-1P force-controlled dexterous hands, tactile × 2 | BrainCo Revo2 Basic bionic dexterous hands × 2 | BrainCo Revo2 Touch tactile bionic dexterous hands × 2 | Inspire DFQ dexterous hands, non-tactile × 2 | Inspire E2 dexterous hands, tactile × 2 | BrainCo Revo3 U21 dexterous hands, non-tactile × 2 | BrainCo Revo3 U21T tactile dexterous hands × 2 | BrainCo Revo3 U21VT visual-tactile dexterous hands × 2 | Wuji Hand 2 dexterous hands, non-tactile × 2 |
| Tactile sensing | No | No | Yes | No | Yes | No | Yes | No | Yes | No | Yes | Yes | No | No | No | Yes | No | Yes | No | Yes | No | Yes | No | Yes | Yes | No |
| Single hand/end-effector weight | 550 g | 650 g | 650 g | – | – | 383 g | 383 g | – | 800 g | – | – | – | – | – | 650 g | 650 g | – | – | 383 g | 383 g | – | 800 g | – | – | – | – |
| Hand/end-effector dimensions | 143 × 78 × 67 | 175 × 88 × 77 | 175 × 88 × 77 | – | – | – | – | – | – | 215 × 105 × 50 | 215 × 105 × 50 | 215 × 105 × 50 | Approximately 185 × 80 × 40 | – | 175 × 88 × 77 | 175 × 88 × 77 | – | – | – | – | – | – | 215 × 105 × 50 | 215 × 105 × 50 | 215 × 105 × 50 | Approximately 185 × 80 × 40 |
| Hand height | – | – | – | – | – | 160 mm | 160 mm | – | – | – | – | – | – | – | – | – | – | – | 160 mm | 160 mm | – | – | – | – | – | – |
| Operating voltage | – | 12–58 V | 12–58 V | 24–60 V DC | 24–60 V DC | – | – | – | 24 V ±10% | 12–80 V | 12–80 V | 12–80 V | 16–58 V DC | – | 12–58 V | 12–58 V | 24–60 V DC | 24–60 V DC | – | – | – | 24 V ±10% | 12–80 V | 12–80 V | 12–80 V | 16–58 V DC |
| Static current | – | 0.2 A at 58 V | 0.2 A at 58 V | 0.2 A at 58 V | 0.2 A at 58 V | – | – | – | 0.25 A | – | – | – | – | – | 0.2 A at 58 V | 0.2 A at 58 V | 0.2 A at 58 V | 0.2 A at 58 V | – | – | – | 0.25 A | – | – | – | – |
| Maximum current | – | – | – | 3 A at 58 V | 3 A at 58 V | – | – | – | 4 A | 10 A at 24 V | 10 A at 24 V | 10 A at 24 V | – | – | – | – | 3 A at 58 V | 3 A at 58 V | – | – | – | 4 A | 10 A at 24 V | 10 A at 24 V | 10 A at 24 V | – |
| Communication interface / protocol | High-speed RS-485 | USB | USB | USB 2.0 at 1000 Hz | USB 2.0 at 1000 Hz | – | – | – | – | – | – | – | 1000BASE-T Ethernet | – | USB | USB | USB 2.0 at 1000 Hz | USB 2.0 at 1000 Hz | – | – | – | – | – | – | – | 1000BASE-T Ethernet |
| Repeatability / positioning accuracy | 0.1 mm fingertip-position resolution | – | – | ±1 mm | ±1 mm | 0.1° | 0.1° | ±0.20 mm | ±0.20 mm | 0.1° | 0.1° | 0.1° | – | – | – | – | ±1 mm | ±1 mm | 0.1° | 0.1° | ±0.20 mm | ±0.20 mm | 0.1° | 0.1° | 0.1° | – |
| Whole-hand / palm grip force | 5–120 N adjustable | – | – | – | – | 50 N | 50 N | – | – | 70 N palm/whole-hand grip | 70 N palm/whole-hand grip | 70 N palm/whole-hand grip | – | – | – | – | – | – | 50 N | 50 N | – | – | 70 N palm/whole-hand grip | 70 N palm/whole-hand grip | 70 N palm/whole-hand grip | – |
| Fingertip / pinch force | – | – | – | 10 N fingertip force | 10 N fingertip force | 15 N | 15 N | – | – | 20 N fingertip pinch | 20 N fingertip pinch | 20 N fingertip pinch | Peak fingertip force ≥15 N | – | – | – | 10 N fingertip force | 10 N fingertip force | 15 N | 15 N | – | – | 20 N fingertip pinch | 20 N fingertip pinch | 20 N fingertip pinch | Peak fingertip force ≥15 N |
| Thumb gripping force | – | – | – | – | – | – | – | 6 N | 30 N | – | – | – | – | – | – | – | – | – | – | – | 6 N | 30 N | – | – | – | – |
| Four-finger gripping force | – | – | – | – | – | – | – | 4 N | 28 N | – | – | – | – | – | – | – | – | – | – | – | 4 N | 28 N | – | – | – | – |
| Grip-force resolution | – | – | – | – | – | – | – | 0.50 N | – | – | – | – | – | – | – | – | – | – | – | – | 0.50 N | – | – | – | – | – |
| Whole-hand payload | – | – | – | – | – | – | – | – | – | 20 kg | 20 kg | 20 kg | – | – | – | – | – | – | – | – | – | – | 20 kg | 20 kg | 20 kg | – |
| Four-finger payload | – | – | – | – | – | – | – | – | – | 5 kg | 5 kg | 5 kg | – | – | – | – | – | – | – | – | – | – | 5 kg | 5 kg | 5 kg | – |
| Form-closure gripping payload | 20 kg | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – |
| Friction gripping payload | 5 kg | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – |
| Tactile sensors per hand | – | – | 33 | – | – | – | – | – | 17 | – | – | – | – | – | – | 33 | – | – | – | – | – | 17 | – | – | – | – |
| Array sensors per hand | – | – | – | – | 12 | – | – | – | – | – | – | – | – | – | – | – | – | 12 | – | – | – | – | – | – | – | – |
| Pressure sensors per hand | – | – | – | – | 94 | – | – | – | – | – | – | – | – | – | – | – | – | 94 | – | – | – | – | – | – | – | – |
| Tactile sensing capabilities | – | – | – | – | – | – | Pressure, friction, direction and proximity sensing | – | – | – | Full-palm tactile sensing | Full-palm visual-tactile sensing | – | – | – | – | – | – | – | Pressure, friction, direction and proximity sensing | – | – | – | Full-palm tactile sensing | Full-palm visual-tactile sensing | – |
| Tactile / force-detection range | – | – | – | – | 10–2500 g; non-destructive tolerance up to 20 kg | – | – | – | 0–30 N | – | 0–25 N | 0–25 N | – | – | – | – | – | 10–2500 g; non-destructive tolerance up to 20 kg | – | – | – | 0–30 N | – | 0–25 N | 0–25 N | – |
| Tactile accuracy / sensitivity | – | – | – | – | – | – | – | – | ≤5% FS | – | 0.01 N resolution | 0.01 N resolution | – | – | – | – | – | – | – | – | – | ≤5% FS | – | 0.01 N resolution | 0.01 N resolution | – |
| Minimum measurable visual-tactile deformation | – | – | – | – | – | – | – | – | – | – | – | 130 | – | – | – | – | – | – | – | – | – | – | – | – | 130 | – |
| Hand / finger motion speed | – | – | – | – | – | – | – | Thumb lateral >235°/s; thumb flexion >150°/s; four fingers >570°/s | Thumb lateral/flexion >130°/s; four fingers >200°/s | Opening/closing up to 3 Hz | Opening/closing up to 3 Hz | Opening/closing up to 3 Hz | Opening/closing ≥4 times/s | – | – | – | – | – | – | – | Thumb lateral >235°/s; thumb flexion >150°/s; four fingers >570°/s | Thumb lateral/flexion >130°/s; four fingers >200°/s | Opening/closing up to 3 Hz | Opening/closing up to 3 Hz | Opening/closing up to 3 Hz | Opening/closing ≥4 times/s |
| Gripper stroke | 90 mm | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – |
| Closing time | 0.24 s for full stroke | – | – | – | – | – | – | – | 0.8 s | – | – | – | – | – | – | – | – | – | – | – | – | 0.8 s | – | – | – | – |
| Finger / claw length | 80 mm | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – | – |
| Minimum grasping diameter | – | – | – | 10 | 10 | – | – | – | – | 10 | 10 | 10 | 0 | – | – | – | 10 | 10 | – | – | – | – | 10 | 10 | 10 | 0 |
| Maximum grasping diameter | – | – | – | – | – | – | – | – | – | 150 | 150 | 150 | – | – | – | – | – | – | – | – | – | – | 150 | 150 | 150 | – |
| Control frequency | – | – | – | – | – | – | – | – | – | 500 Hz | 500 Hz | 500 Hz | 1000 Hz × 20 axes | – | – | – | – | – | – | – | – | – | 500 Hz | 500 Hz | 500 Hz | 1000 Hz × 20 axes |
| Control mode | – | – | – | – | – | – | – | – | – | – | – | – | MIT force/position hybrid control | – | – | – | – | – | – | – | – | – | – | – | – | MIT force/position hybrid control |
| Joint backlash | – | – | – | – | – | – | – | – | – | – | – | – | <1° | – | – | – | – | – | – | – | – | – | – | – | – | <1° |
| Operating temperature | – | – | – | −20 to 60 °C | −20 to 60 °C | – | – | – | – | – | – | – | – | – | – | – | −20 to 60 °C | −20 to 60 °C | – | – | – | – | – | – | – | – |
| Transmission mechanism | – | – | – | 12 micro force-controlled composite-transmission joints plus 4 micro gear joints | 12 micro force-controlled composite-transmission joints plus 4 micro gear joints | – | – | – | – | – | – | – | Direct-drive rotary joints; backdrivable | – | – | – | 12 micro force-controlled composite-transmission joints plus 4 micro gear joints | 12 micro force-controlled composite-transmission joints plus 4 micro gear joints | – | – | – | – | – | – | – | Direct-drive rotary joints; backdrivable |
| Grasping configuration | – | – | – | – | – | – | – | Thumb lateral range >65° | – | – | – | – | Fully opposed; supports lateral swing | – | – | – | – | – | – | – | Thumb lateral range >65° | – | – | – | – | Fully opposed; supports lateral swing |
| Wrist RGB camera included | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes | Yes |
| Hand / end-effector notes | Two-finger force-controlled gripper; specifications are per gripper. | Three-finger force-controlled hand: thumb 3 DoF, index finger 2 DoF and middle finger 2 DoF; specifications are per hand. | Three-finger force-controlled hand: thumb 3 DoF, index finger 2 DoF and middle finger 2 DoF; specifications are per hand. | Five-finger dexterous hand; specifications are per hand. | Five-finger dexterous hand; specifications are per hand. | Height is measured from the middle fingertip to the palm root; specifications are per hand. | Height is measured from the middle fingertip to the palm root; specifications are per hand. | – | Documented mass is approximately 800 g (790 g + 10 g); specifications are per hand. | BrainCo Revo3 U21 family; specifications are per hand. | BrainCo Revo3 U21 family; specifications are per hand. | BrainCo Revo3 U21 family; specifications are per hand. | Variant table identifies this Wuji Hand 2 configuration as non-tactile; specifications are per hand. | The supplied document identifies the Advanced Version but does not state its detailed gripper specifications. | Three-finger force-controlled hand: thumb 3 DoF, index finger 2 DoF and middle finger 2 DoF; specifications are per hand. | Three-finger force-controlled hand: thumb 3 DoF, index finger 2 DoF and middle finger 2 DoF; specifications are per hand. | Five-finger dexterous hand; specifications are per hand. | Five-finger dexterous hand; specifications are per hand. | Height is measured from the middle fingertip to the palm root; specifications are per hand. | Height is measured from the middle fingertip to the palm root; specifications are per hand. | – | Documented mass is approximately 800 g (790 g + 10 g); specifications are per hand. | BrainCo Revo3 U21 family; specifications are per hand. | BrainCo Revo3 U21 family; specifications are per hand. | BrainCo Revo3 U21 family; specifications are per hand. | Variant table identifies this Wuji Hand 2 configuration as non-tactile; specifications are per hand. |
| Package, Warranty & Notes | ||||||||||||||||||||||||||
| Included items | Dex1-1 Standard grippers × 2; handheld remote controller | Dex3-1 force-controlled three-finger dexterous hands, non-tactile × 2; handheld remote controller | Dex3-1 force-controlled three-finger dexterous hands, tactile × 2; handheld remote controller | Dex5-1 force-controlled dexterous hands, non-tactile × 2; handheld remote controller | Dex5-1P force-controlled dexterous hands, tactile × 2; handheld remote controller | BrainCo Revo2 Basic bionic dexterous hands × 2; handheld remote controller | BrainCo Revo2 Touch tactile bionic dexterous hands × 2; handheld remote controller | Inspire DFQ dexterous hands, non-tactile × 2; handheld remote controller | Inspire E2 dexterous hands, tactile × 2; handheld remote controller | BrainCo Revo3 U21 dexterous hands, non-tactile × 2; handheld remote controller | BrainCo Revo3 U21T tactile dexterous hands × 2; handheld remote controller | BrainCo Revo3 U21VT visual-tactile dexterous hands × 2; handheld remote controller | Wuji Hand 2 dexterous hands, non-tactile × 2; handheld remote controller | Dex1-1 Advanced Version grippers × 2; removable internal base battery; charging pile kit; external power supply; handheld remote controller; visualization PC | Dex3-1 force-controlled three-finger dexterous hands, non-tactile × 2; removable internal base battery; charging pile kit; external power supply; handheld remote controller; visualization PC | Dex3-1 force-controlled three-finger dexterous hands, tactile × 2; removable internal base battery; charging pile kit; external power supply; handheld remote controller; visualization PC | Dex5-1 force-controlled dexterous hands, non-tactile × 2; removable internal base battery; charging pile kit; external power supply; handheld remote controller; visualization PC | Dex5-1P force-controlled dexterous hands, tactile × 2; removable internal base battery; charging pile kit; external power supply; handheld remote controller; visualization PC | BrainCo Revo2 Basic bionic dexterous hands × 2; removable internal base battery; charging pile kit; external power supply; handheld remote controller; visualization PC | BrainCo Revo2 Touch tactile bionic dexterous hands × 2; removable internal base battery; charging pile kit; external power supply; handheld remote controller; visualization PC | Inspire DFQ dexterous hands, non-tactile × 2; removable internal base battery; charging pile kit; external power supply; handheld remote controller; visualization PC | Inspire E2 dexterous hands, tactile × 2; removable internal base battery; charging pile kit; external power supply; handheld remote controller; visualization PC | BrainCo Revo3 U21 dexterous hands, non-tactile × 2; removable internal base battery; charging pile kit; external power supply; handheld remote controller; visualization PC | BrainCo Revo3 U21T tactile dexterous hands × 2; removable internal base battery; charging pile kit; external power supply; handheld remote controller; visualization PC | BrainCo Revo3 U21VT visual-tactile dexterous hands × 2; removable internal base battery; charging pile kit; external power supply; handheld remote controller; visualization PC | Wuji Hand 2 dexterous hands, non-tactile × 2; removable internal base battery; charging pile kit; external power supply; handheld remote controller; visualization PC |
| Whole-unit warranty | 12 months | 12 months | 12 months | 12 months | 12 months | 12 months | 12 months | 12 months | 12 months | 12 months | 12 months | 12 months | 12 months | 12 months | 12 months | 12 months | 12 months | 12 months | 12 months | 12 months | 12 months | 12 months | 12 months | 12 months | 12 months | 12 months |
| Warranty / option notes | Whole-unit warranty: 12 months. | Whole-unit warranty: 12 months. | Whole-unit warranty: 12 months. | Whole-unit warranty: 12 months. | Whole-unit warranty: 12 months. | Whole-unit warranty: 12 months. | Whole-unit warranty: 12 months. | Whole-unit warranty: 12 months. | Whole-unit warranty: 12 months. | Whole-unit warranty: 12 months. | Whole-unit warranty: 12 months. | Whole-unit warranty: 12 months. | Whole-unit warranty: 12 months. | Whole-unit warranty: 12 months. | Whole-unit warranty: 12 months. | Whole-unit warranty: 12 months. | Whole-unit warranty: 12 months. | Whole-unit warranty: 12 months. | Whole-unit warranty: 12 months. | Whole-unit warranty: 12 months. | Whole-unit warranty: 12 months. | Whole-unit warranty: 12 months. | Whole-unit warranty: 12 months. | Whole-unit warranty: 12 months. | Whole-unit warranty: 12 months. | Whole-unit warranty: 12 months. |
| Additional specification notes | Standard base does not support autonomous movement; it supports in-place Z-axis rotation. | Standard base does not support autonomous movement; it supports in-place Z-axis rotation. | Standard base does not support autonomous movement; it supports in-place Z-axis rotation. | Standard base does not support autonomous movement; it supports in-place Z-axis rotation. | Standard base does not support autonomous movement; it supports in-place Z-axis rotation. | Standard base does not support autonomous movement; it supports in-place Z-axis rotation. | Standard base does not support autonomous movement; it supports in-place Z-axis rotation. | Standard base does not support autonomous movement; it supports in-place Z-axis rotation. | Standard base does not support autonomous movement; it supports in-place Z-axis rotation. | Standard base does not support autonomous movement; it supports in-place Z-axis rotation. | Standard base does not support autonomous movement; it supports in-place Z-axis rotation. | Standard base does not support autonomous movement; it supports in-place Z-axis rotation. | Standard base does not support autonomous movement; it supports in-place Z-axis rotation. | Mobile base supports differential drive, in-place rotation and automatic recharge. | Mobile base supports differential drive, in-place rotation and automatic recharge. | Mobile base supports differential drive, in-place rotation and automatic recharge. | Mobile base supports differential drive, in-place rotation and automatic recharge. | Mobile base supports differential drive, in-place rotation and automatic recharge. | Mobile base supports differential drive, in-place rotation and automatic recharge. | Mobile base supports differential drive, in-place rotation and automatic recharge. | Mobile base supports differential drive, in-place rotation and automatic recharge. | Mobile base supports differential drive, in-place rotation and automatic recharge. | Mobile base supports differential drive, in-place rotation and automatic recharge. | Mobile base supports differential drive, in-place rotation and automatic recharge. | Mobile base supports differential drive, in-place rotation and automatic recharge. | Mobile base supports differential drive, in-place rotation and automatic recharge. |
| Configuration | H2-D Standard A, H2-D Standard B, H2-D Standard C, H2-D Standard D, H2-D Standard E, H2-D Standard F, H2-D Standard G, H2-D Standard H, H2-D Standard I, H2-D Standard J, H2-D Standard K, H2-D Standard L, H2-D Standard M, H2-D Ultimate A, H2-D Ultimate B, H2-D Ultimate C, H2-D Ultimate D, H2-D Ultimate E, H2-D Ultimate F, H2-D Ultimate G, H2-D Ultimate H, H2-D Ultimate I, H2-D Ultimate J, H2-D Ultimate K, H2-D Ultimate L, H2-D Ultimate M |
|---|---|
| Brand | Unitree |
| Robot type | Humanoid robot |
| Application | Research, Education, Development, Embodied AI, Manipulation |
Unitree H2-D är en avancerad humanoid överkroppsplattform från Unitree Robotics, utvecklad för forskning, robotutveckling, embodied AI och objektmanipulation.
Plattformen kombinerar två robotarmar med rörlig midja, kameror och en höjdjusterbar konstruktion. Beroende på konfiguration kan roboten utrustas med olika gripdon och fingerfärdiga robothänder för utveckling av avancerade manipulationsfunktioner.
Unitree H2-D finns i två huvudutföranden: Standard med stationär, roterande bas och Ultimate med mobil bas. Båda versionerna är höjdjusterbara, men erbjuder olika möjligheter att använda roboten vid olika arbetspositioner.
H2-D är en utvecklingsplattform. Specialiserade autonoma arbetsuppgifter kräver normalt ytterligare programmering, integration och tester för den aktuella tillämpningen.
Unitree H2-D kan användas för forskning och utveckling inom styrning av robotarmar, rörelseplanering och hantering av föremål.Robotens konstruktion gör det möjligt att undersöka hur två robotarmar samordnas för att gripa, flytta och manipulera objekt.
Med olika gripdon och robotiska händer kan utvecklingsteam studera allt från kontrollerade tvåfingersgrepp till mer komplexa handrörelser.
H2-D är relevant för projekt inom embodied AI, där artificiell intelligens används för att styra en fysisk robots handlingar. Genom att kombinera sensordata, rörelsekontroll och AI-modeller kan forskare och utvecklare undersöka hur robotar kan interagera med föremål och utföra fysiska uppgifter.
För dessa tillämpningar behöver programvara och styralgoritmer anpassas till projektets krav.
Unitree H2-D kan användas som plattform för utveckling av fjärrstyrning och datainsamling från robotens rörelser och interaktion med objekt. I sådana projekt kan operatörsstyrda rörelser och insamlad sensorinformation användas för att utveckla och utvärdera styrsystem och AI-modeller.
Vilken styrutrustning och programvara som behövs beror på projektets tekniska upplägg. Det är därför viktigt att skilja på robotplattformens befintliga funktioner och funktioner som behöver utvecklas separat.
H2-D finns med flera olika robothänder och gripdon, med varierande antal frihetsgrader och sensorfunktioner. Alternativen omfattar tvåfingersgripdon, trefingrade robothänder och femfingrade fingerfärdiga händer.
För projekt som kräver information om kontakten med föremål finns även konfigurationer med taktil eller visuellt-taktil avkänning.
Det gör H2-D relevant för forskning inom greppstyrning, fingerfärdig manipulation och hantering av objekt.
Den justerabara höjden på konstruktionen gör H2-D intressant för projekt där robotens armar behöver arbeta vid olika höjder.
Plattformen kan användas för att undersöka grepp, rörelsebanor och hantering av föremål vid definierade arbetspositioner.
Ultimate-versionens mobila bas ger ytterligare möjligheter att utveckla och testa arbetsmoment där förflyttning och manipulation behöver samverka.
Unitree H2-D erbjuds i 26 konfigurationer på Webot.se, fördelade mellan Standard A–M och Ultimate A–M.
Valet bör göras i två steg: först avgör du om projektet behöver en stationär eller mobil plattform, därefter väljer du gripdon eller robothänder.
Unitree H2-D Standard har en stationär bas som kan rotera på plats samt en höjdjusterbar pelarkonstruktion. Det gör Standard relevant för forsknings- och utvecklingsmiljöer där roboten ska arbeta från en bestämd position, men behöver kunna orientera överkroppen och armarna mot olika arbetsytor.
Standard saknar den mobila drivningen som finns i Ultimate-versionerna.
Unitree H2-D Ultimate har en mobil bas som möjliggör förflyttning mellan olika positioner. Ultimate kompletterar överkroppsplattformen med bland annat LiDAR, djupkamera och sensorer för den mobila basen. Enligt produktspecifikationen stöds även automatisk laddning.
Det gör Ultimate relevant för utvecklingsprojekt där roboten behöver kunna förflytta sig och arbeta vid olika positioner.
Vilka autonoma navigerings- och manipulationsfunktioner som finns tillgängliga beror på programvara och den aktuella tillämpningen.
H2-D har en konstruktion med justerbar höjd med ett angivet höjdintervall på 1 200–1 700 mm. Den vertikala rörelsen gör det möjligt att anpassa robotens position till olika experimentuppställningar och arbetsmoment.
Tillsammans med robotarmarnas rörelseförmåga ger detta förutsättningar för utveckling av manipulationsuppgifter vid olika höjder.
Både Standard och Ultimate finns i 13 olika handkonfigurationer, från A till M. Grundplattformen är densamma inom respektive huvudserie, medan ändeffektorerna påverkar greppfunktioner, sensorinformation och det totala antalet frihetsgrader.
A-konfigurationerna är utrustade med tvåfingersgripdon i Dex1-1-serien.
Standard A använder Dex1-1 Standard, medan Ultimate A har Dex1-1 Advanced.
Dessa alternativ är relevanta för forskning och utveckling inom kontrollerade grepp och hantering av föremål.
Konfigurationerna B och C använder trefingrade Dex3-1-händer. B-versionerna saknar taktil avkänning, medan C-versionerna har taktila sensorer för att registrera information om kontakt med föremål.
Det gör C-versionerna relevanta för projekt där kontaktinformation används i utveckling av greppstyrning och manipulation.
D-konfigurationerna omfattar Dex5-1 och E-konfigurationerna Dex5-1P. Dessa femfingrade händer erbjuder fler möjligheter till fingerfärdig manipulation och komplexa handrörelser.
Dex5-1P-versionerna har taktil avkänning enligt de angivna konfigurationsuppgifterna.
F–I-konfigurationerna omfattar robothänder från BrainCo och Inspire. Alternativen skiljer sig åt i konstruktion, rörelseegenskaper och möjlighet till taktil återkoppling.
Det gör det möjligt att välja en handlösning som bättre motsvarar projektets krav på gripfunktioner och sensorinformation.
J–L använder olika versioner av BrainCo Revo 3 U21, inklusive alternativ med taktil och visuellt-taktil avkänning. M använder Wuji Hand 2, en fingerfärdig robothand med många individuellt styrbara leder.
Dessa konfigurationer är särskilt relevanta för forskning inom komplexa handrörelser, objektmanipulation och AI-baserad greppstyrning.
Unitree H2-D och H2-A är båda humanoida överkroppsplattformar, men med olika mekaniska förutsättningar.
Unitree H2-A är en kompaktare överkroppsplattform för forskning inom robotarmstyrning, perception och manipulation. Den är relevant när projektet inte behöver H2-D höjdjusterbara pelare eller mobila bas.
Unitree H2-D erbjuder en höjdjusterbar konstruktion och möjlighet att välja mellan stationär och mobil bas. Den är därför ett alternativ för projekt där arbetsposition, räckvidd och förflyttning behöver ingå i utvecklingsarbetet.
Vilken plattform som passar bäst beror på projektets krav på uppställning, robotarmar, gripdon och mobilitet.
Läs mer om Unitree H2-A Humanoid.
Om projektet också omfattar tvåbent gång, balans och humanoid förflyttning kan Unitree H2 vara ett mer relevant alternativ.
Unitree H2 är en fullstor humanoidrobot med armar, ben och avancerad rörelsekontroll.
Den lämpar sig för forskning och utveckling där hela humanoidrobotens rörelsesystem behöver ingå, snarare än enbart överkroppens manipulation.
För projekt där en mindre humanoid överkroppsplattform är lämpligare kan även Unitree G1-D vara ett alternativ.
G1-D är inriktad på datainsamling, teleoperation och robotmanipulation. Den finns i olika konfigurationer med gripdon eller fingerfärdiga robothänder.
G1-D kan därför vara relevant att jämföra med H2-D när projektet fokuserar på utveckling av manipulationsfunktioner och insamling av rörelsedata.
Läs mer om Unitree G1-D Humanoid.
Unitree H2-D finns med flera typer av gripdon och robotiska händer. De olika alternativen ger möjlighet att anpassa plattformen till projekt där exempelvis tvåfingersgrepp, fingerfärdig manipulation eller taktil återkoppling är viktiga.
Observera att den valda H2-D-konfigurationen redan omfattar specifika gripdon eller robothänder. Kontrollera därför leveransomfattningen innan separata tillbehör läggs till.
Se tillbehör och robothänder till Unitree H2-D.
Valet av Unitree H2-D bör utgå från projektets behov av mobilitet, höjdjustering, robotarmstyrning och objektmanipulation.
På produktsidan kan du jämföra Standard och Ultimate samt välja mellan olika gripdon och fingerfärdiga robothänder.
Välj önskad konfiguration och kontakta Webot för offert på Unitree H2-D.
Unitree H2-D är en höjdjusterbar humanoid överkroppsplattform från Unitree Robotics för forskning, robotutveckling och objektmanipulation. Den har två robotarmar och stöd för olika gripdon och fingerfärdiga robothänder. H2-D finns i Standard-konfigurationer med stationär bas och Ultimate-konfigurationer med mobil bas.
Priset på Unitree H2-D beror på vilken konfiguration och vilka robothänder eller tillbehör som väljs. Webot erbjuder produkten via offert, där utrustning, pris och leveransvillkor bekräftas utifrån den aktuella beställningen. Kontakta Webot för offert på önskad H2-D-konfiguration.
H2-D Standard har en stationär, roterande bas och höjdjusterbar pelare. H2-D Ultimate har dessutom en mobil bas för förflyttning mellan olika positioner. Ultimate omfattar bland annat LiDAR, djupkamera och stöd för automatisk laddning. Båda serierna finns med olika gripdon och robotiska händer.
H2-D Ultimate har en motordriven mobil bas som stöder förflyttning och rotation på plats. Standard-versionerna har ingen motsvarande mobil drivning, men kan rotera sin bas från en stationär position. Vilka autonoma navigeringsfunktioner som är tillgängliga beror på programvaran och den aktuella konfigurationen.
Enligt de publicerade produktspecifikationerna kan H2-D justeras mellan cirka 1 200 och 1 700 mm i höjd, vilket motsvarar en vertikal rörelse på cirka 500 mm. Höjdjusteringen gör det möjligt att arbeta vid olika positioner i forsknings- och utvecklingsmiljöer.
Webot erbjuder 26 konfigurationer av Unitree H2-D: 13 Standard-varianter och 13 Ultimate-varianter. Inom respektive serie skiljer sig modellerna främst genom val av gripdon eller robotiska händer, med olika antal frihetsgrader och sensorfunktioner.
H2-D erbjuds med bland annat Dex1-1-gripdon, Dex3-1, Dex5-1, Dex5-1P, BrainCo Revo 2, BrainCo Revo 3, Inspire och Wuji Hand 2. Alternativen skiljer sig åt i greppfunktioner, antal frihetsgrader och tillgång till taktil avkänning. Kontrollera vilka händer som ingår i den valda konfigurationen.
H2-D stöder vidareutveckling enligt Webots publicerade produktspecifikationer. Plattformen kan användas i utvecklingsprojekt inom bland annat robotarmstyrning, manipulation och embodied AI. Vilka programmeringsgränssnitt och programvarufunktioner som är tillgängliga behöver kontrolleras för projektets tekniska krav.
Unitree H2-D är främst en utvecklingsplattform. Ultimate-versionerna har en mobil bas med sensorer och stöd för förflyttning, men avancerade autonoma arbetsuppgifter kan kräva ytterligare programmering, integration och tester. Det är därför viktigt att skilja mellan robotens grundfunktioner och en färdig automatiserad tillämpning.
Unitree H2-D är en höjdjusterbar humanoidplattform som finns med stationär eller mobil bas. Unitree H2-A är en kompaktare överkroppsplattform för forskning och manipulation utan motsvarande integrerade mobila bas. Valet beror på projektets krav på uppställning, höjdjustering, mobilitet och hantering av föremål.